今日从 arXiv 订阅中筛选 10 篇论文。
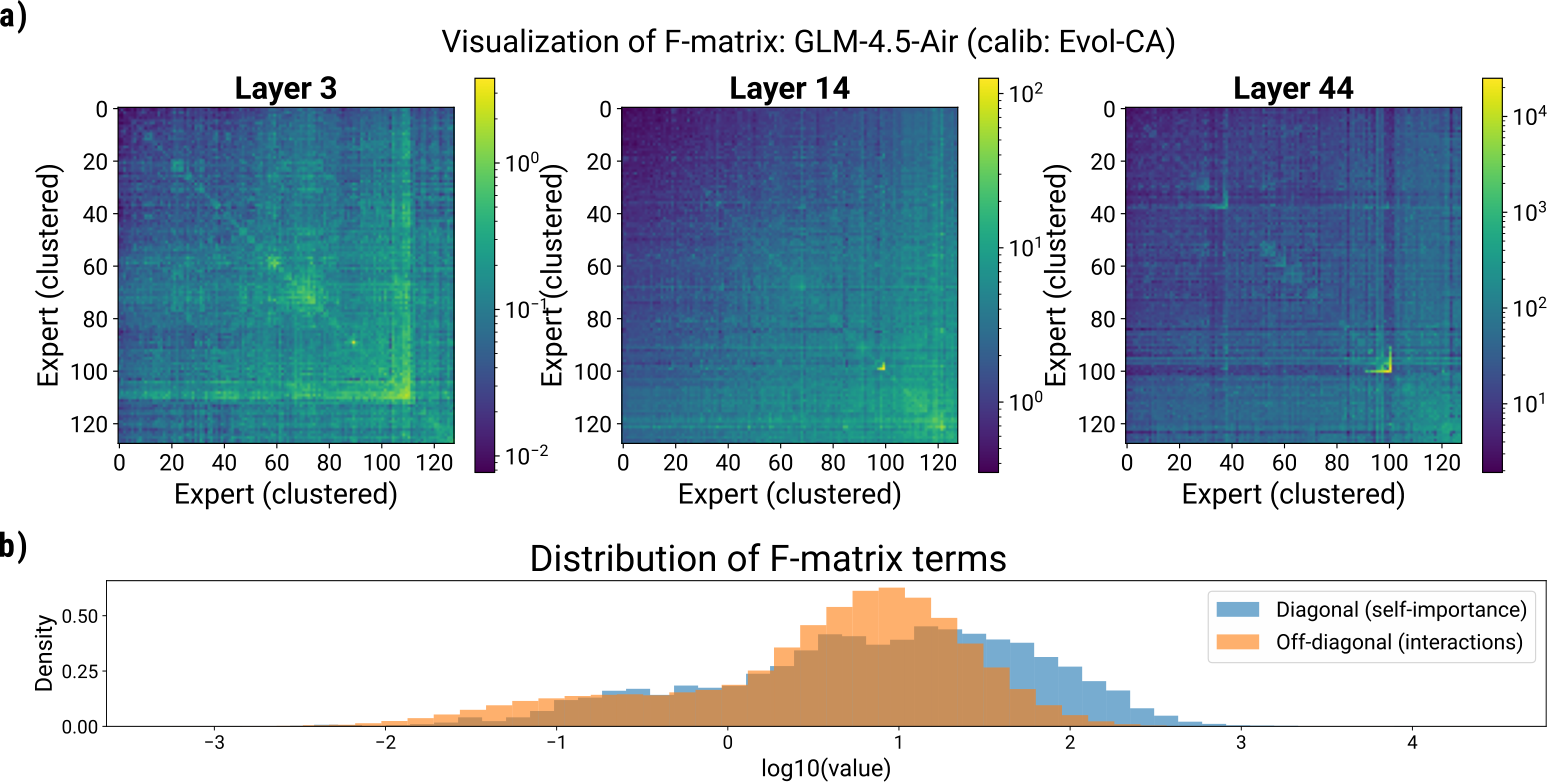
⚡ Higher-order pruning of experts in mixture-of-experts language models
专家剪枝要二阶:REAP 忽略了专家之间的交互项。
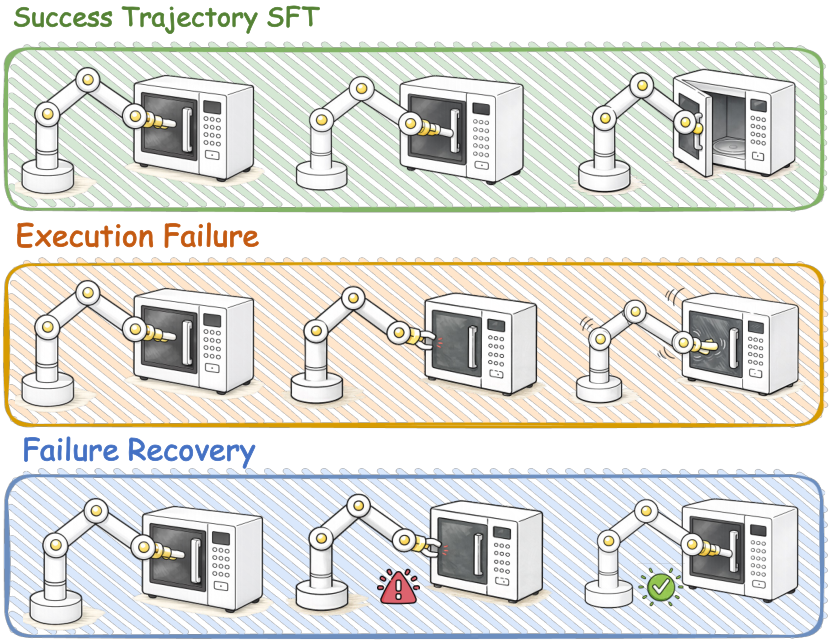
⚡ Causal-History Test-Time Scaling for Failure Recovery in Autoregressive World-Action Models
自回归 WAM 出错后:把"历史改哪里"也当作搜索问题。
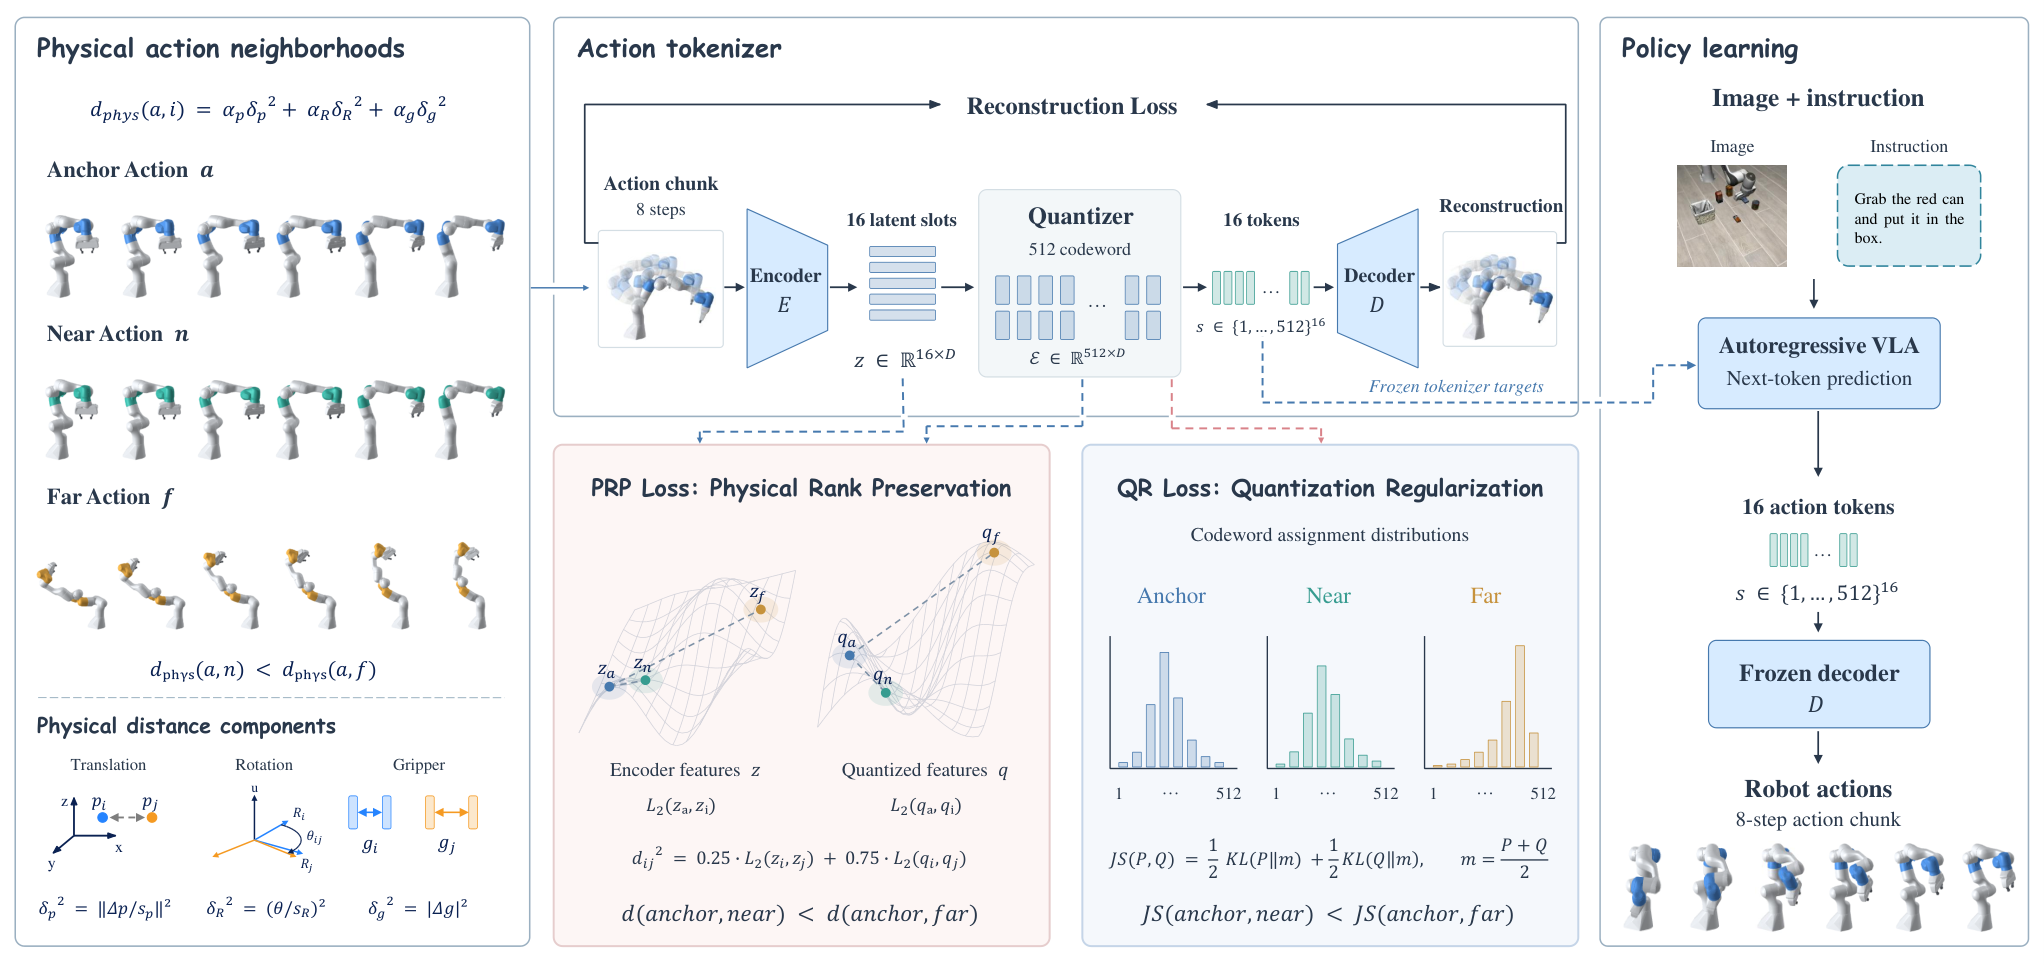
⚡ ActionPiece: Rethinking Action Tokenization for Autoregressive Vision-Language-Action Models
动作 tokenizer:重建 MSE 会骗人,物理关系会。
⚡ Zing-0.5: Toward Playable Worlds with Real-Time Joint Action and Text Control
可玩世界模型:键盘+文本联合实时控制,成本按分钟计价。
⚡ StrucPhysVideo: Learning Physical Dynamics from Structured Captions and Robot Actions
视频世界模型的物理课:结构化标注 + 稀疏 MoE 课程。
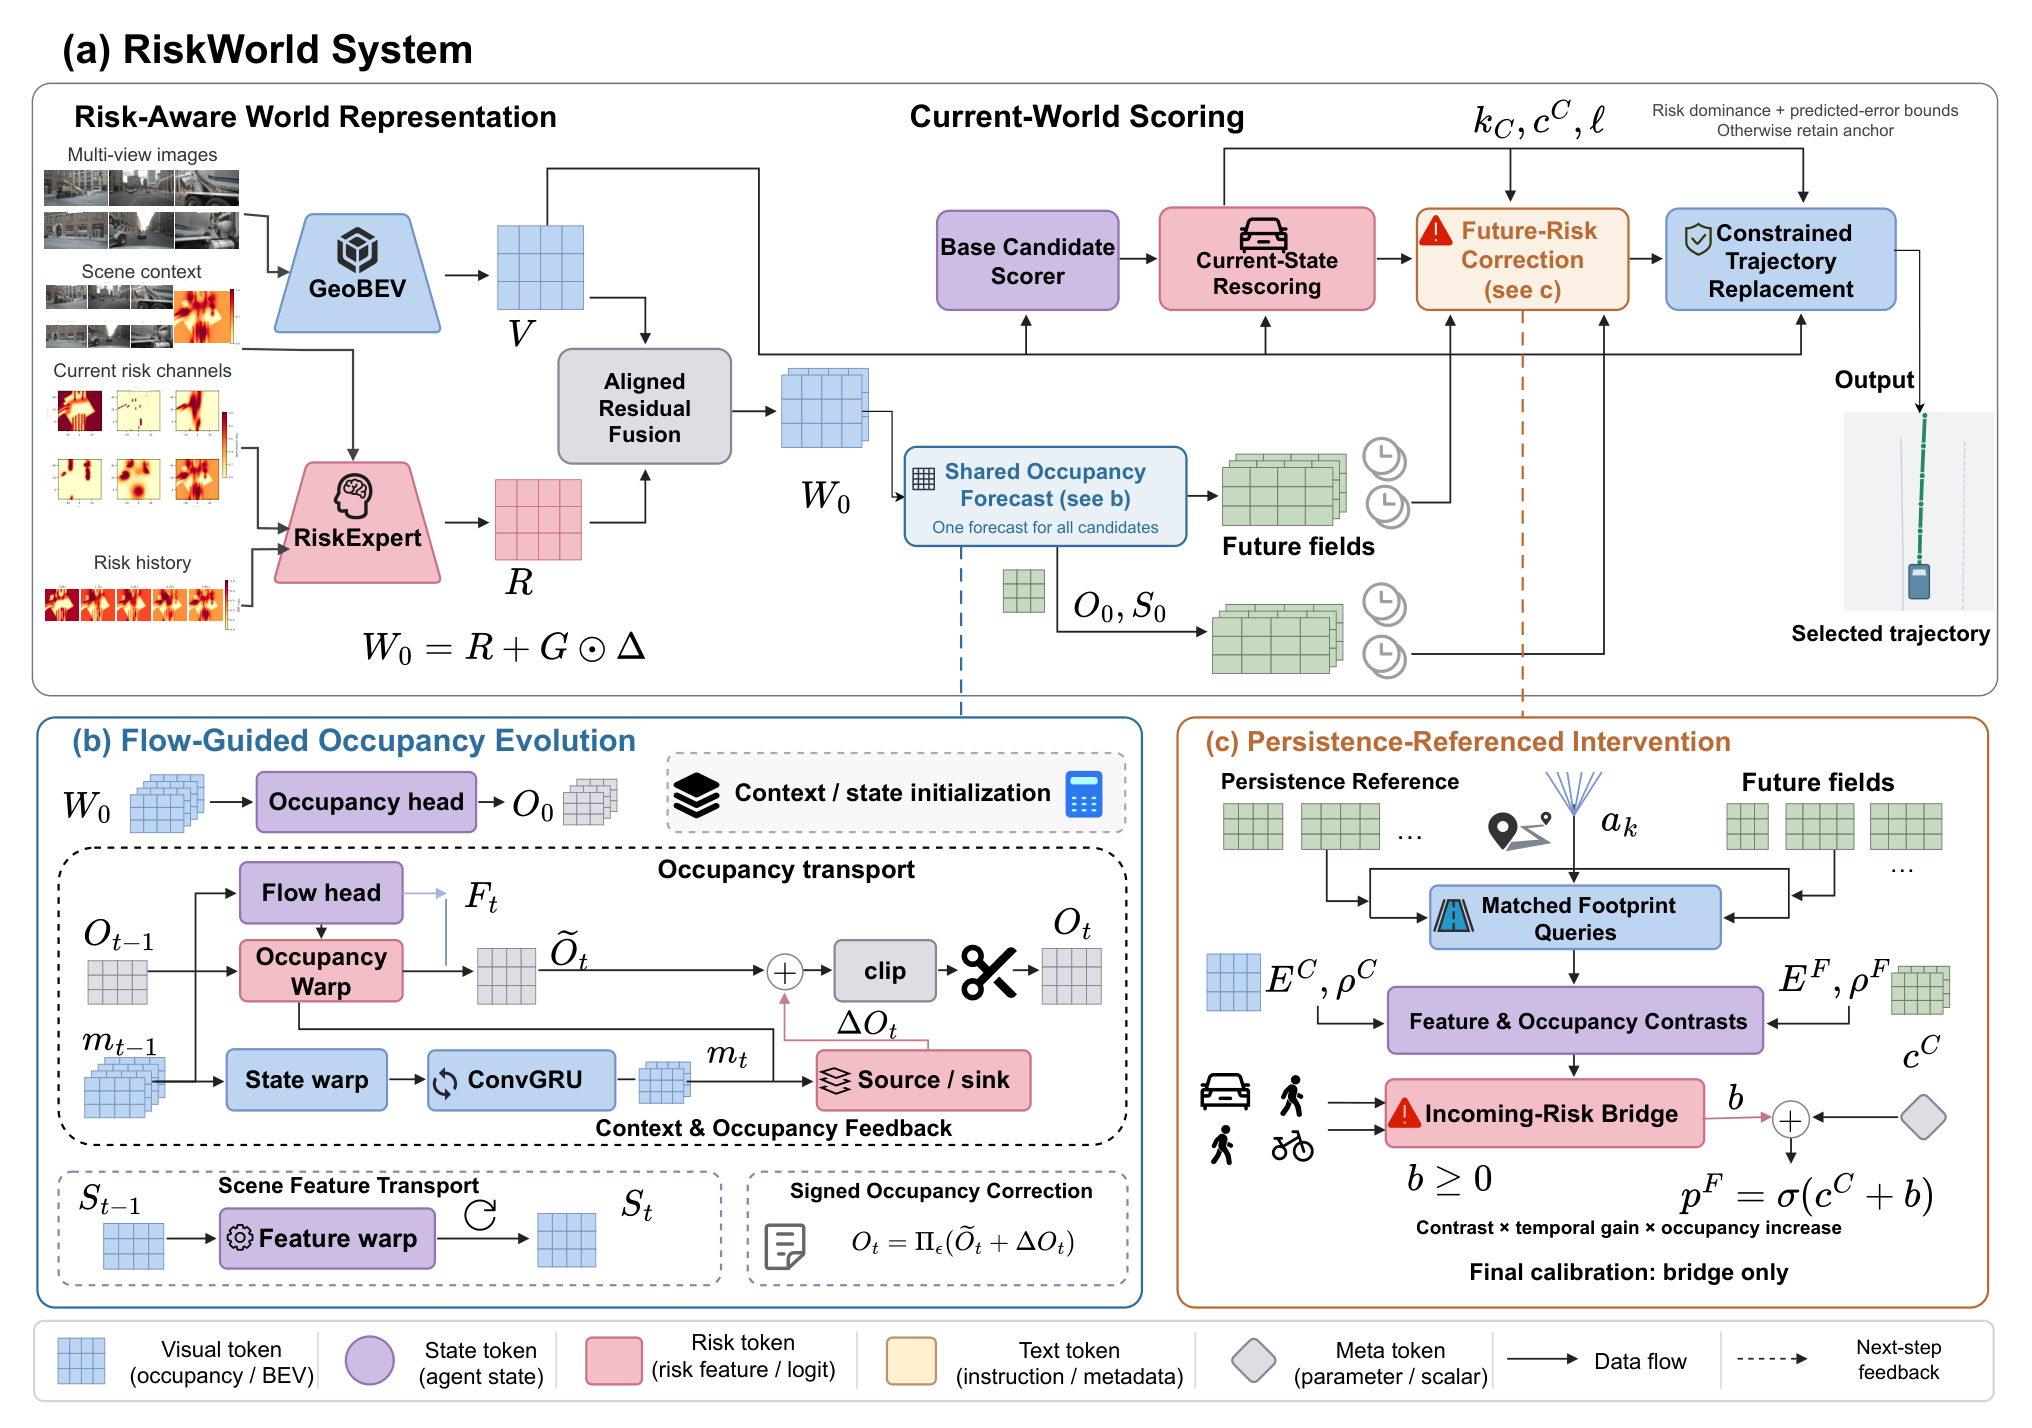
⚡ Risk-Aware World Modeling with Flow-Guided Occupancy Evolution for Selective Trajectory Planning in Automated Driving
什么时候该改道:风险增量触发,而不是每步重规划。
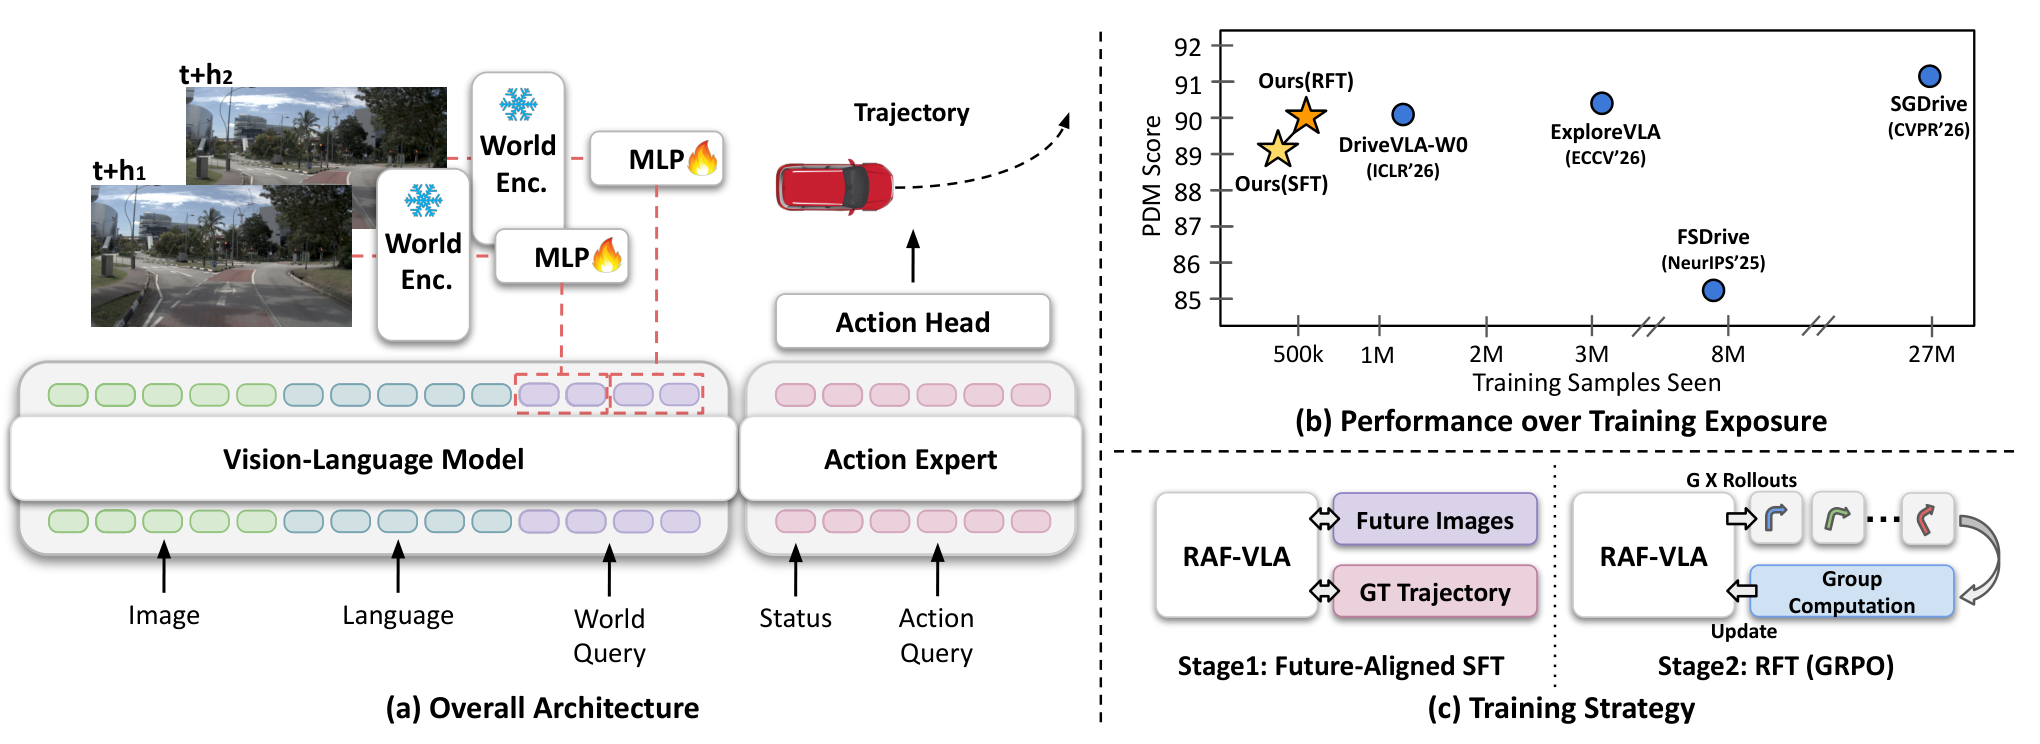
⚡ RAF-VLA: Representation Alignment with the Future for End-to-End Autonomous Driving
未来不必生成:对齐未来帧的表示就够了。
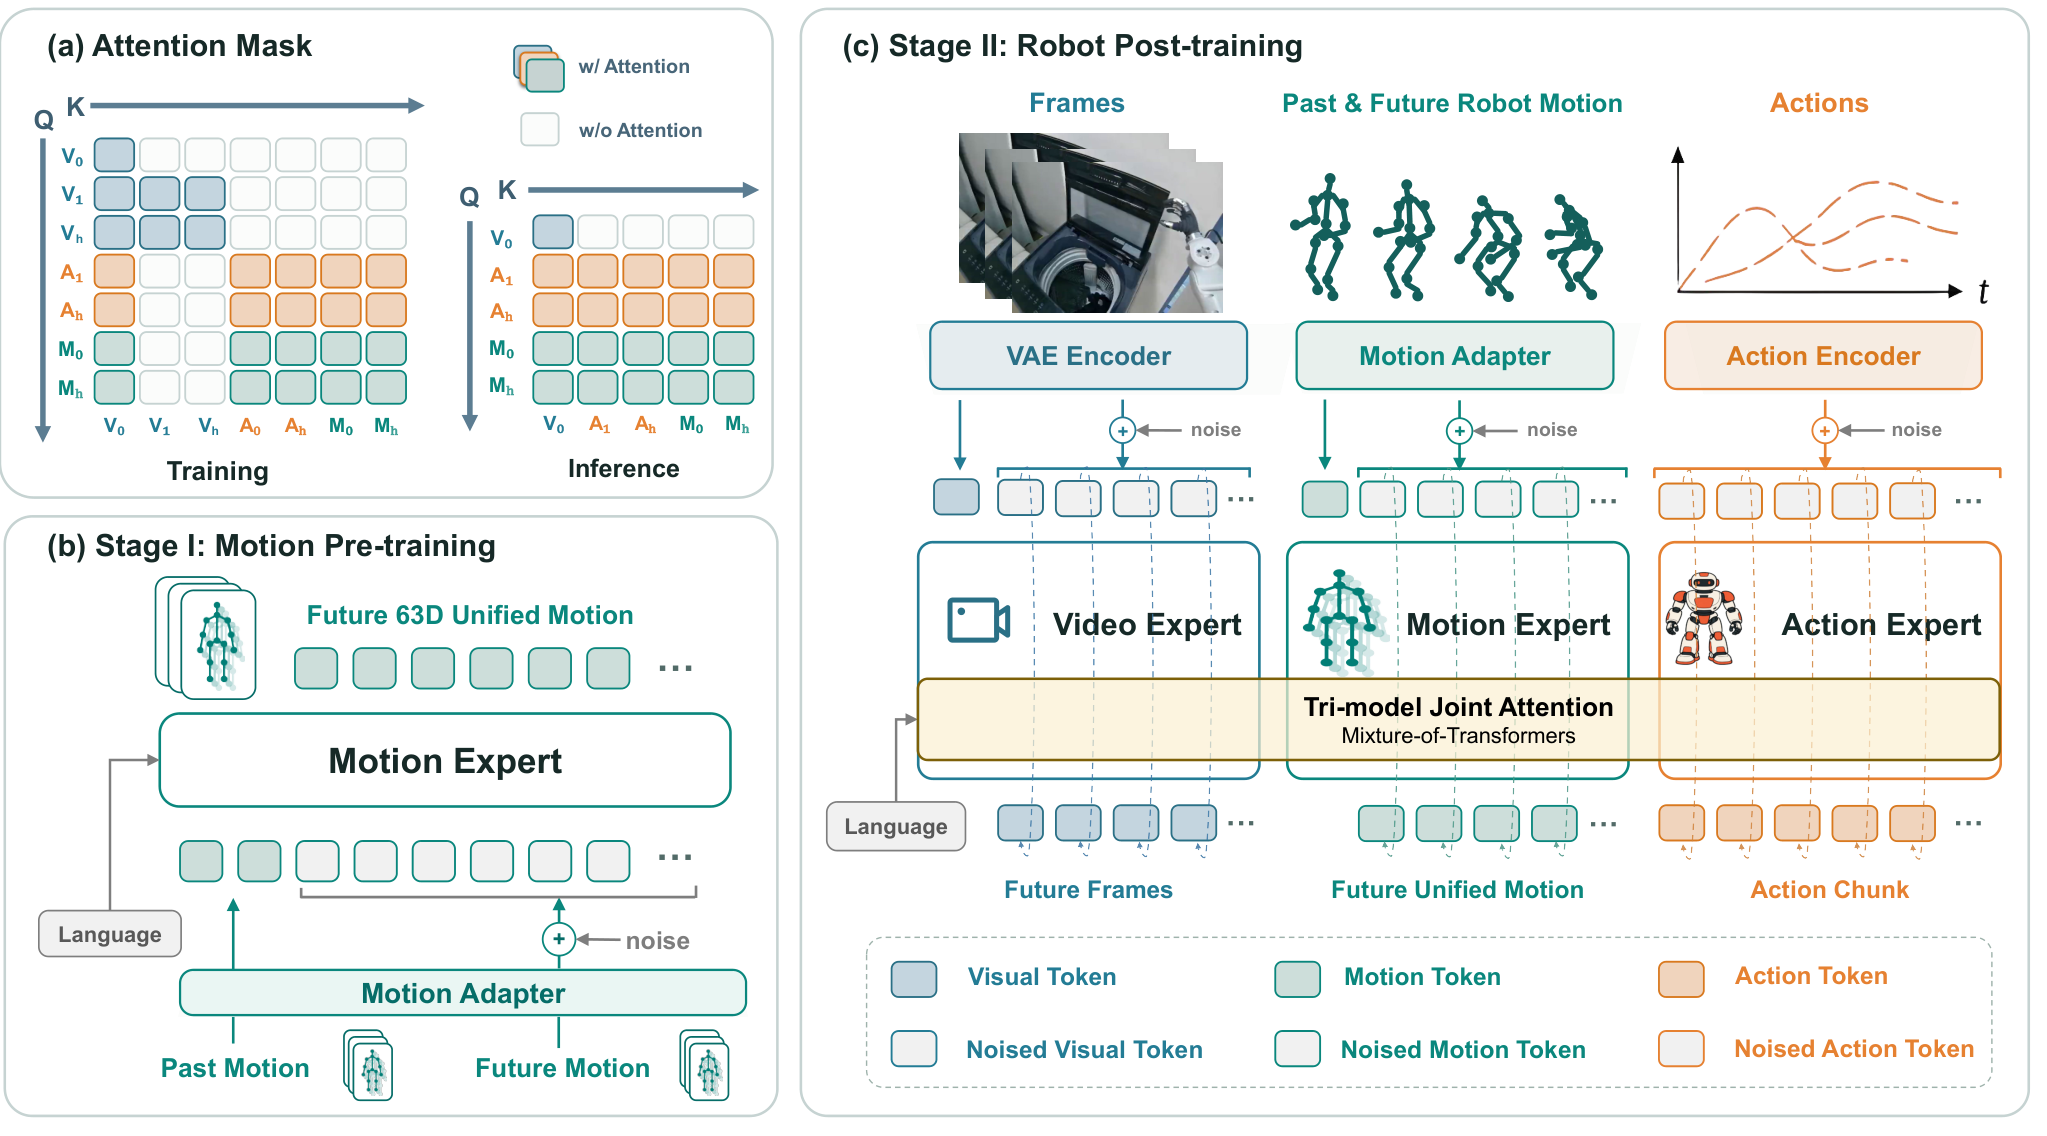
⚡ WholeBodyWAM: Learning Whole-Body World Action Models with Scalable Motion Priors
人形全身 WAM:先把人类/异构机体的运动学成先验。
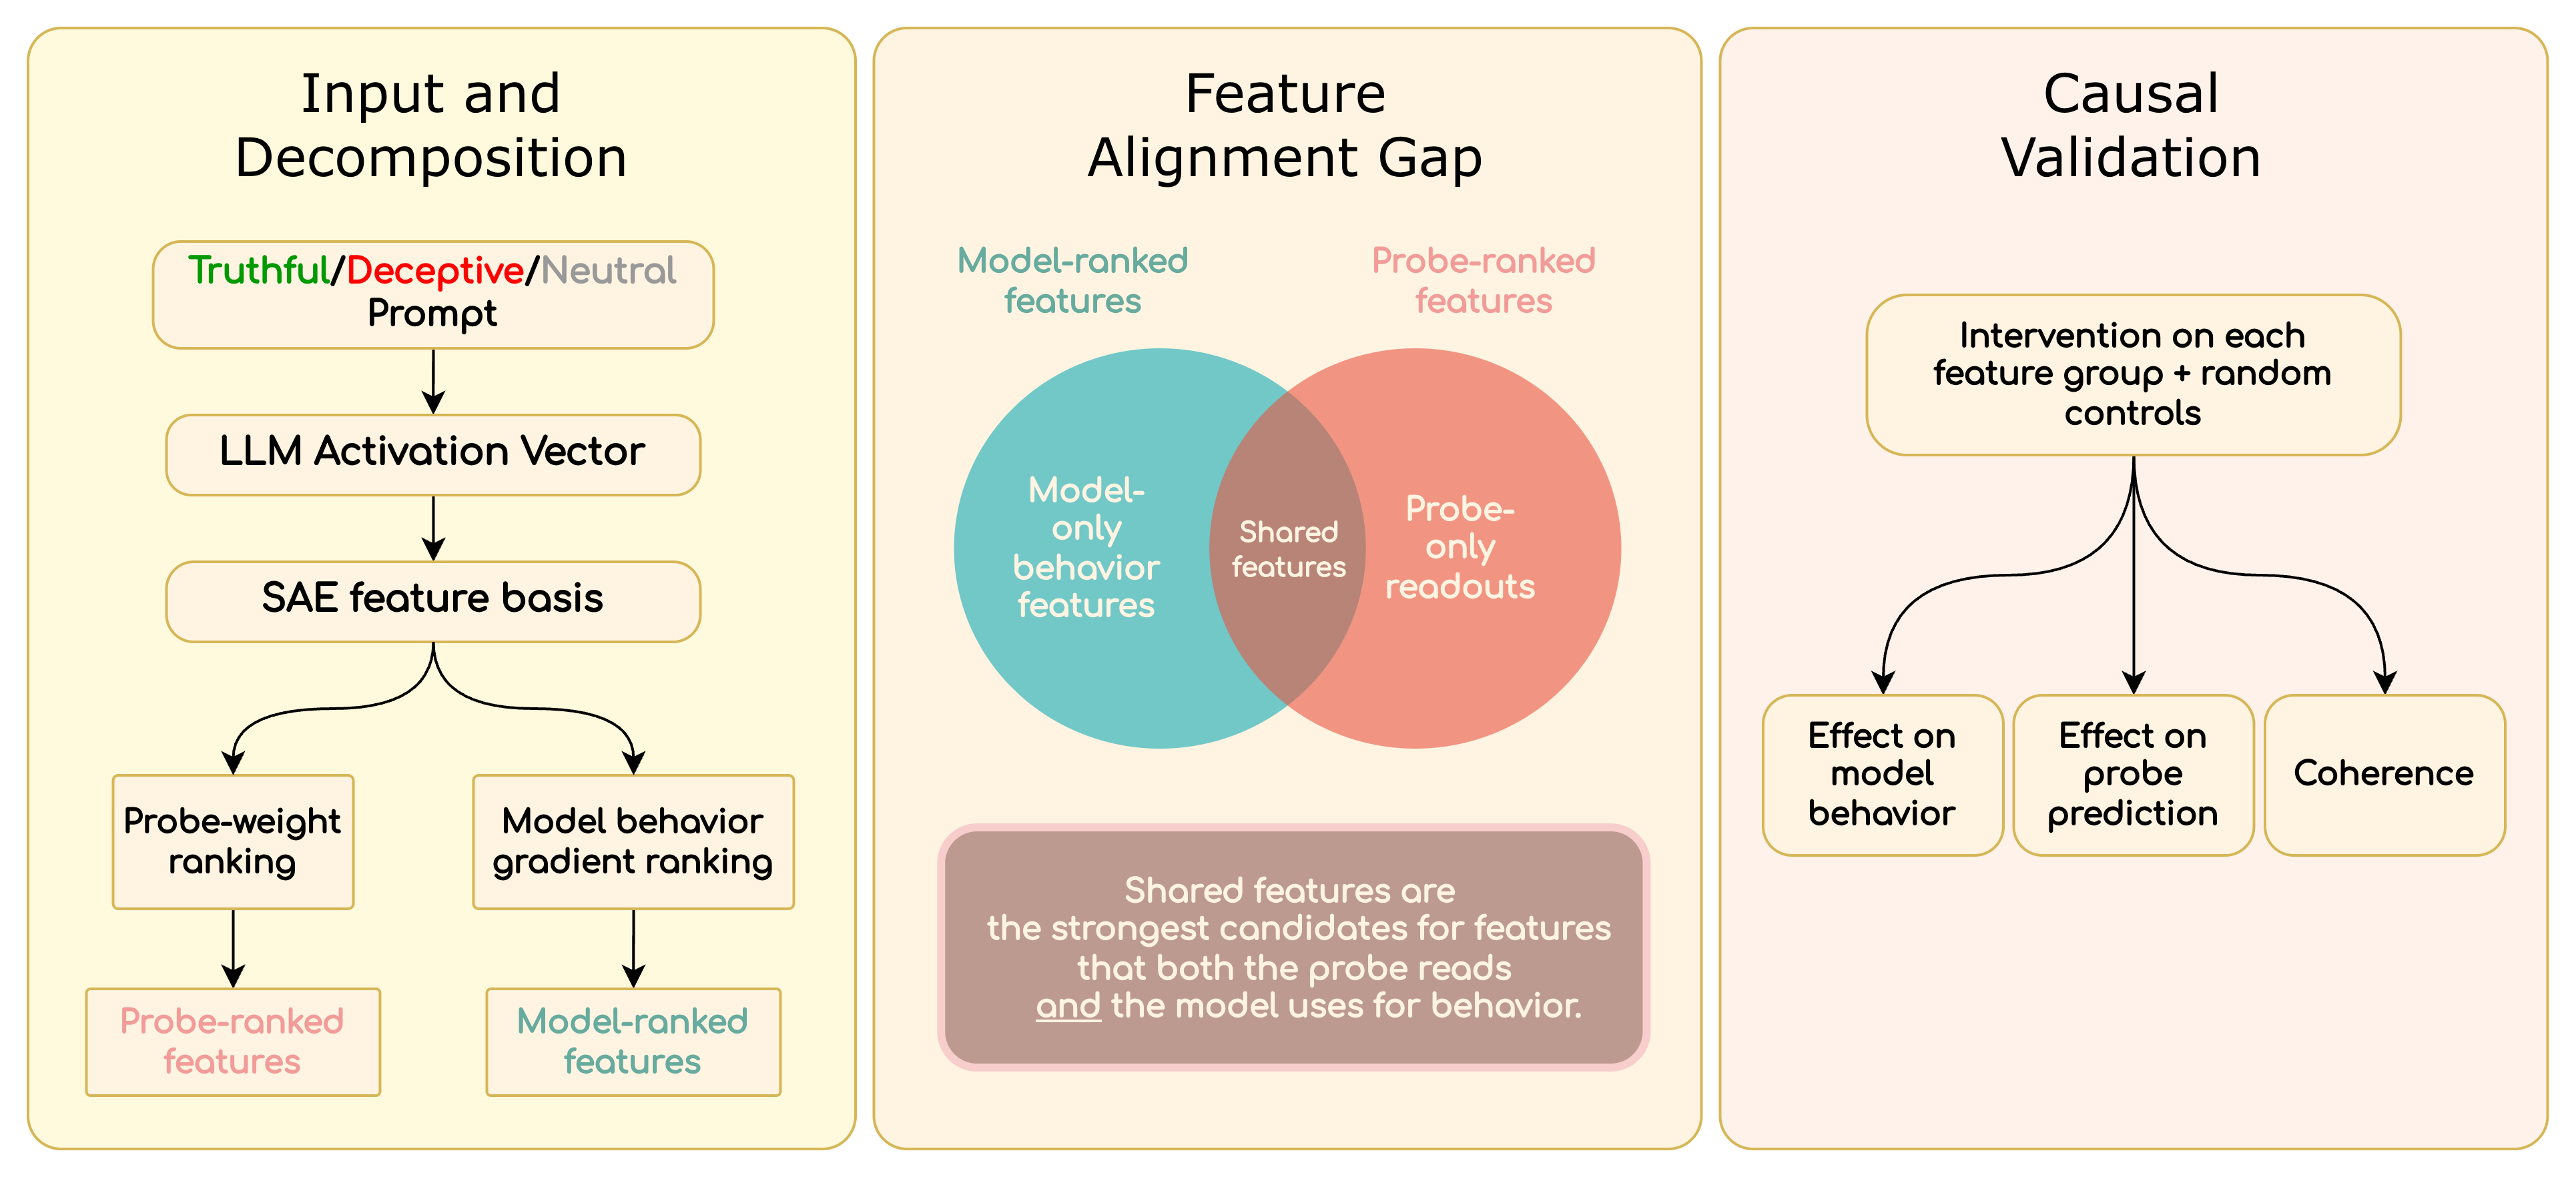
⚡ Decodability is Not Causality: Dissociating Probe Readouts from Behavioral Drivers via SAE Decomposition
探针能读到,不等于模型在用它。
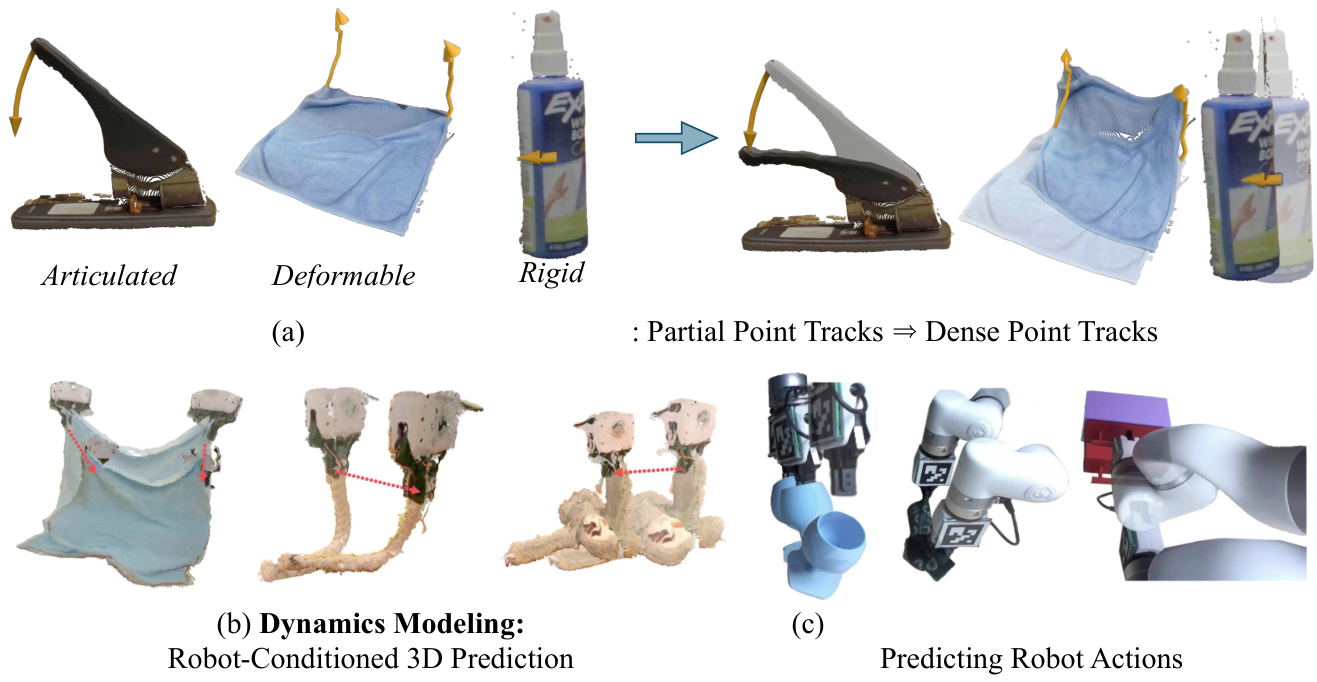
⚡ PointZero: 3D Point Track Completion for Learning Transferable 3D Dynamics
点轨迹补全:不用机器人数据学会 3D 动力学。
自动生成于 2026-09-18 · 基于 arXiv Daily Digest