今日从 arXiv 订阅中筛选 10 篇论文。
⚡ IMPLY: Physically Anchored Consistency for World-Model Rollouts
世界模型 rollout 的物理锚定一致性:不只看"自洽",要看反演出的物理量是否被证据锚定。
⚡ SMELT: Scaling Laws for Compute-Matched MoE Looped Transformers
looped MoE 的 compute-matched 缩放律:中间一半层循环两次,三预算对齐后仍省 6.8–18% FLOPs。
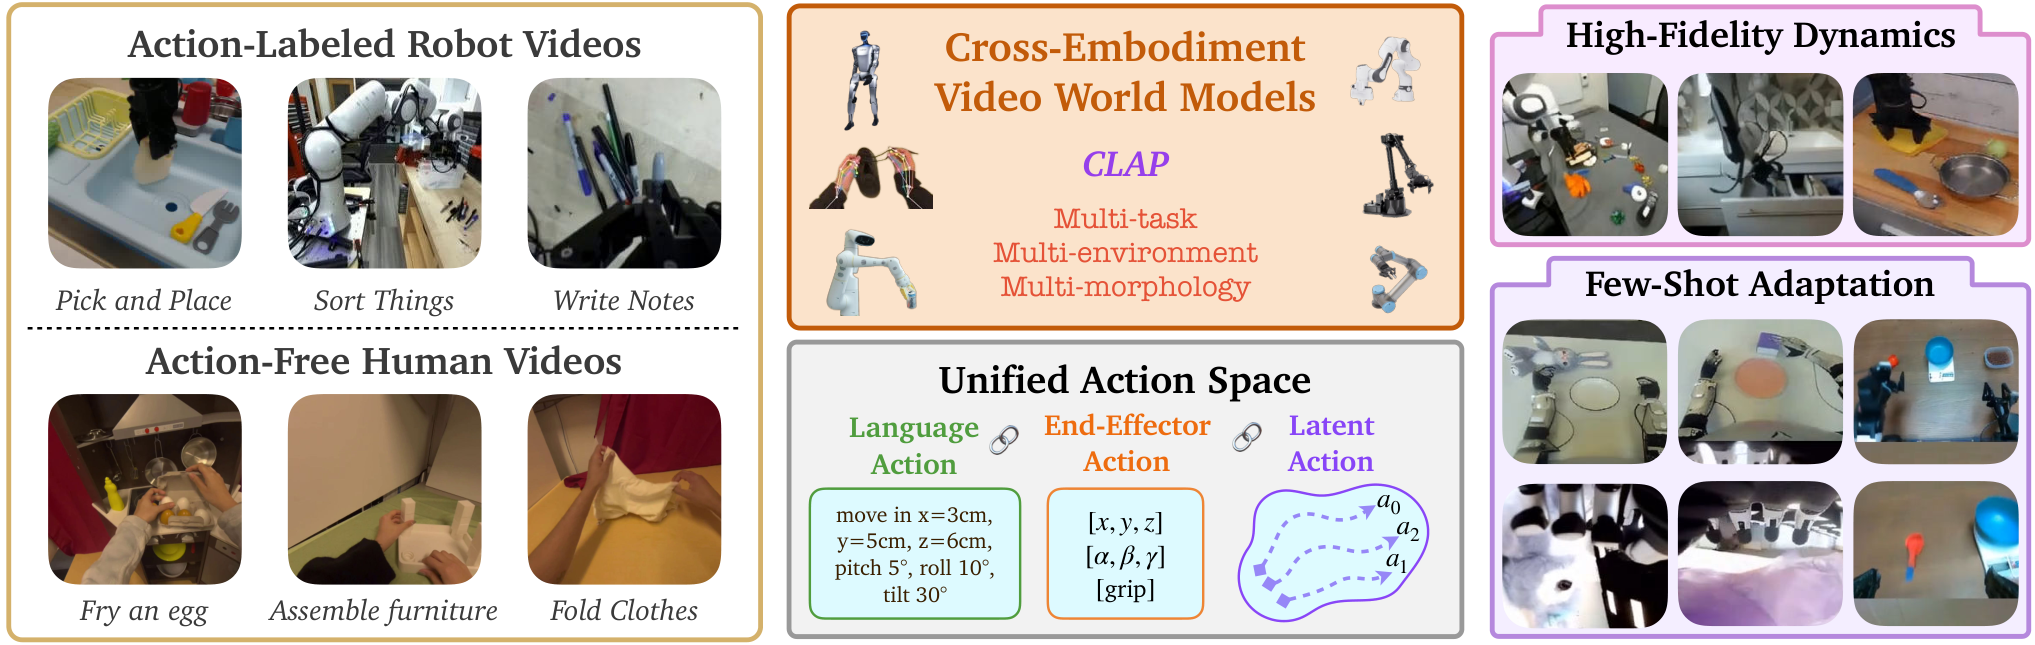
⚡ CLAP: Cross-Embodiment Video World Models are Zero-Shot Physical Simulators
跨具身视频世界模型=零样本物理模拟器:统一动作接口 + 课程式跨具身学习。
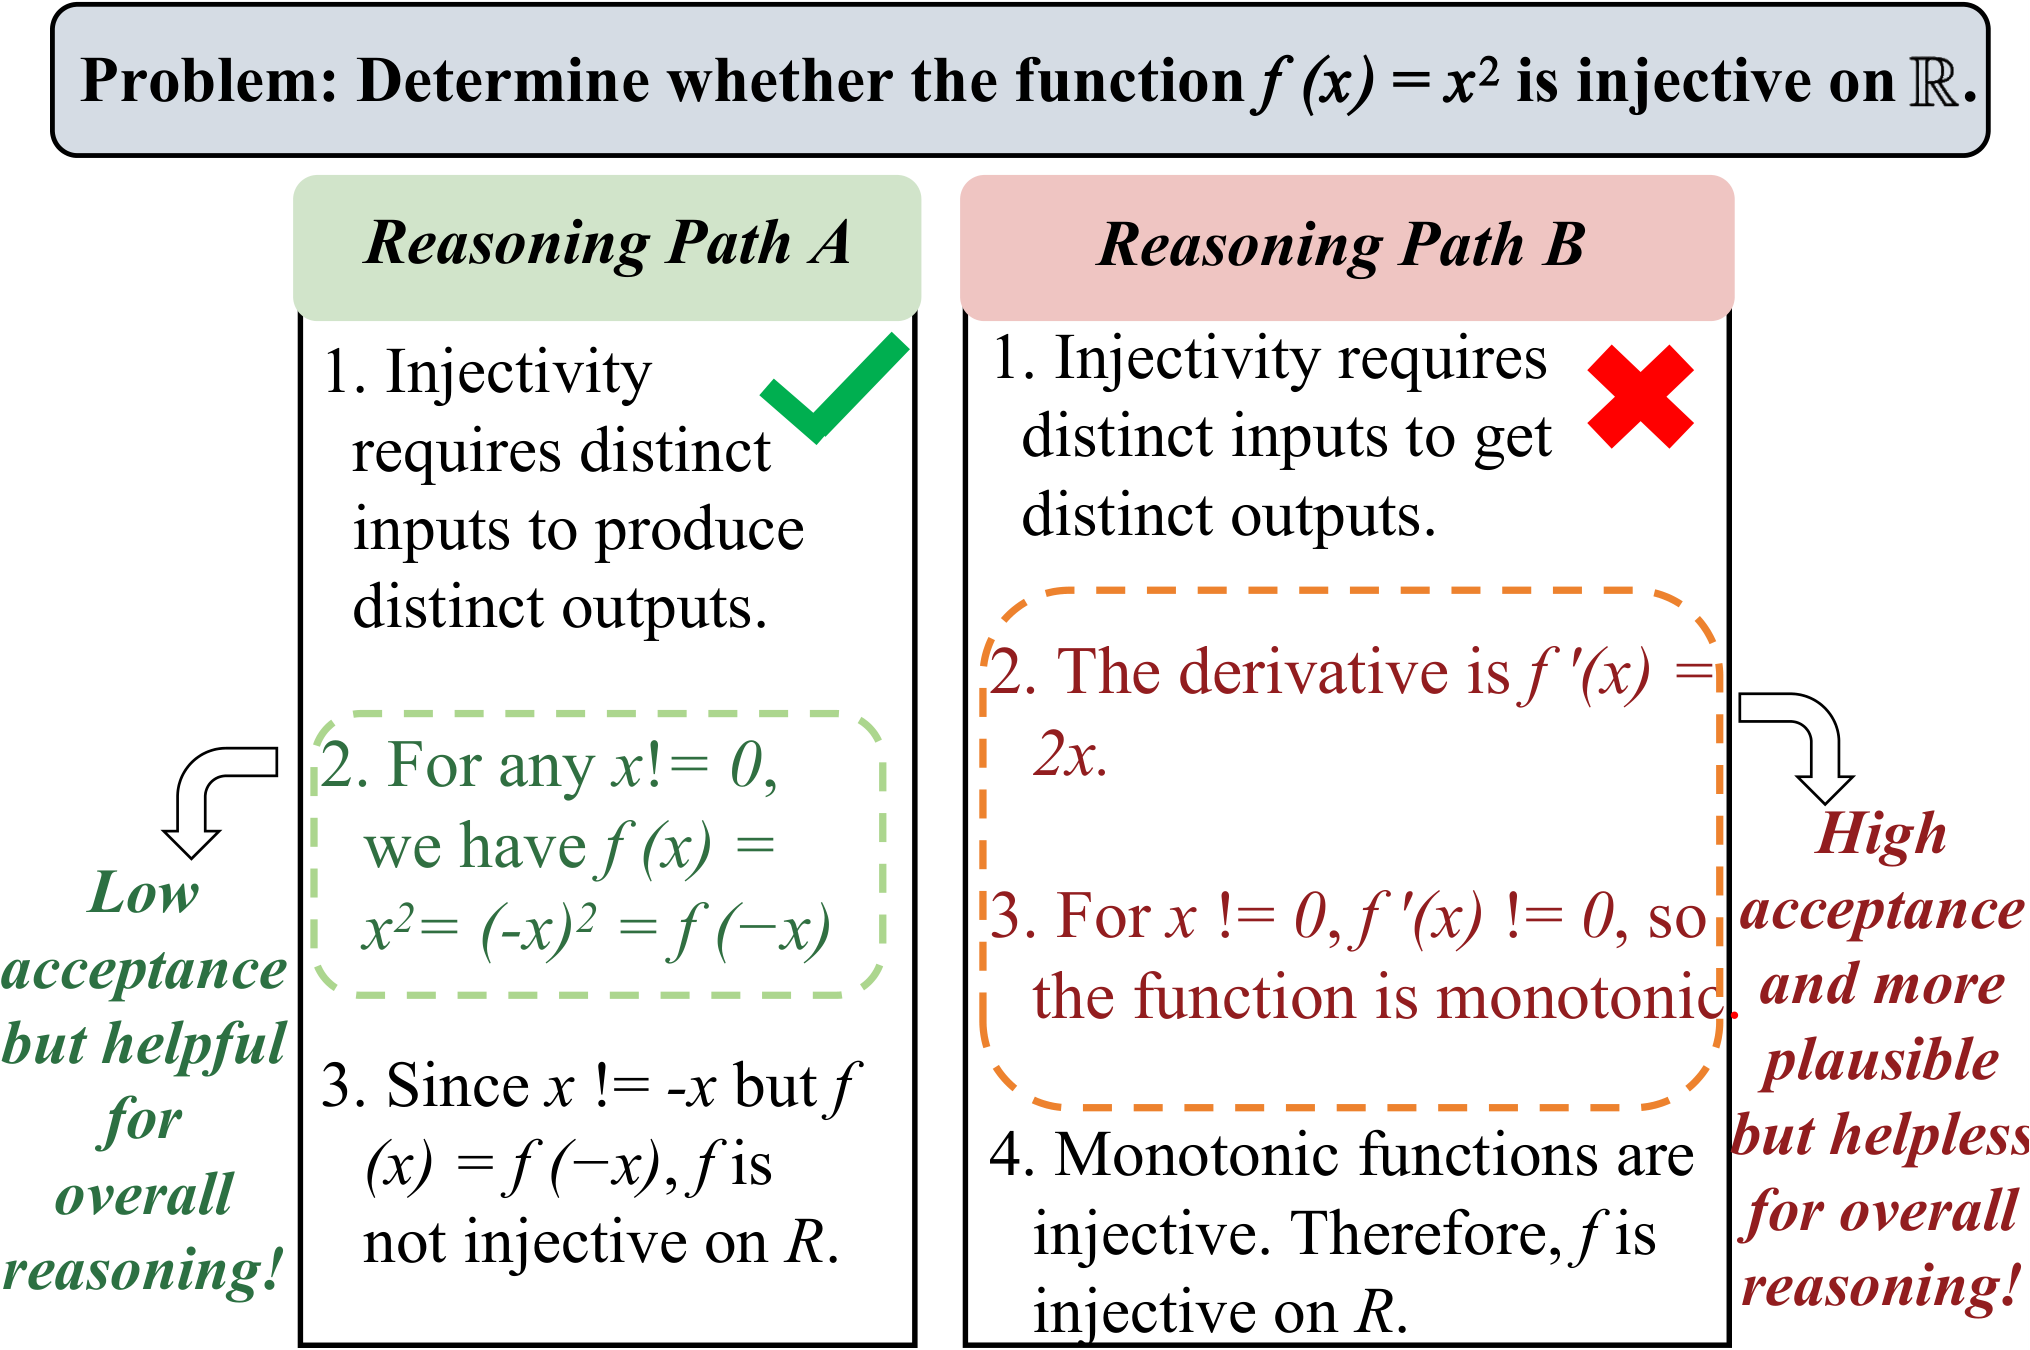
⚡ Sampling via Decision-Flow: Training-Free Extraction of Improved Latent Reasoning Paths in Large Language Models
训练-free 提取 latent 推理路径:全局轨迹评估 + 效用回传,GPQA 45.6 反超 RL 训练。
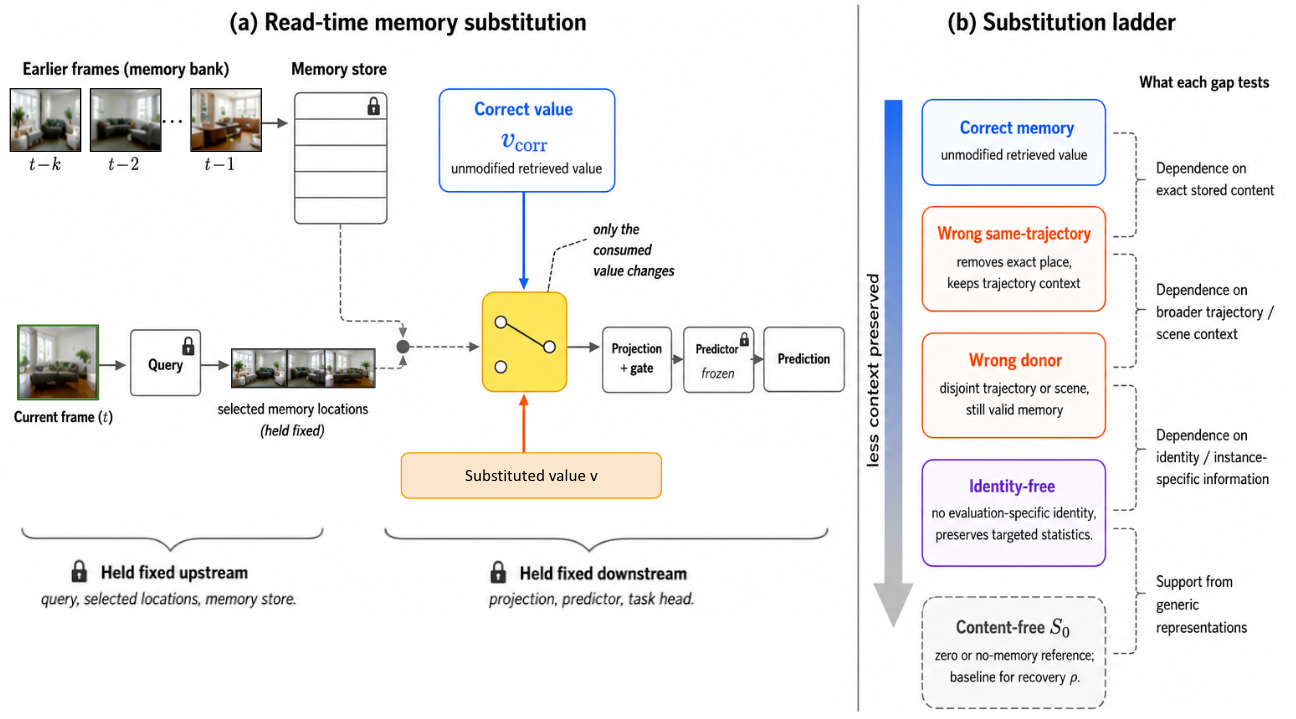
⚡ Does Video Memory Use What It Retrieves? A Causal Audit of Memory Specificity
视频记忆的因果审计:读时替换分离"记忆增益"与"记忆特异性"。
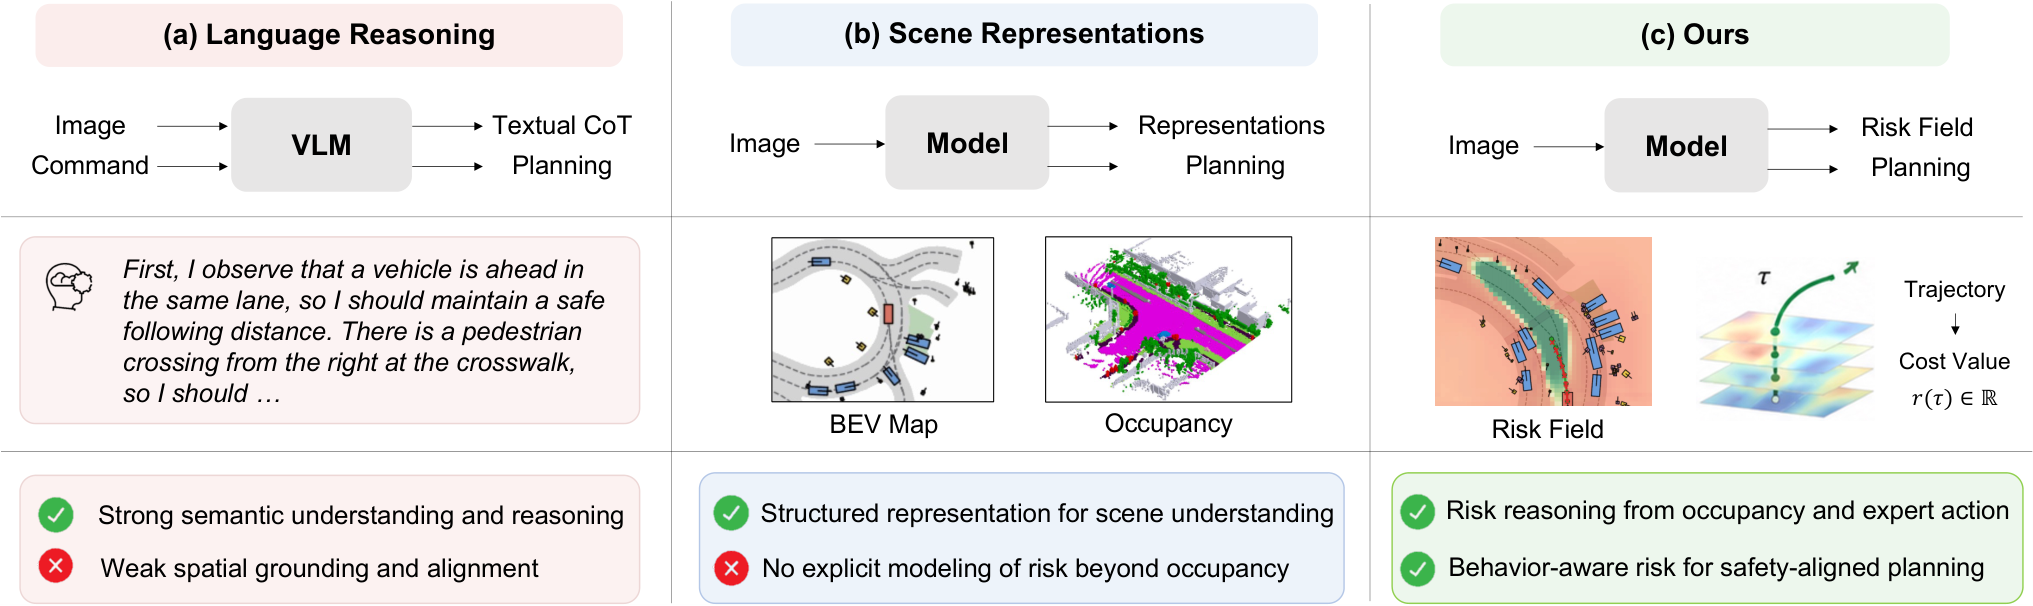
⚡ READ: Learning Risk-Informed Fields for End-to-End Autonomous Driving
E2E 自动驾驶的学习式风险场:显式、可微、planning-aligned 的时空风险表示。
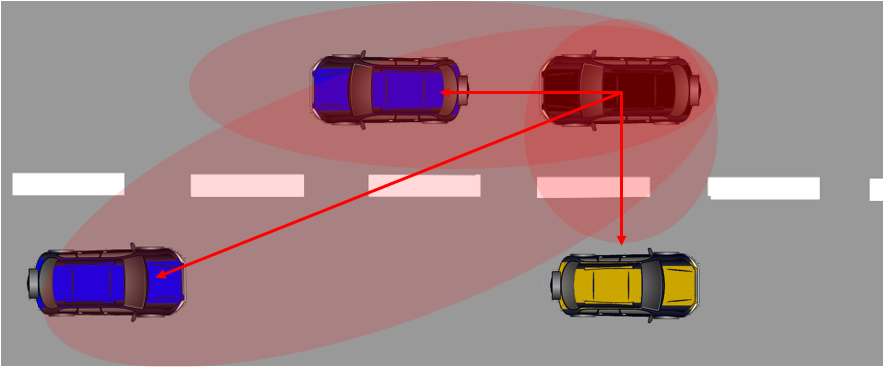
⚡ Scenario-Independent Criticality Assessment and Prediction for Vulnerable Road Users in Autonomous Driving
VRU 专用 criticality 度量 + 场景无关预测框架。
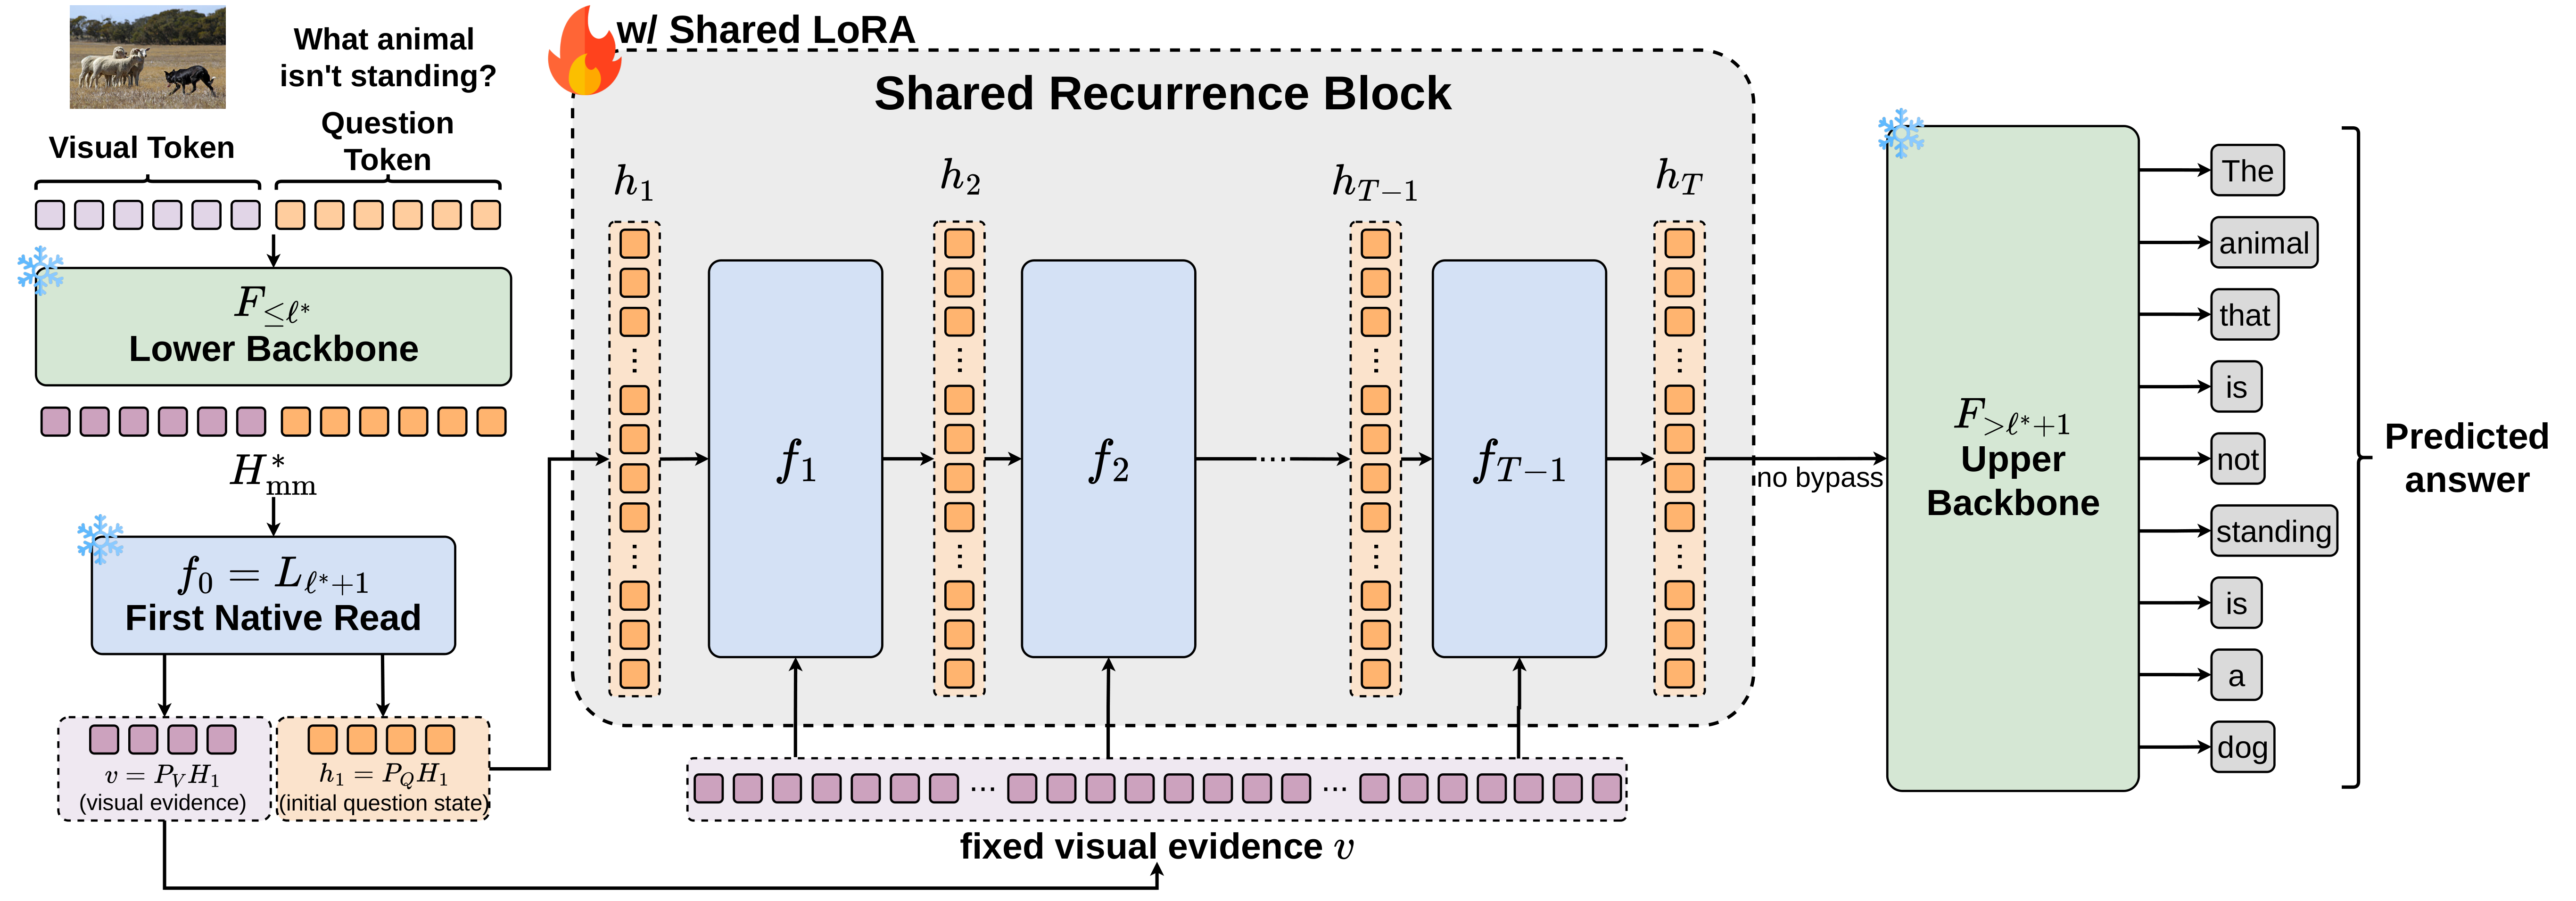
⚡ Reason Through the Latent! Making Latent Visual Reasoning Necessary
让 latent 视觉推理"因果必要":解码前删掉视觉 KV,只让递归状态携带图像信息。
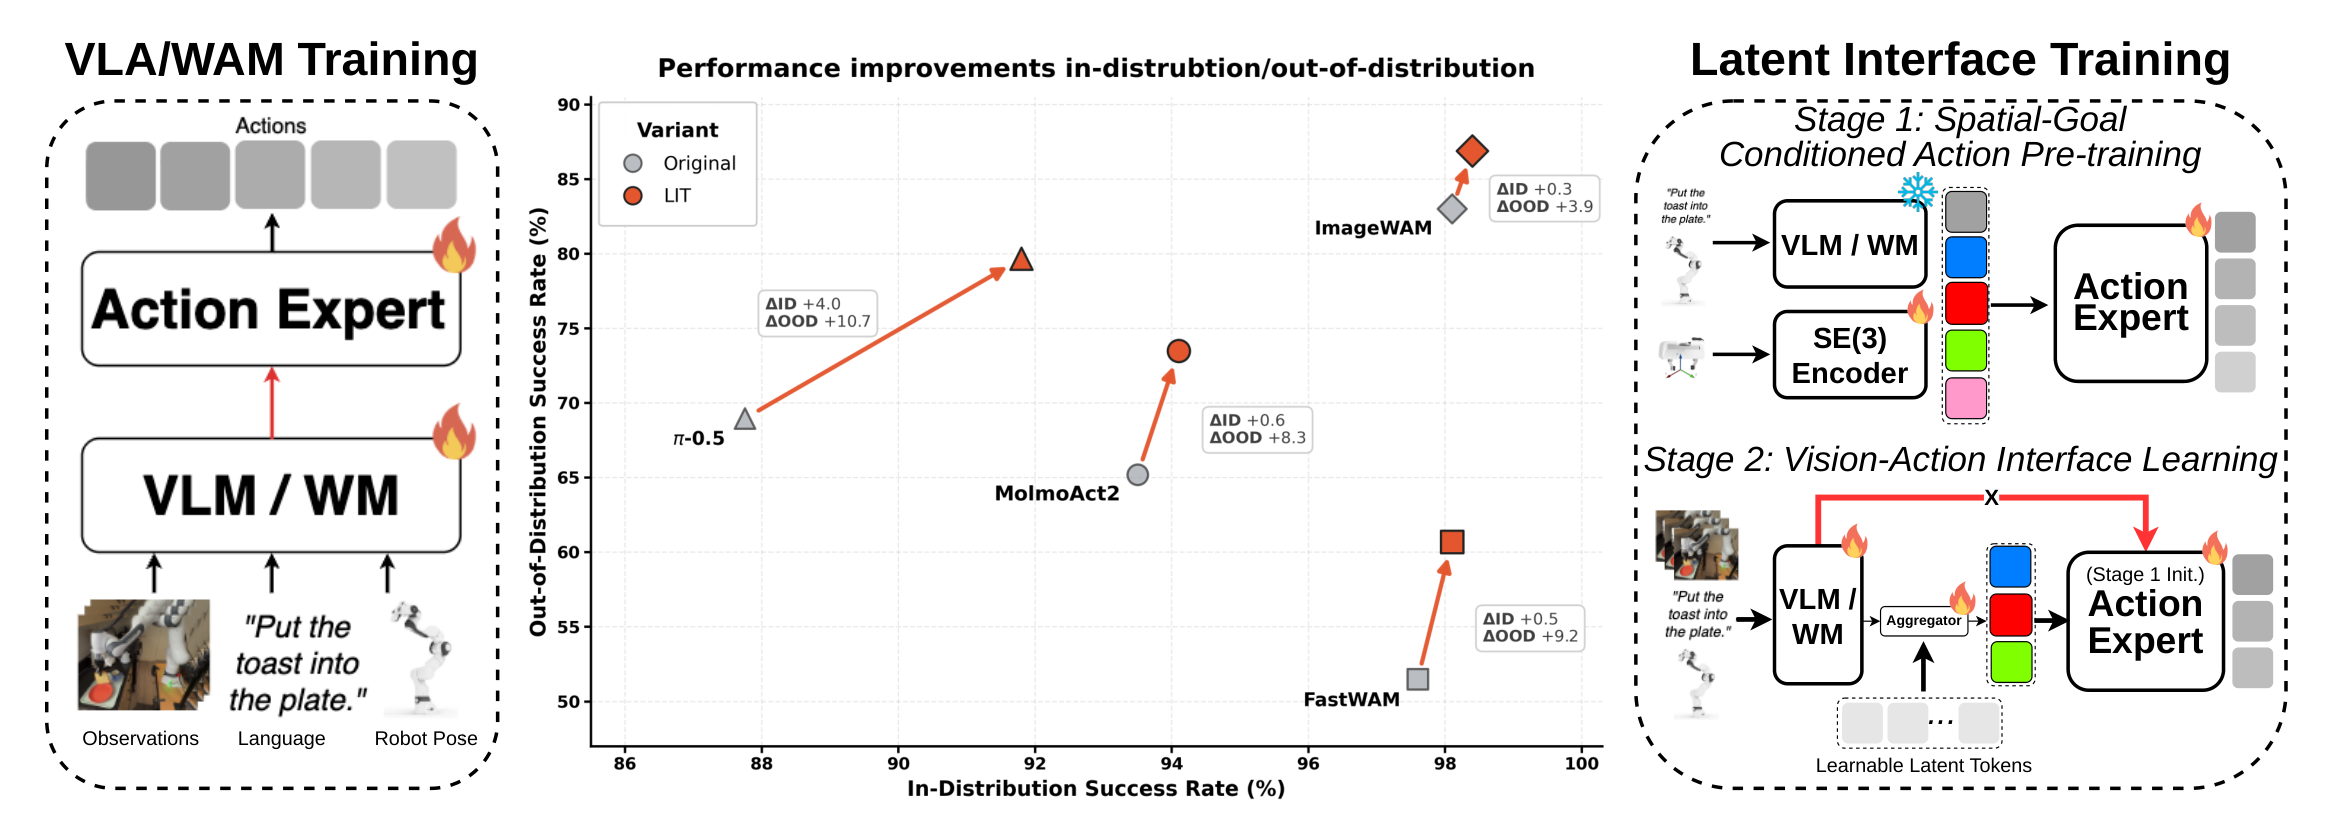
⚡ Breaking the Vision-Action Shortcut: Latent Interface Training for Generalizable Robotics Foundation Models
拆"视觉-动作捷径":两阶段 latent interface 训练。
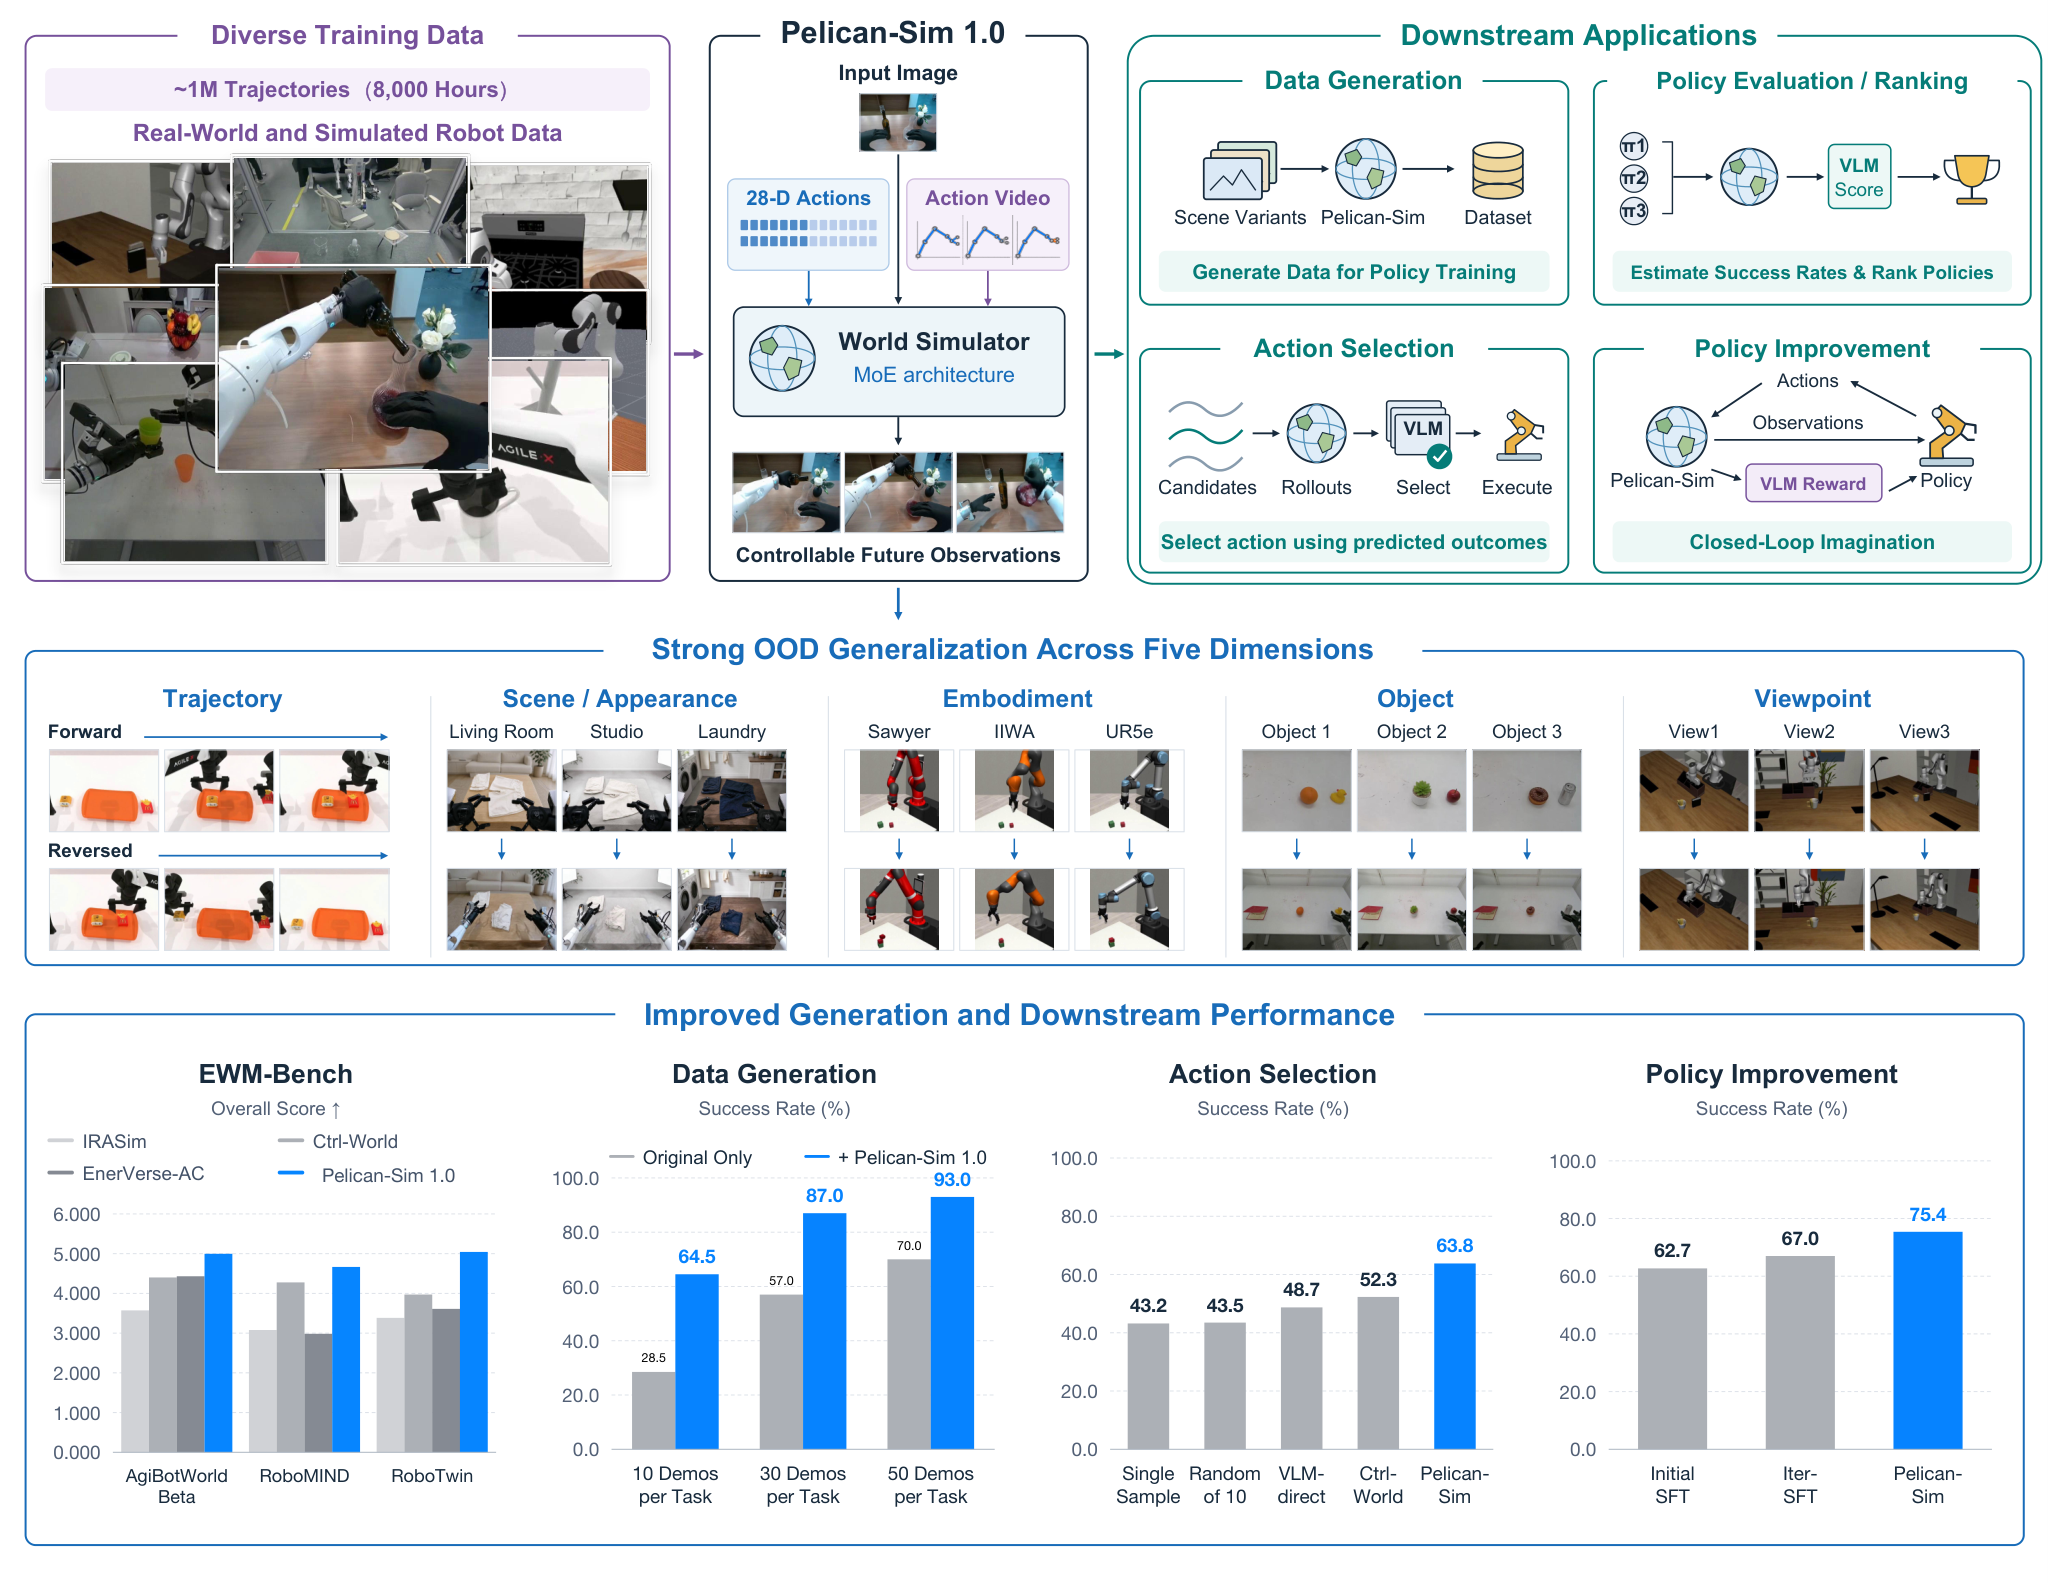
⚡ Pelican-Sim 1.0: A General World Model Simulator for Embodied Intelligence
通用世界模型模拟器技术报告:统一动作空间 + 动作-视觉注入 + 稀疏 MoE。
自动生成于 2026-09-15 · 基于 arXiv Daily Digest