今日从 arXiv 订阅中筛选 10 篇论文。
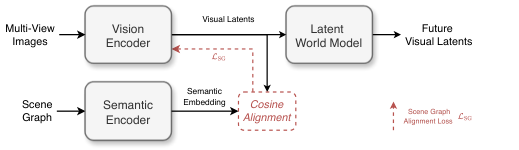
⚡ Relationally Grounded Latent World Models for Autonomous Driving
给潜世界模型喂"关系结构"特权监督:只训练时用场景图,推理时全删。
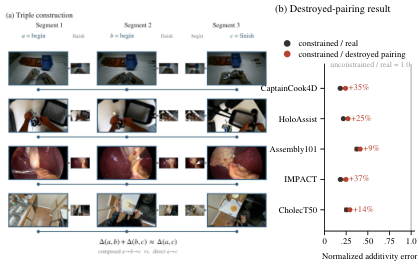
⚡ Algebraic Consistency Alone Does Not Certify Temporal Structure in Latent Action Models
拆掉潜动作模型的"免标签证书":代数恒等式对任意配对都成立,证明不了时序结构。
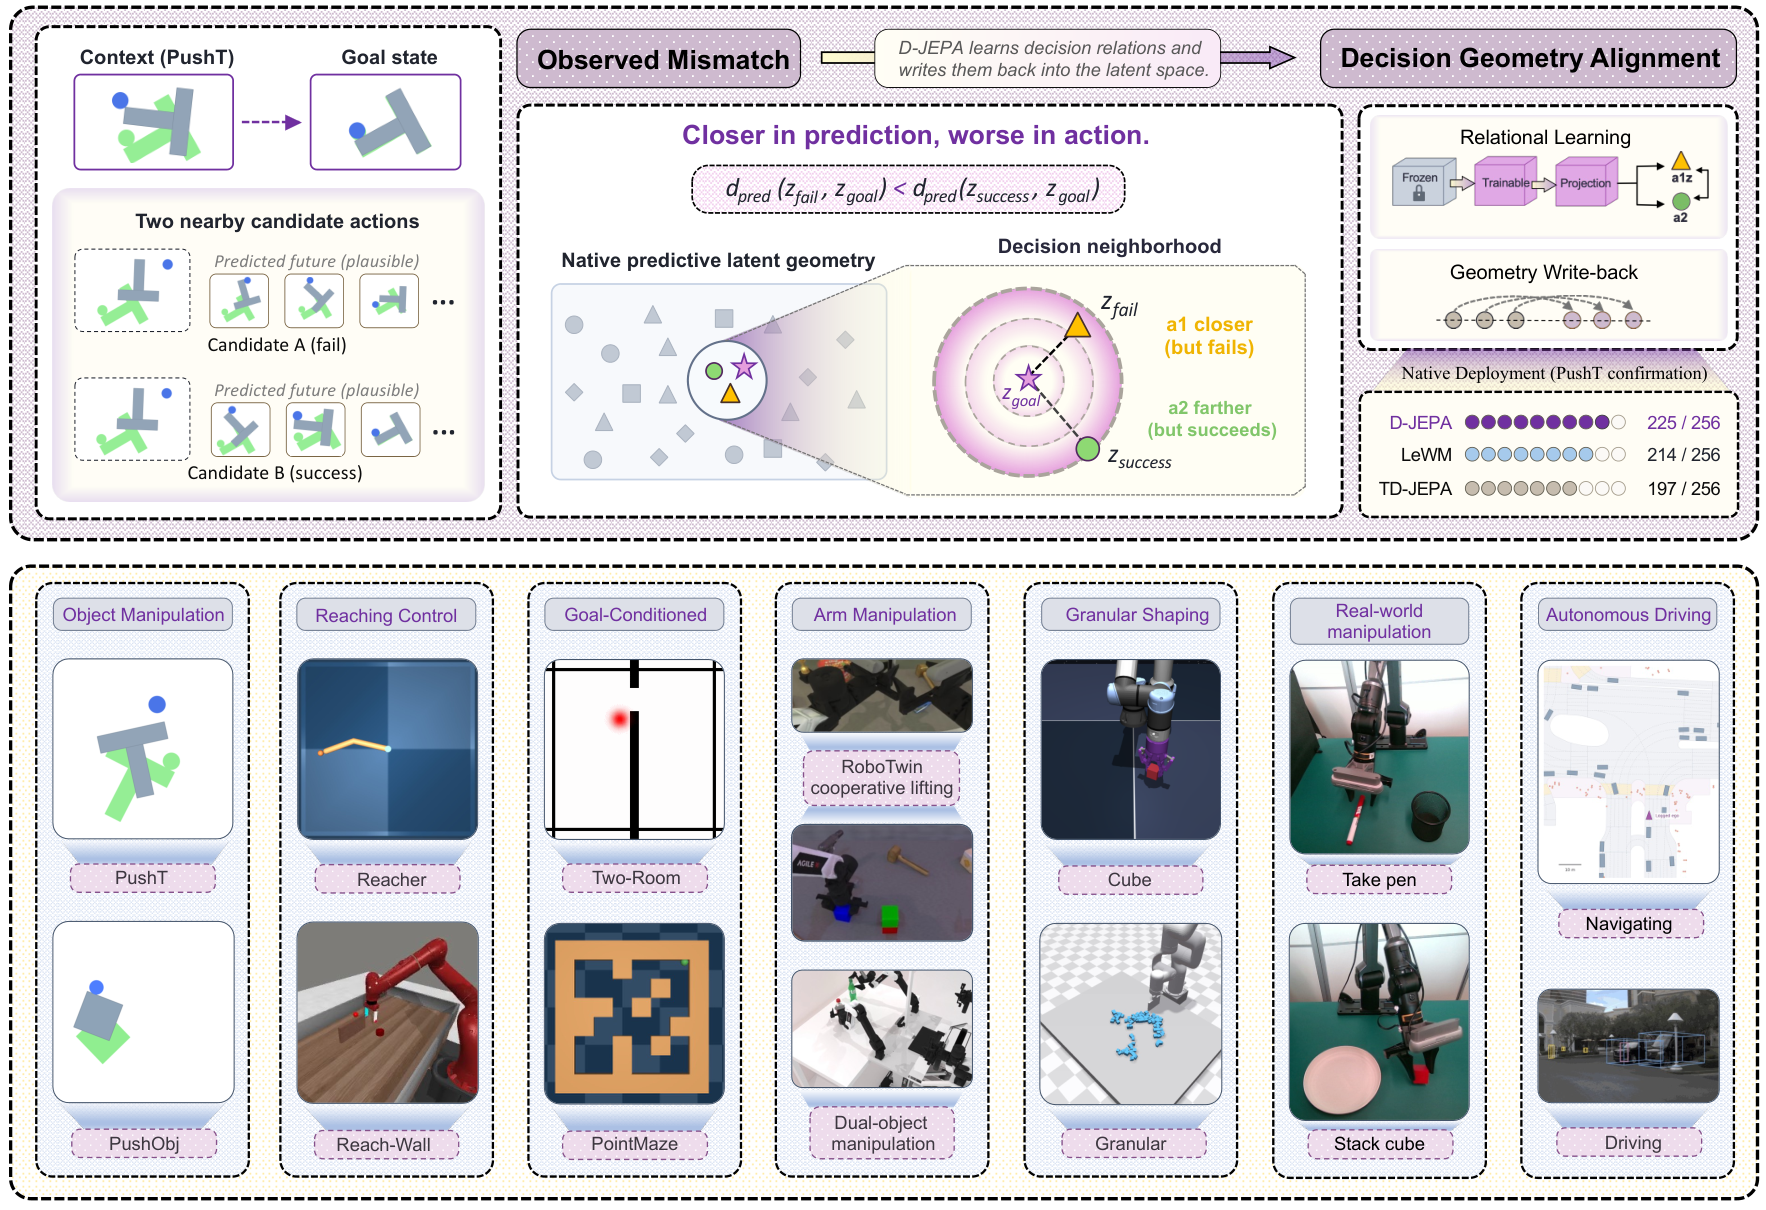
⚡ D-JEPA: A Decision-Aligned Latent World Model
预测更准不等于选得对:把"决策相关序关系"从执行结果里学出来。
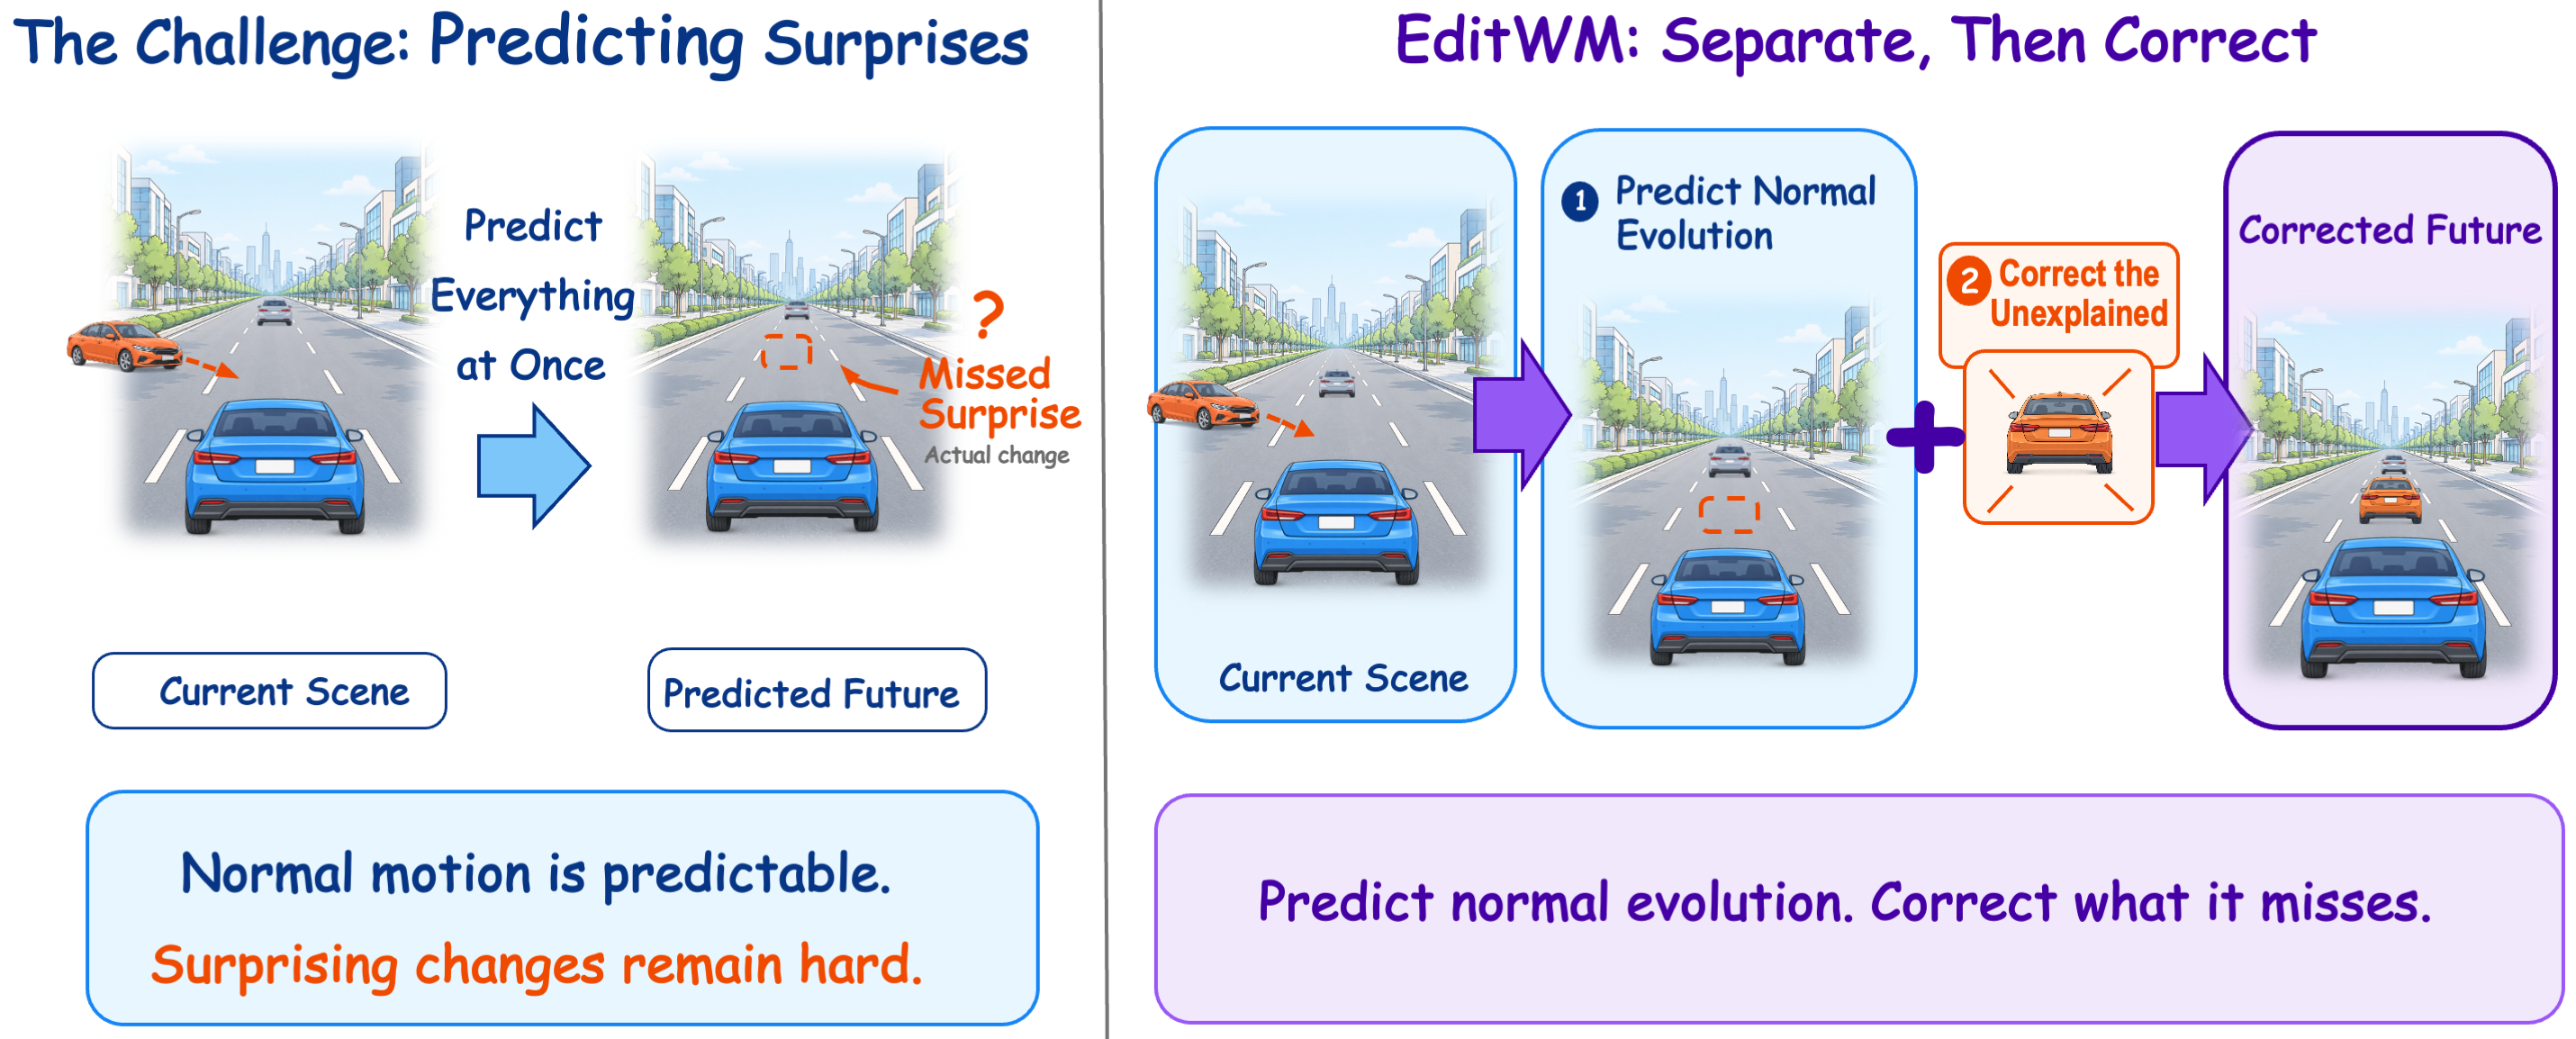
⚡ EditWM: Event-Decomposed World Modeling with Incremental Correction for End-to-End Autonomous Driving
把未来拆成"常规演化+事件驱动增量修正",只在对的地方花算力。
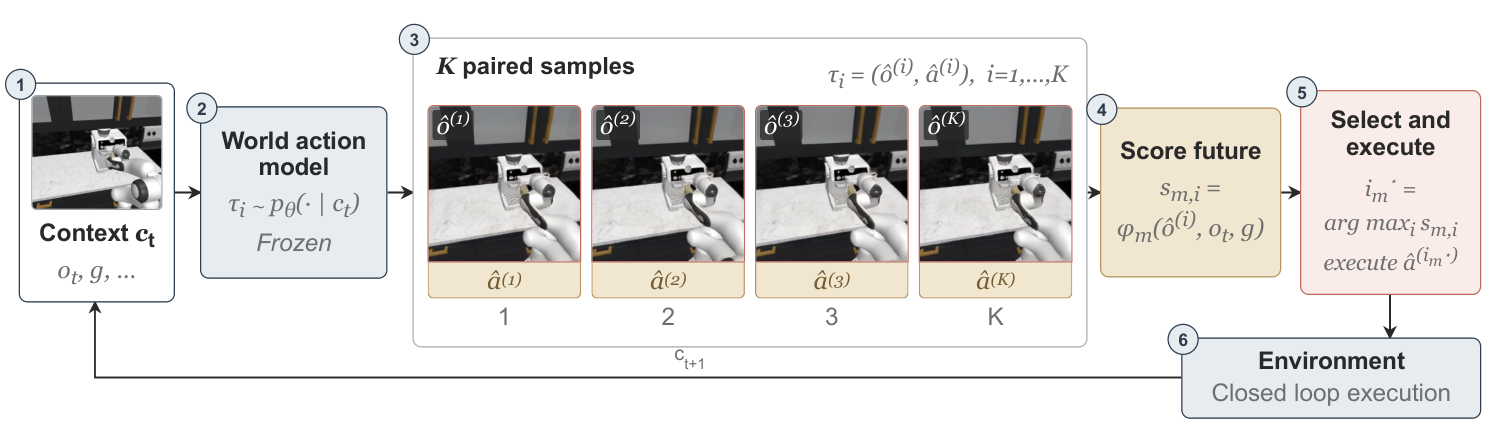
⚡ Beyond Visual Quality: A Study of Test-Time Planning with World Action Models
WAM 的想象未来能用于规划吗?oracle 上界给了,选择器回收不了。
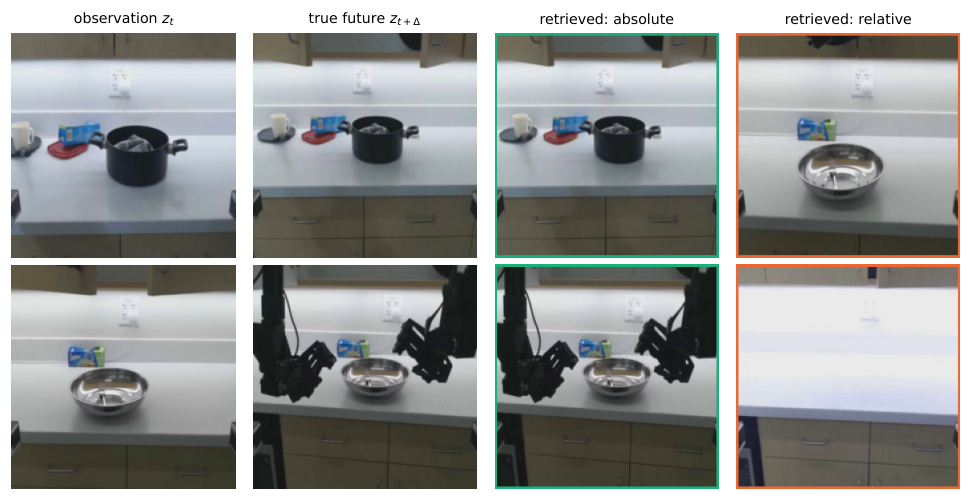
⚡ Robot World Models Are Not Invariant to How the Actions Are Written
动作写法(绝对关节 vs 增量)是静默继承的灾难:世界模型换编码就答错问题。
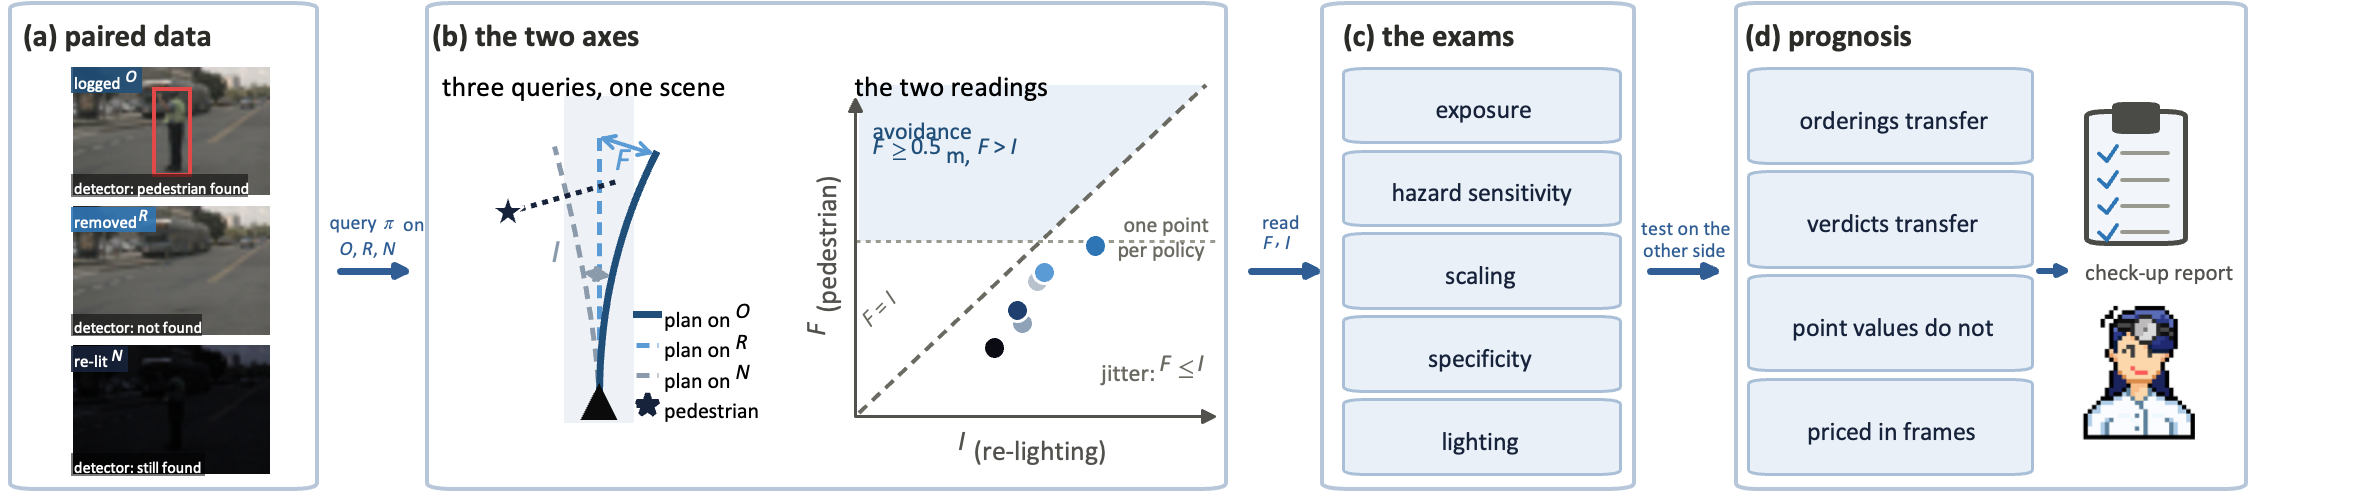
⚡ Beyond the Leaderboard: Counterfactual Diagnosis of End-to-End and VLA Driving Policies Under Domain Shift
排行榜名次预测不了新地点行为:用反事实编辑把驾驶策略读成"剖面"。
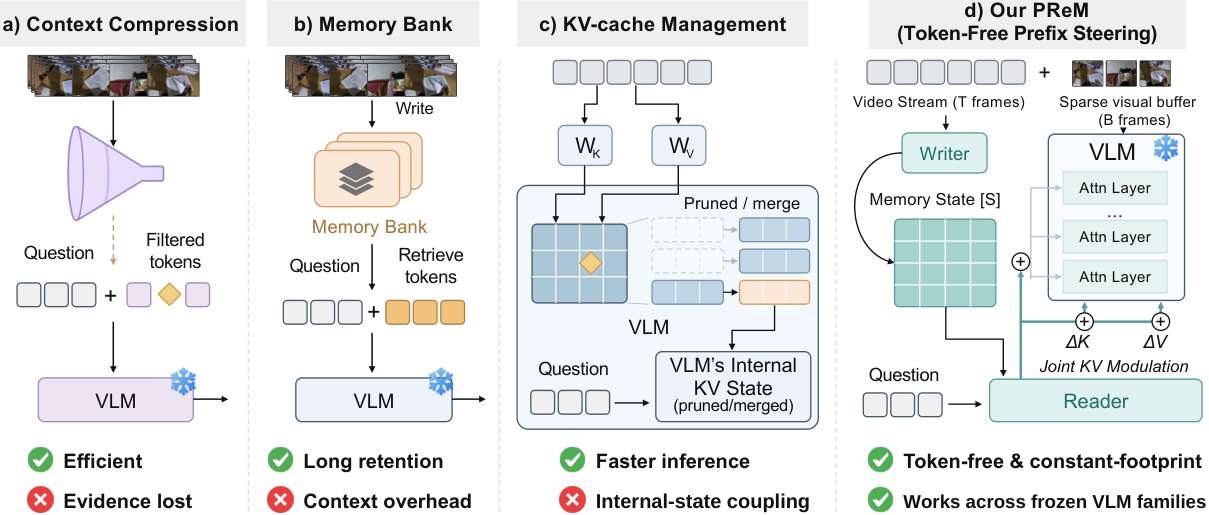
⚡ PREM: Prefix-Steered Recurrent Memory for Long-Video Understanding
长视频记忆从 token 挪进 KV 调制:冻结 VLM,write-once、query-many。
⚡ Anatomy of a Closed-Loop Collapse: A Causal Case Study of a Compressed VLA Policy
离线 0.996 的蒸馏策略闭环 0/72:一例崩溃的因果解剖。
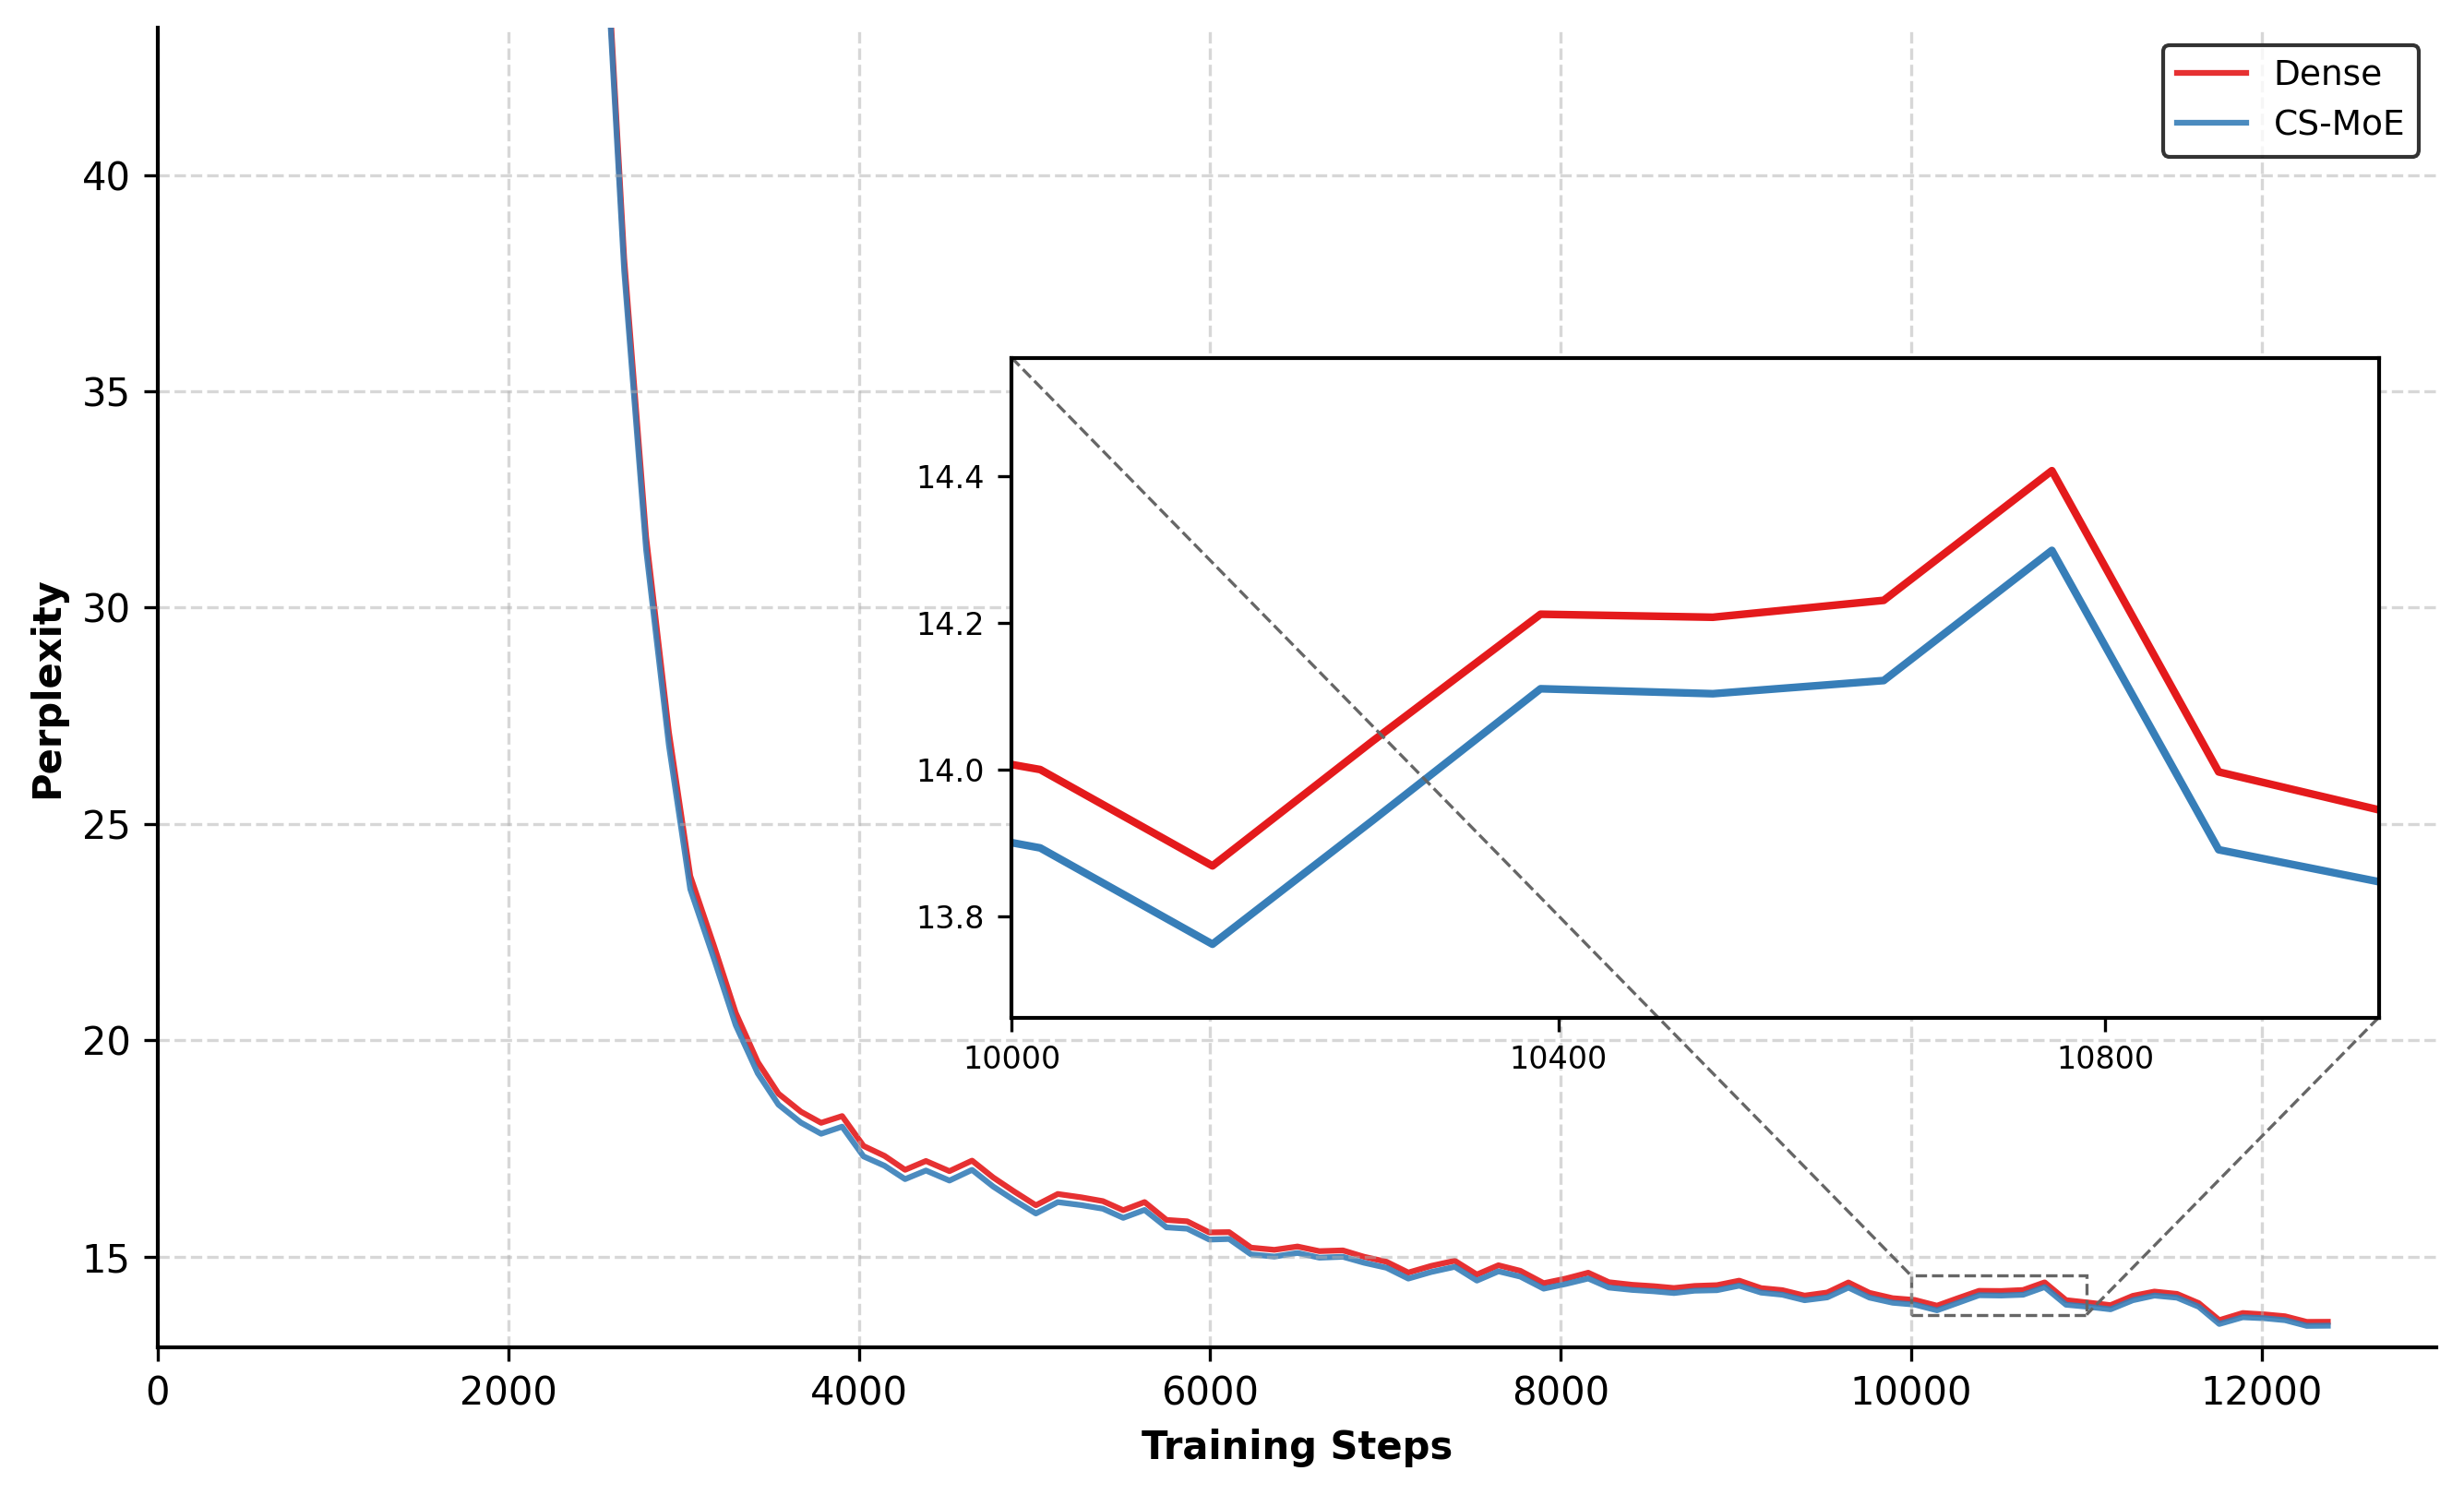
⚡ Improving Parameter Utilization by Sharing Neural Experts Across Layers in Transformers
层间参数冗余的另一种吃法:全局共享专家池。
自动生成于 2026-09-23 · 基于 arXiv Daily Digest