今日从 arXiv 订阅中筛选 10 篇论文。
⚡ You Only Need 2/3 of the Chosen Experts: An Empirical Study of Dynamic Expert Pruning in Fine-Grained MoE LLMs
细粒度 MoE 动态专家剪枝的系统实证:保留 2/3 选中专家 = 98.8% 性能 + 1.2-1.7× 加速。
⚡ Beyond Reconstruction Error: Analytical and Data-Driven Action Tokenization for Autoregressive Vision-Language-Action Models
动作 tokenization 的重建误差 ≠ 闭环控制效用。
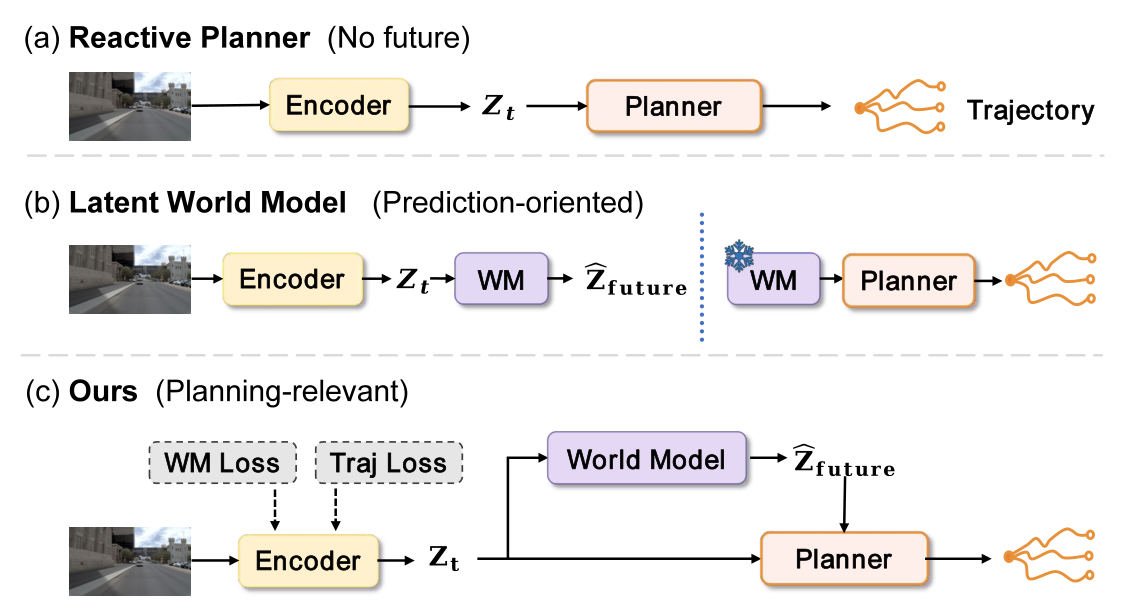
⚡ ForeDrive: Foresight-Guided End-to-End Autonomous Driving with a Planning-Relevant Latent World Model
规划相关的 latent world model:把预测表示直接做成规划条件信号。
⚡ RoboTwin-Phys: Do WAMs and VLAs Understand the Physical World?
把物理条件多样性做成显式评测维度:13 个物理属性连续变化。
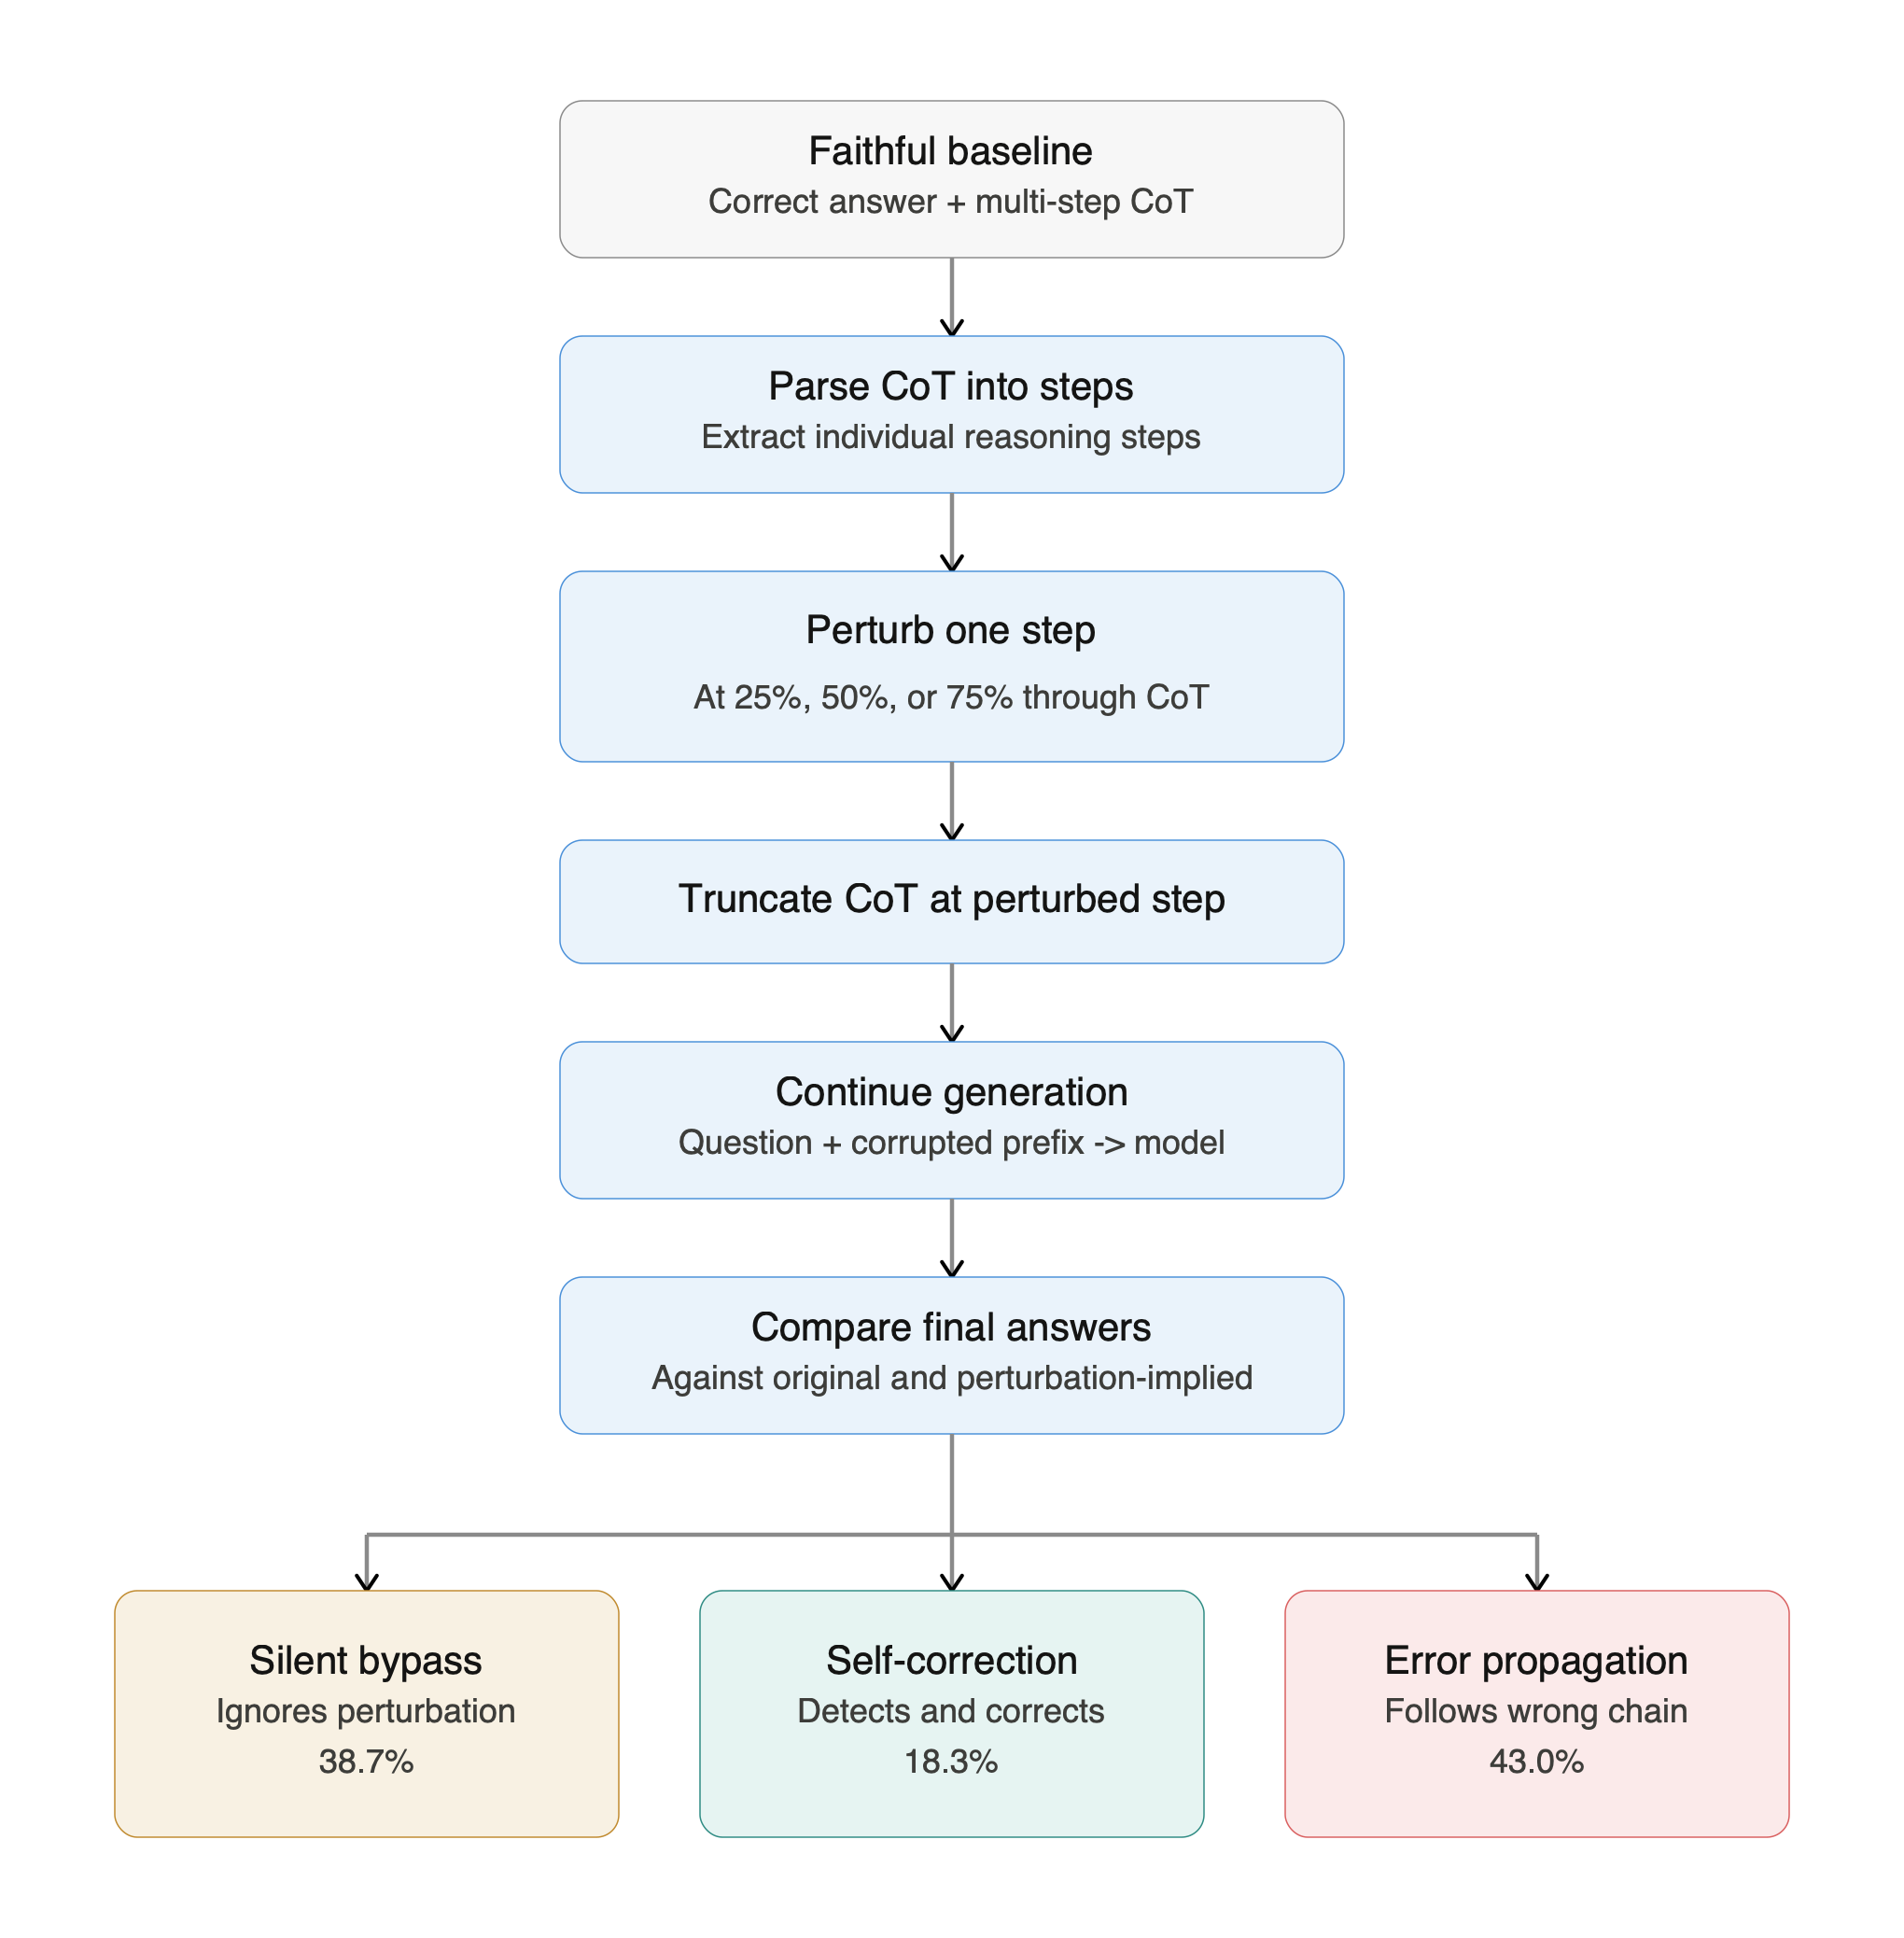
⚡ From Decorative to Load-Bearing: Task Difficulty Shapes the Causal Role of Chain-of-Thought
CoT 的承重因果测试:简单题上模型绕过自己的推理,难题上才跟着污染步骤走。
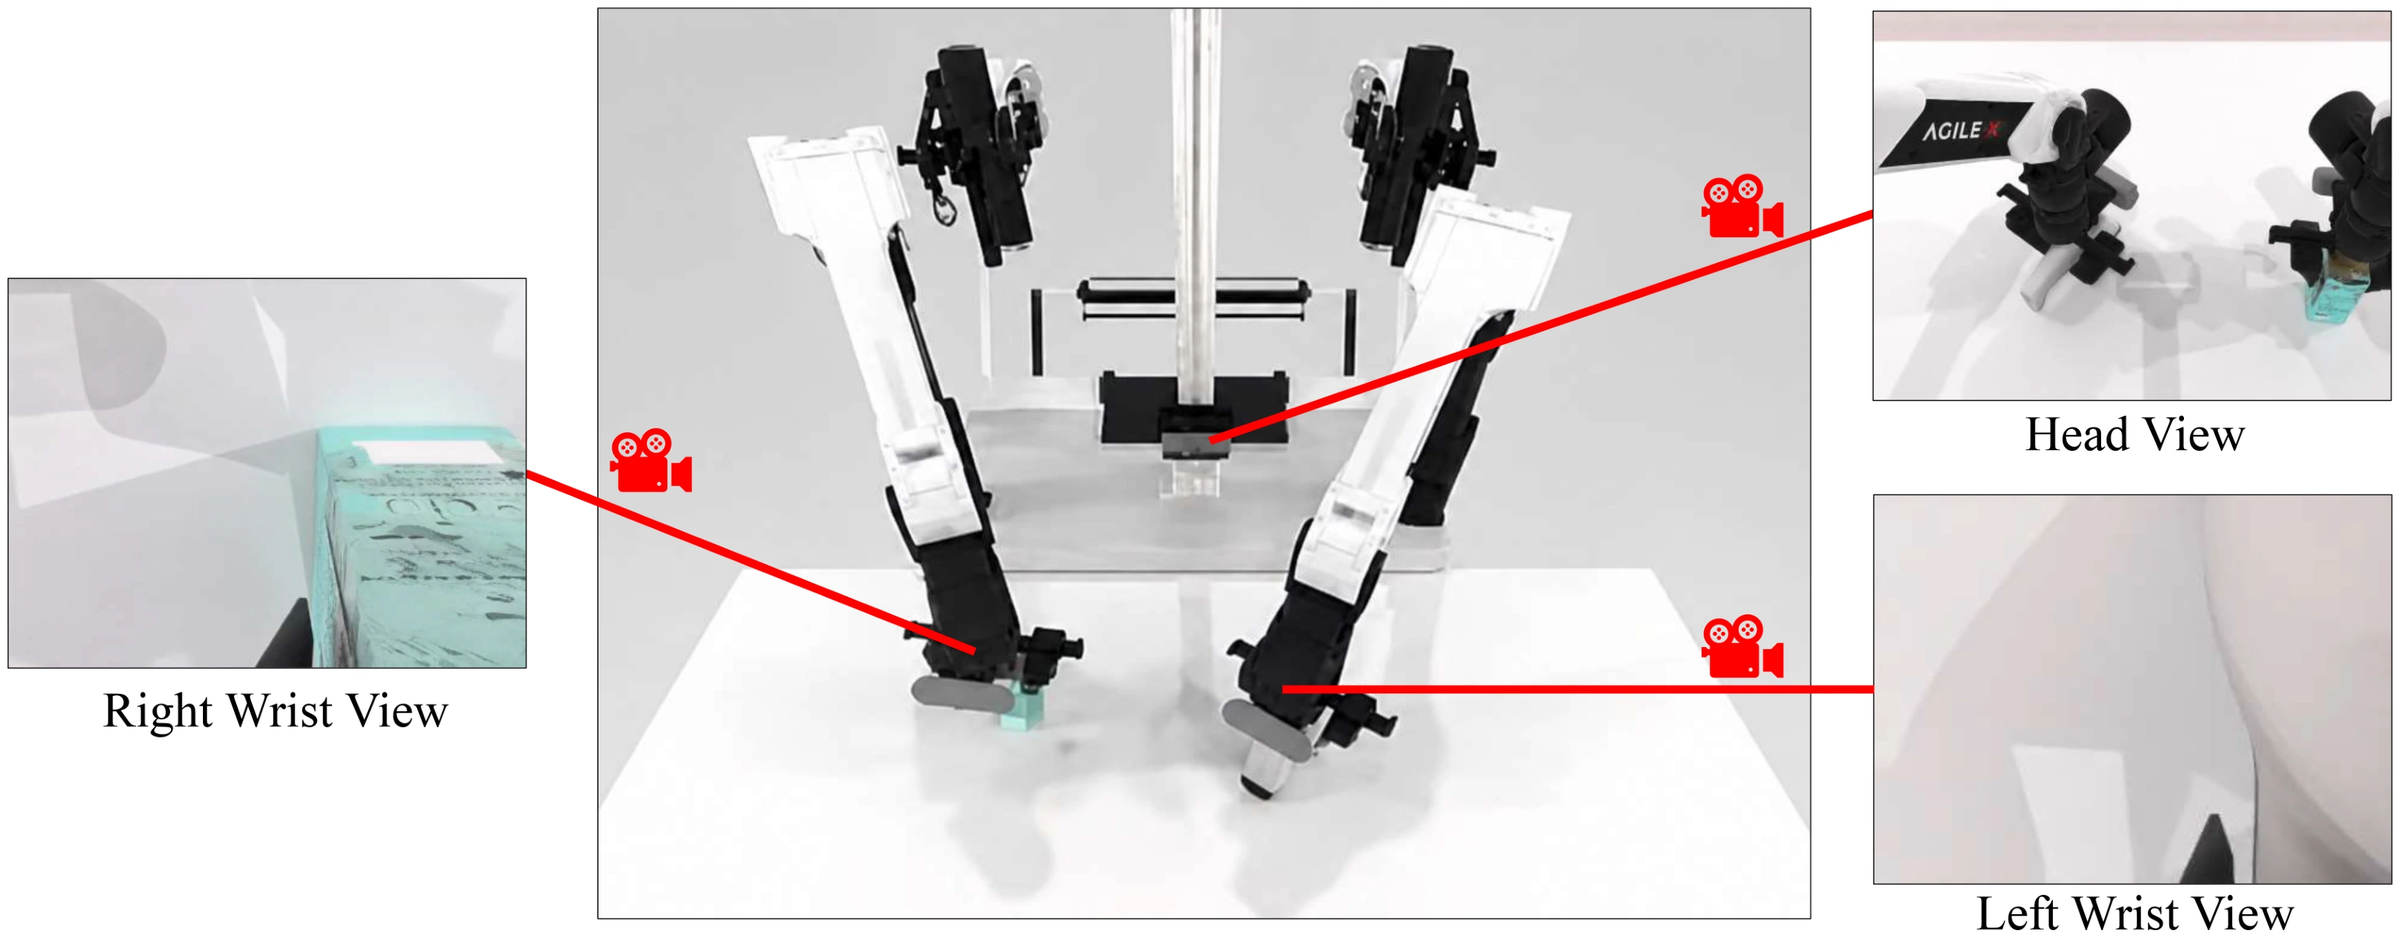
⚡ TriWorldBench: A Tri-View Consistency Perspective on Embodied World Models
具身世界模型三视角一致性基准:单看合理≠同一动作的一致预测。
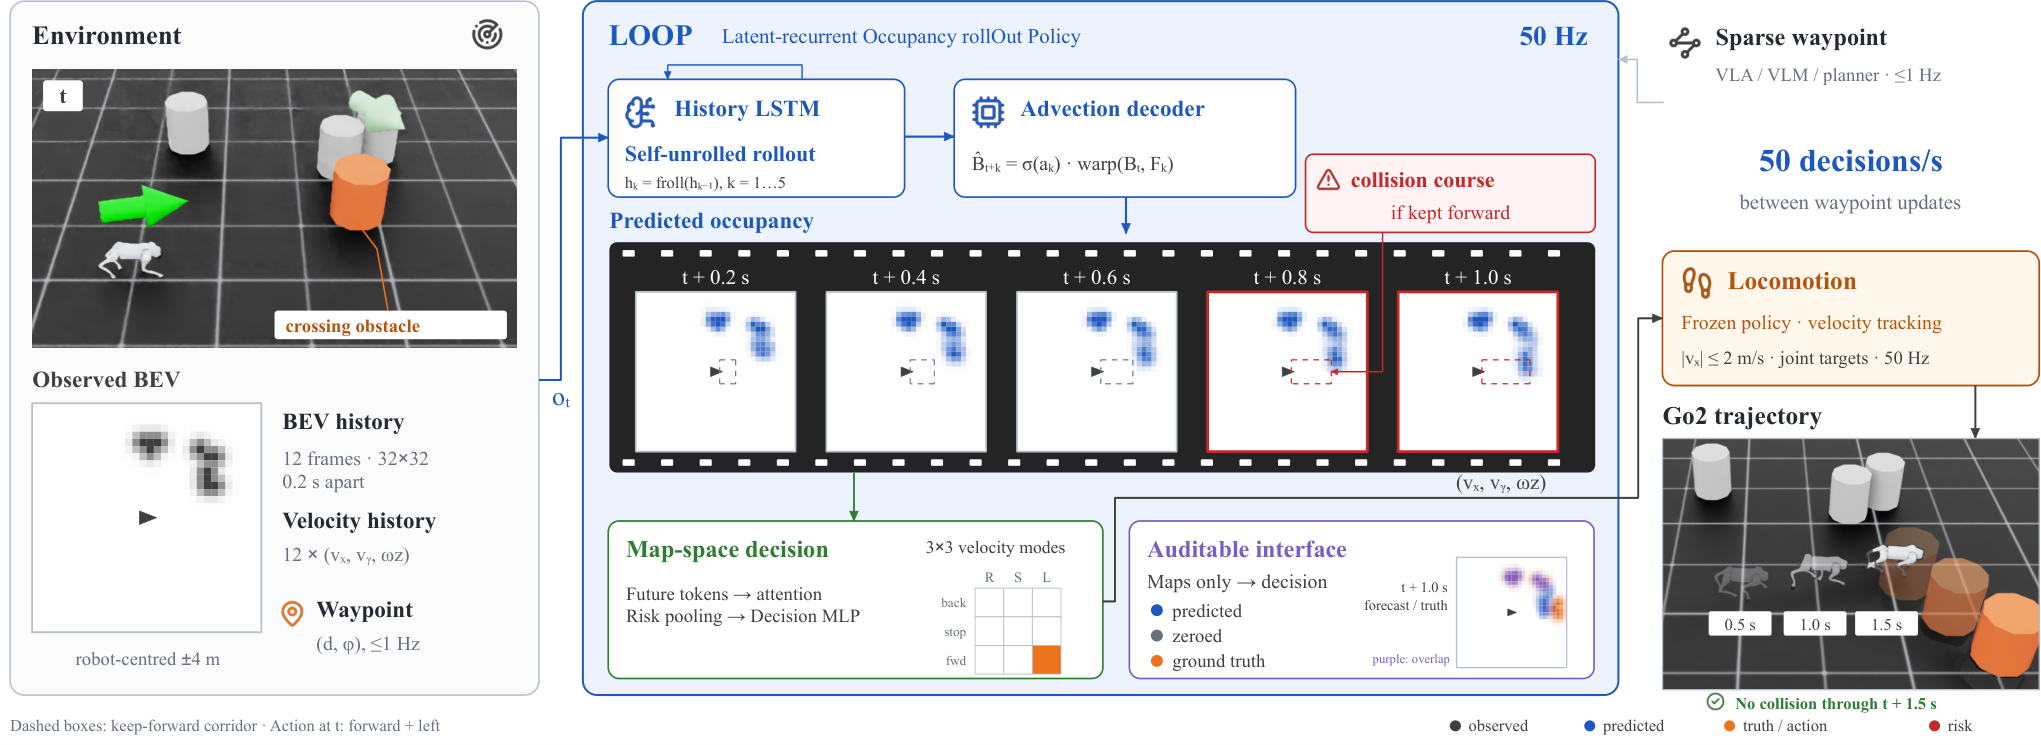
⚡ Predict Before You Step: Auditable Occupancy Forecasting for Dynamic Obstacle Avoidance under Sparse Guidance
可审计占用预测做动态避障:预测接口显式可检查、可替换。
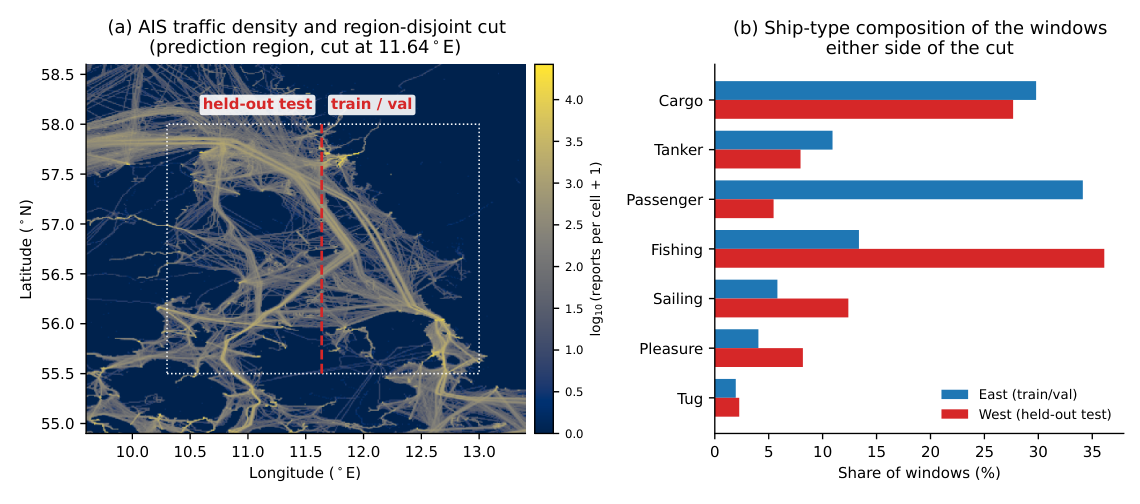
⚡ Protocol before progress: leakage-aware evaluation of AIS trajectory prediction
AIS 轨迹预测:进展该归给协议还是架构?先测协议。
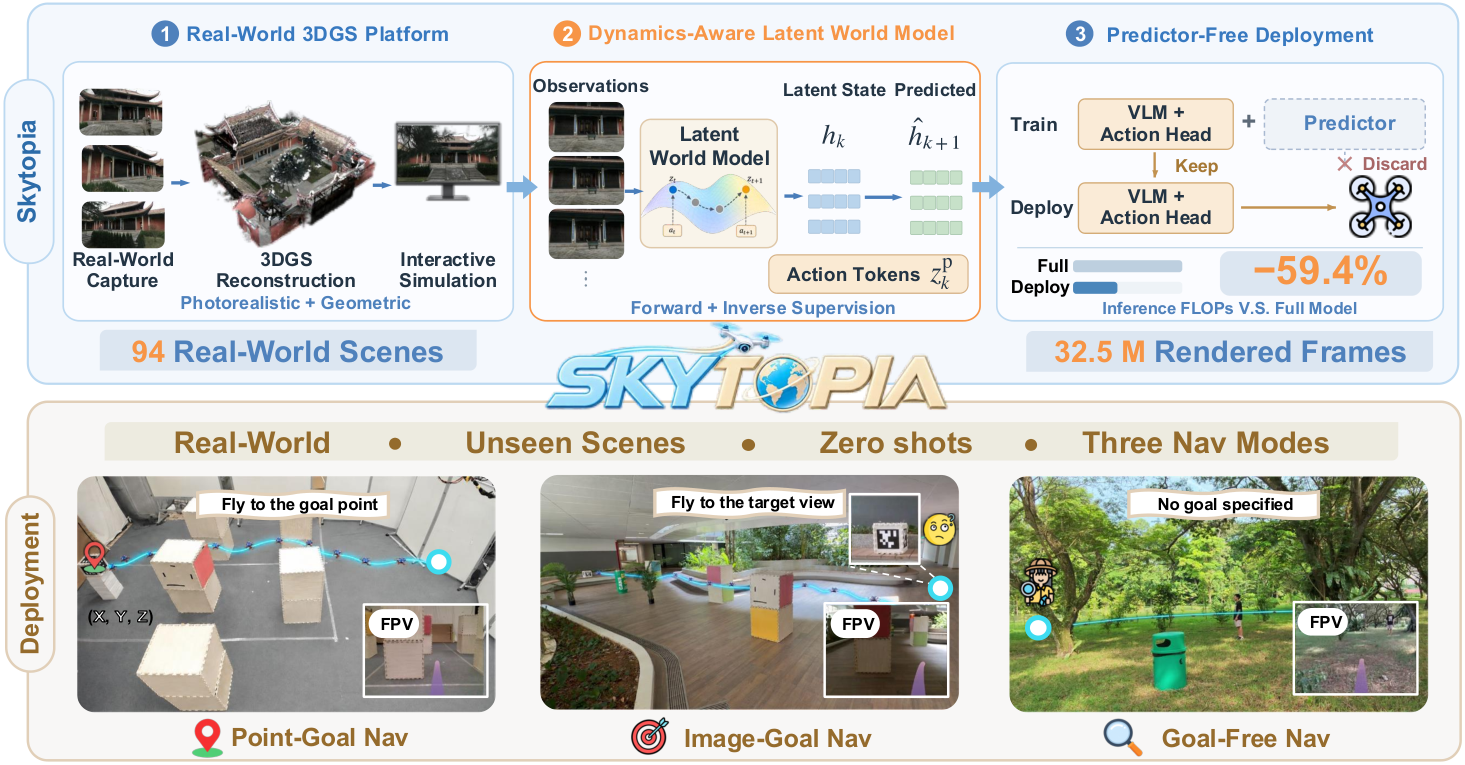
⚡ Skytopia: Monocular Drone Navigation with Action-Conditioned Latent World Models
单目无人机导航:"要的不是预测,而是产生预测的表示"。
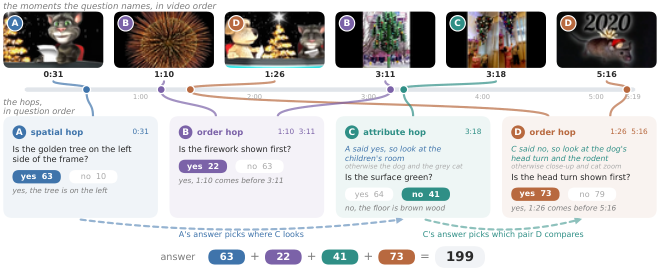
⚡ Video-HopChain: Multi-Hop Questions and Confidence-Gated Exploration for Video Reasoning Models
多跳视频问答:把视觉证据链做成可验证 RLVR 信号。
自动生成于 2026-09-24 · 基于 arXiv Daily Digest