今日从 arXiv 订阅中筛选 10 篇论文。
⚡ Beneath the Scores: Rethinking Hallucination Evaluation for Video Understanding Models
视频理解 agent 幻觉评估的因果重建:grounding 是下游错误主源(≈破坏视觉观测的 4 倍),错误证据比缺失证据更害。
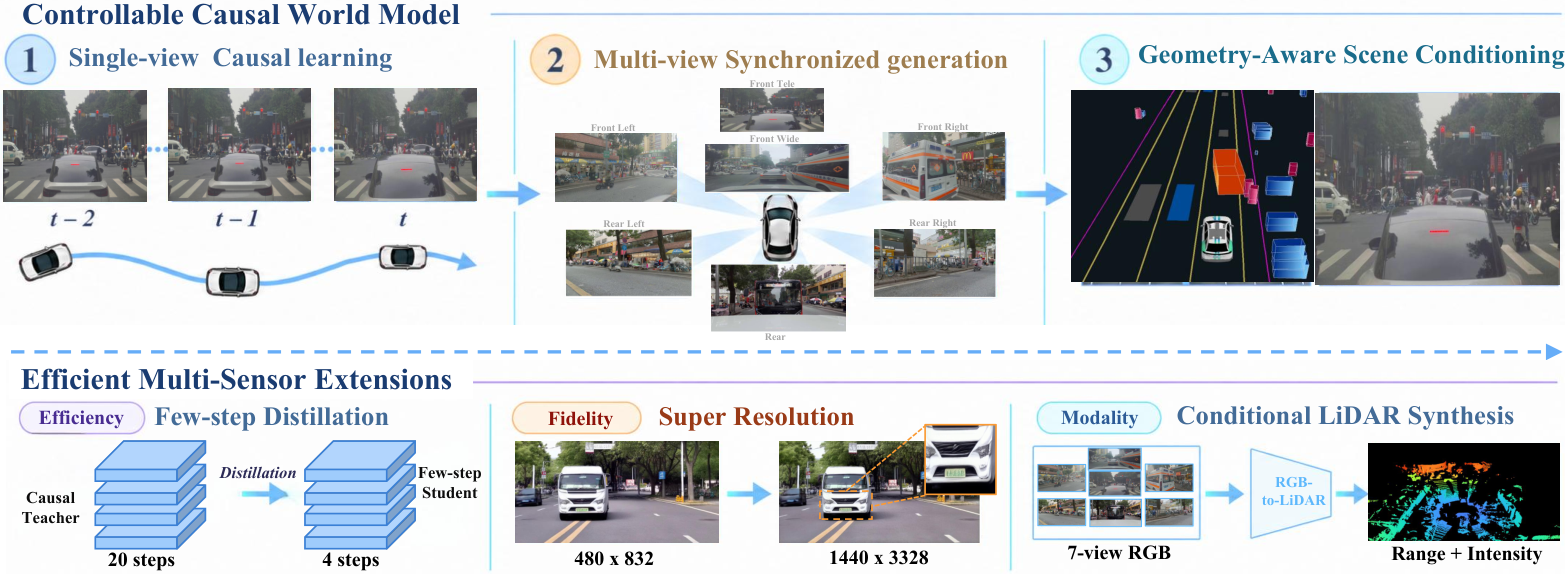
⚡ HelloWorld: Towards Practical Applications of Generative Driving World Models
驾驶世界模型的规模化系统:2B 模型、7 摄像头同步生成 + 条件 LiDAR、少步蒸馏,全维度评估。
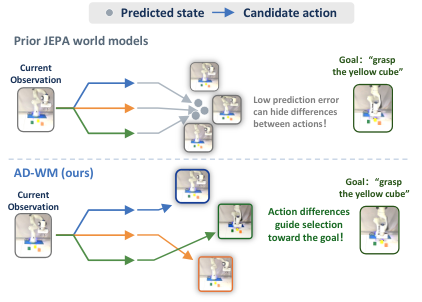
⚡ AD-WM: Action-Discriminative World Models for Counterfactual Model Predictive Control
反事实 MPC 的动作判别世界模型:OGBench-Cube hard-start 3.7%→52.0%,并给出"预测误差不跟随闭环成功"的诊断。
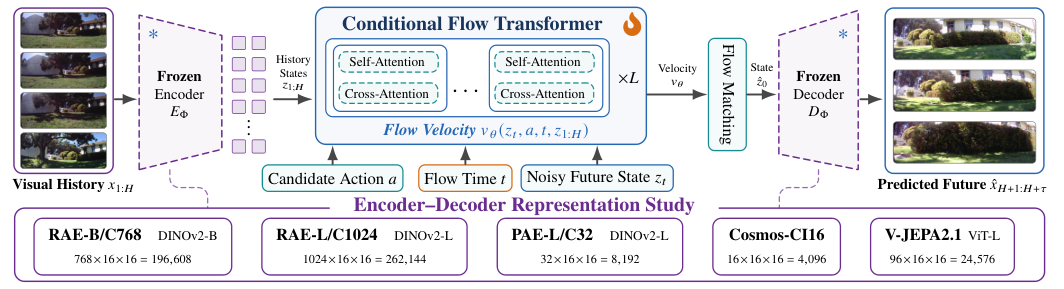
⚡ Visual Representation and History Modeling for Navigation World Models
导航世界模型的表示之问:5 种冻结表示的优劣随目标而变,历史计算可复用。
⚡ Aim Short to Reach Far: Your Frozen World Model Can Plan Better Than You Think
冻结世界模型的目标位置诊断:Anchored Planning 零训练全面超原版 LeWM planner。
⚡ Representation World Model: Learning States, Transition and Executable Plans in Representation
表示世界模型:规划直接在表示几何里发生,无递归 rollout、无动作空间搜索。
⚡ Safety-oriented pedestrian trajectory prediction at urban intersections using time-to-collision and crossing-zone context
安全导向行人轨迹预测:TTC+过街上下文,"超差计数"指标压大误差。
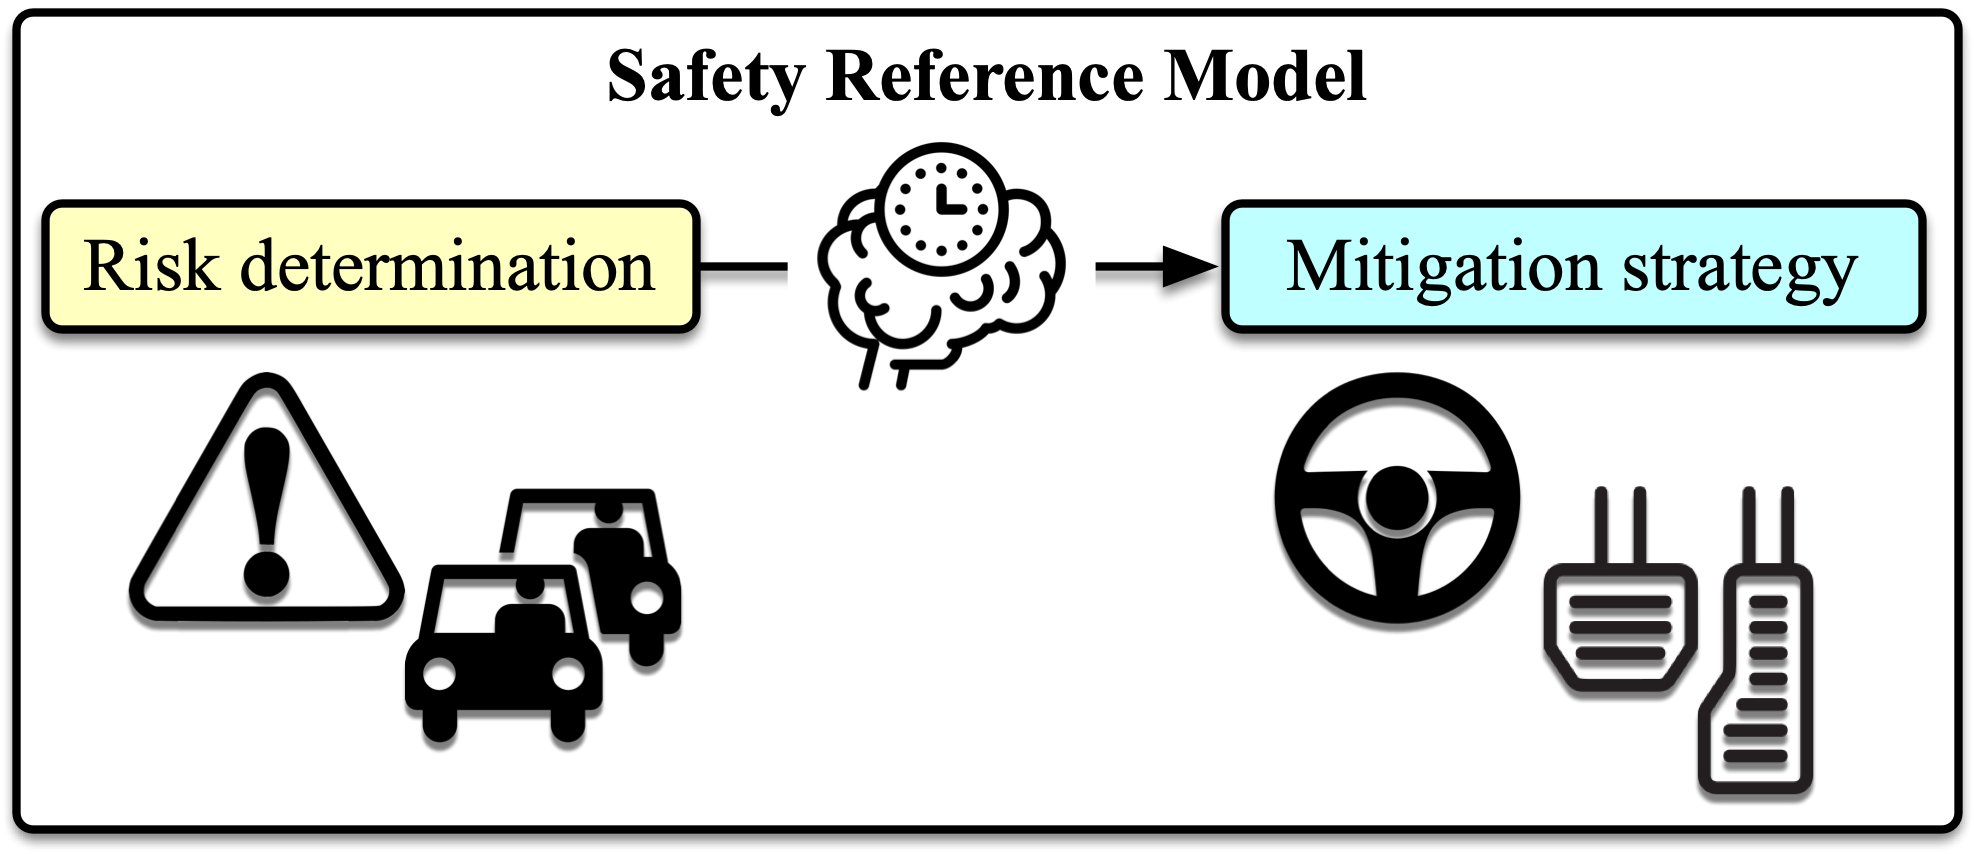
⚡ Combining Evasive and Braking Reactions for Safety Reference Models in Automated Vehicles
ADS 场景测试的"谨慎人类驾驶员"基准:制动+避让混合状态机,可避免碰撞包络扩大。
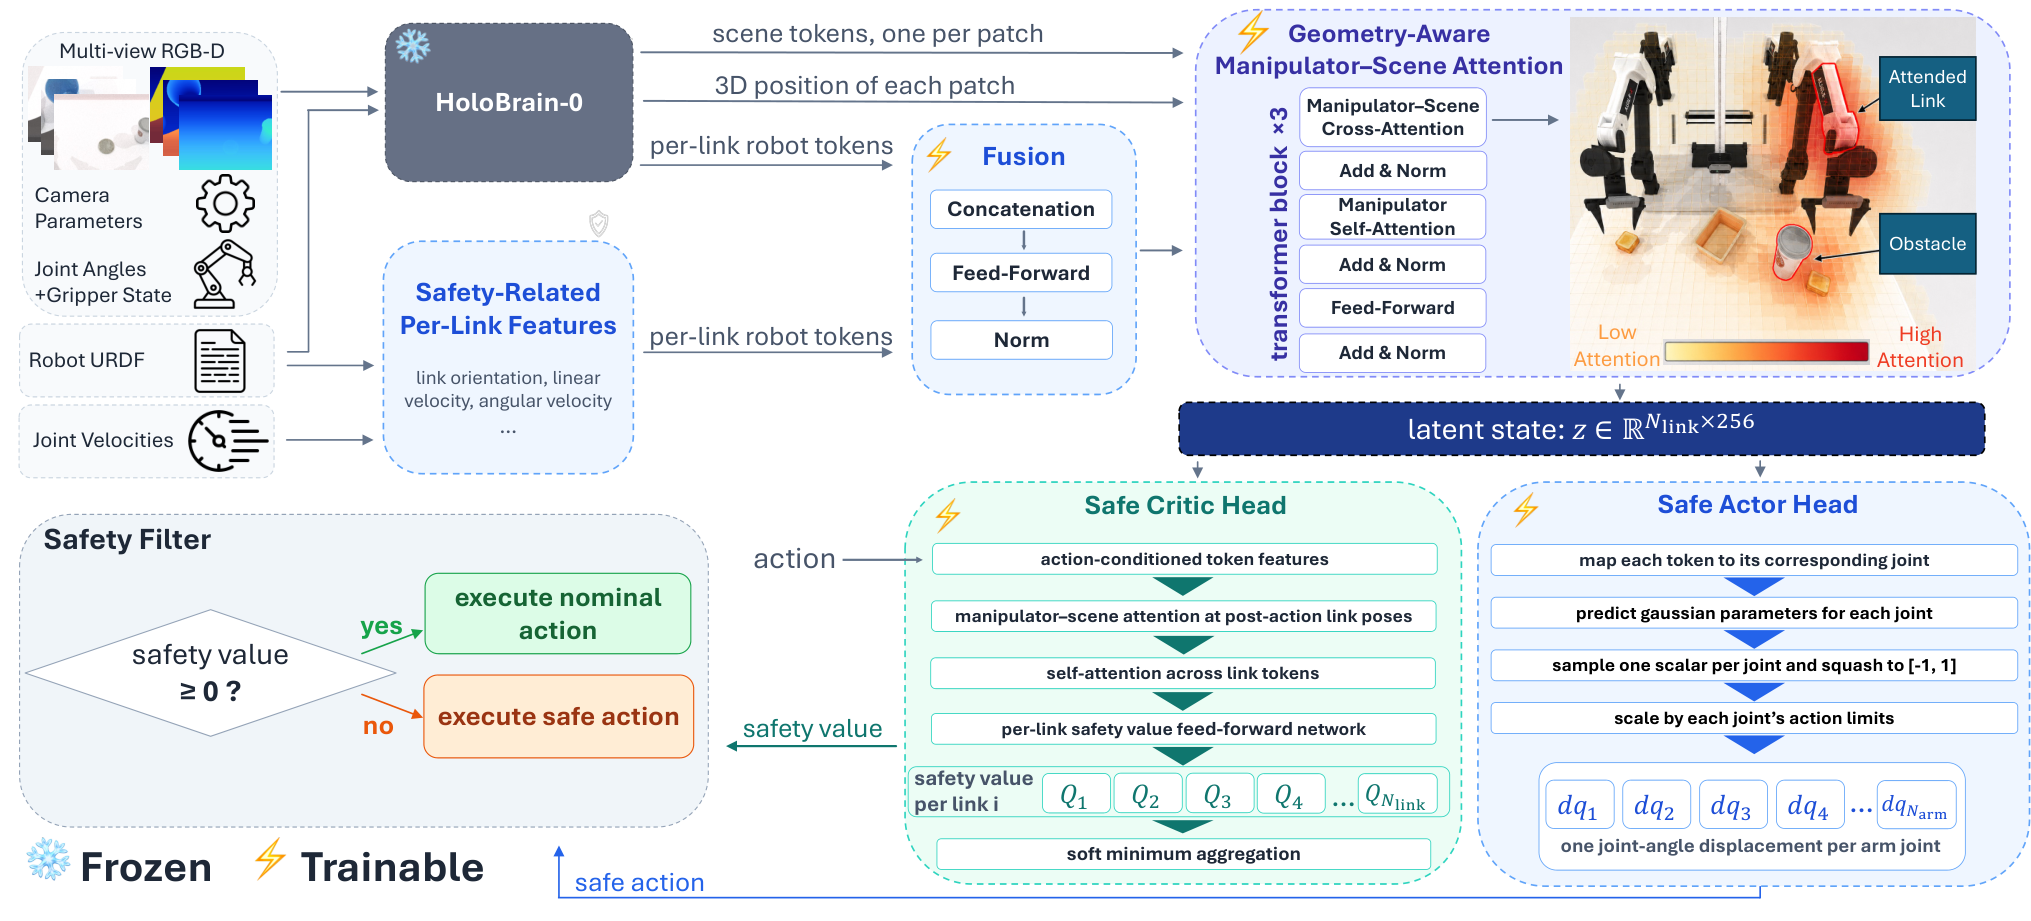
⚡ CrossSafe: Towards Cross-Embodiment Latent Safety Filters
跨形态潜空间安全滤波:安全推理共享、安全实现随身体,5 形态零样本泛化。
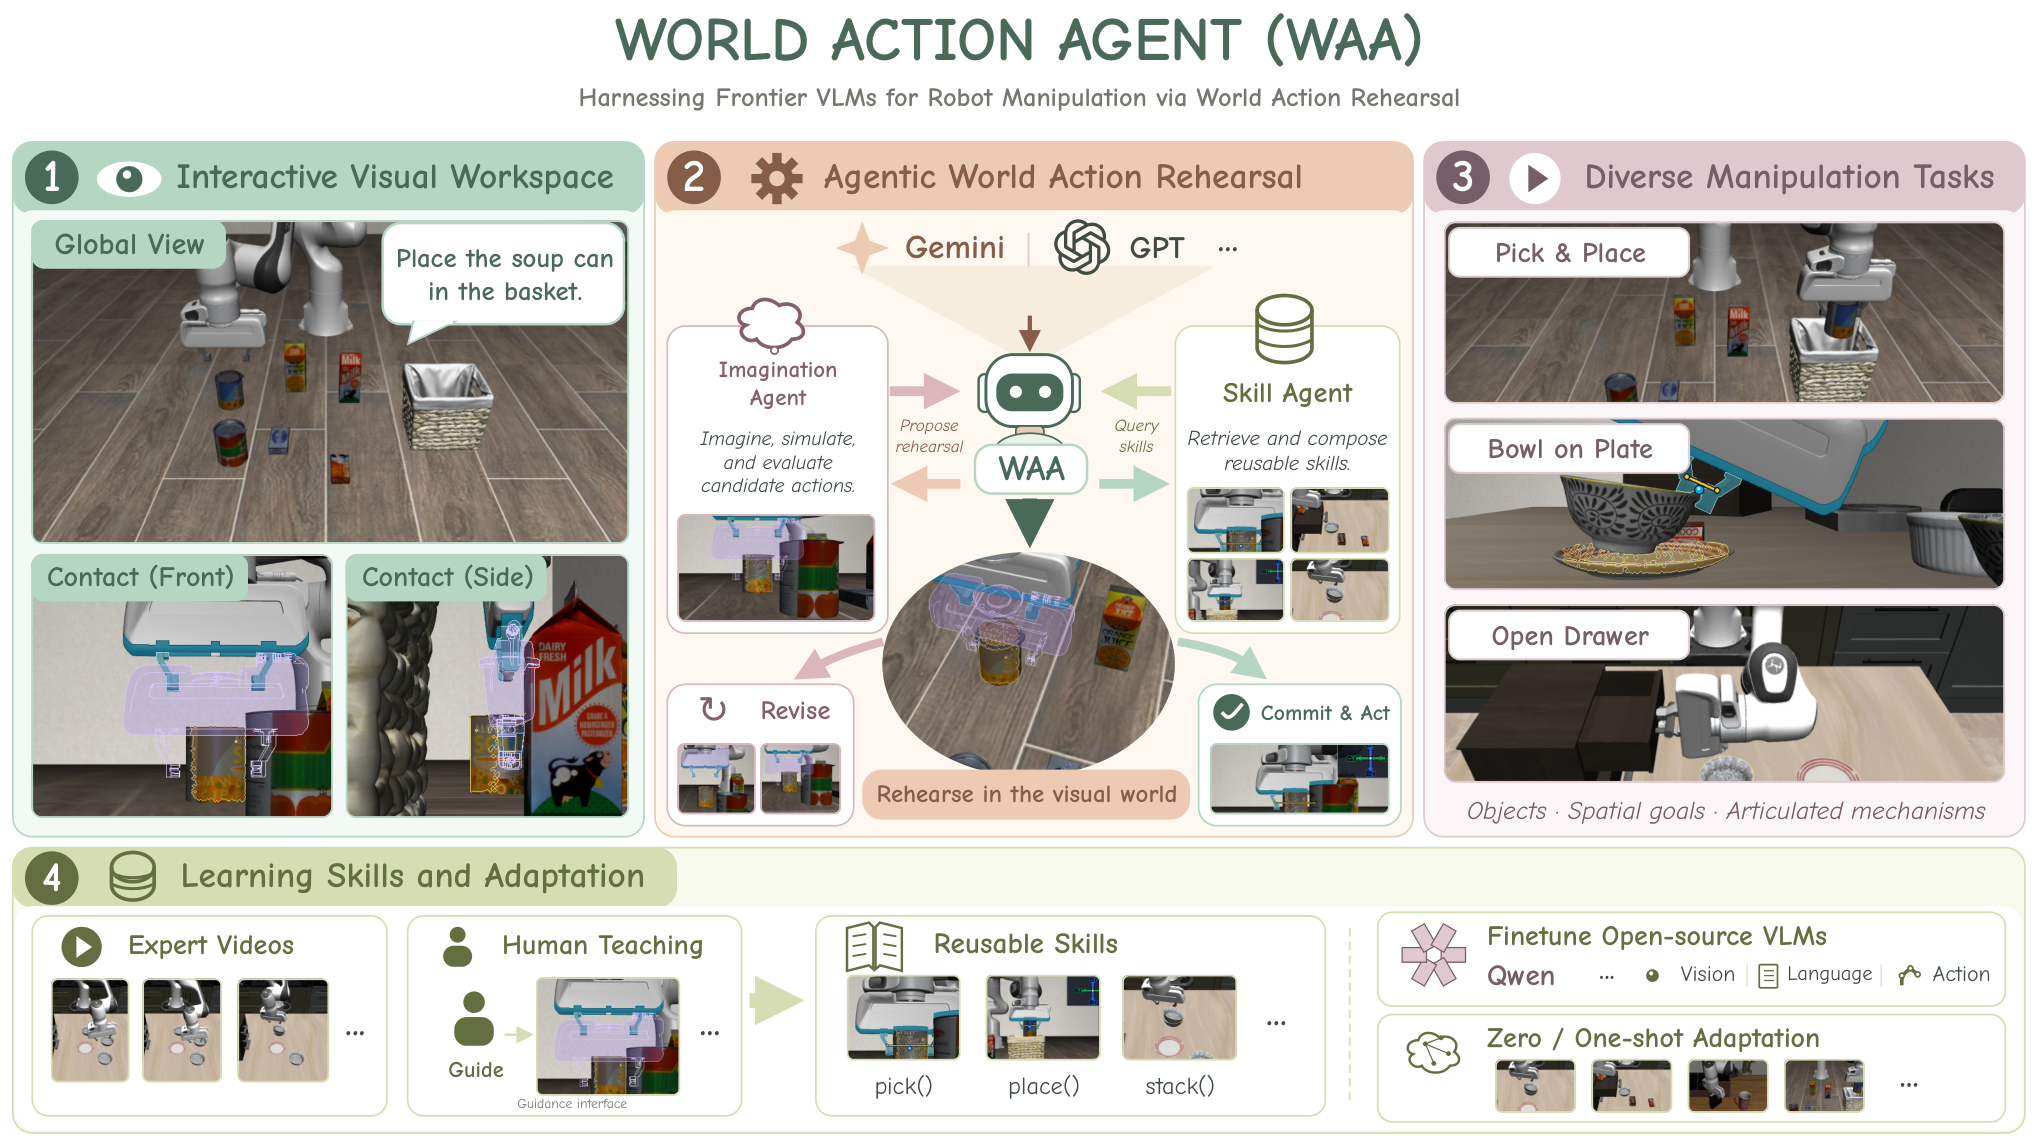
⚡ World Action Agent: Harnessing VLMs for Robot Manipulation via World Action Rehearsal
VLM 开机器人:视觉动作工作台(接触视图/动作彩排/视野内纠偏)+ 技能演化,LIBERO-Pro 75.6%。
自动生成于 2026-09-26 · 基于 arXiv Daily Digest