今日从 arXiv 订阅中筛选 10 篇论文。
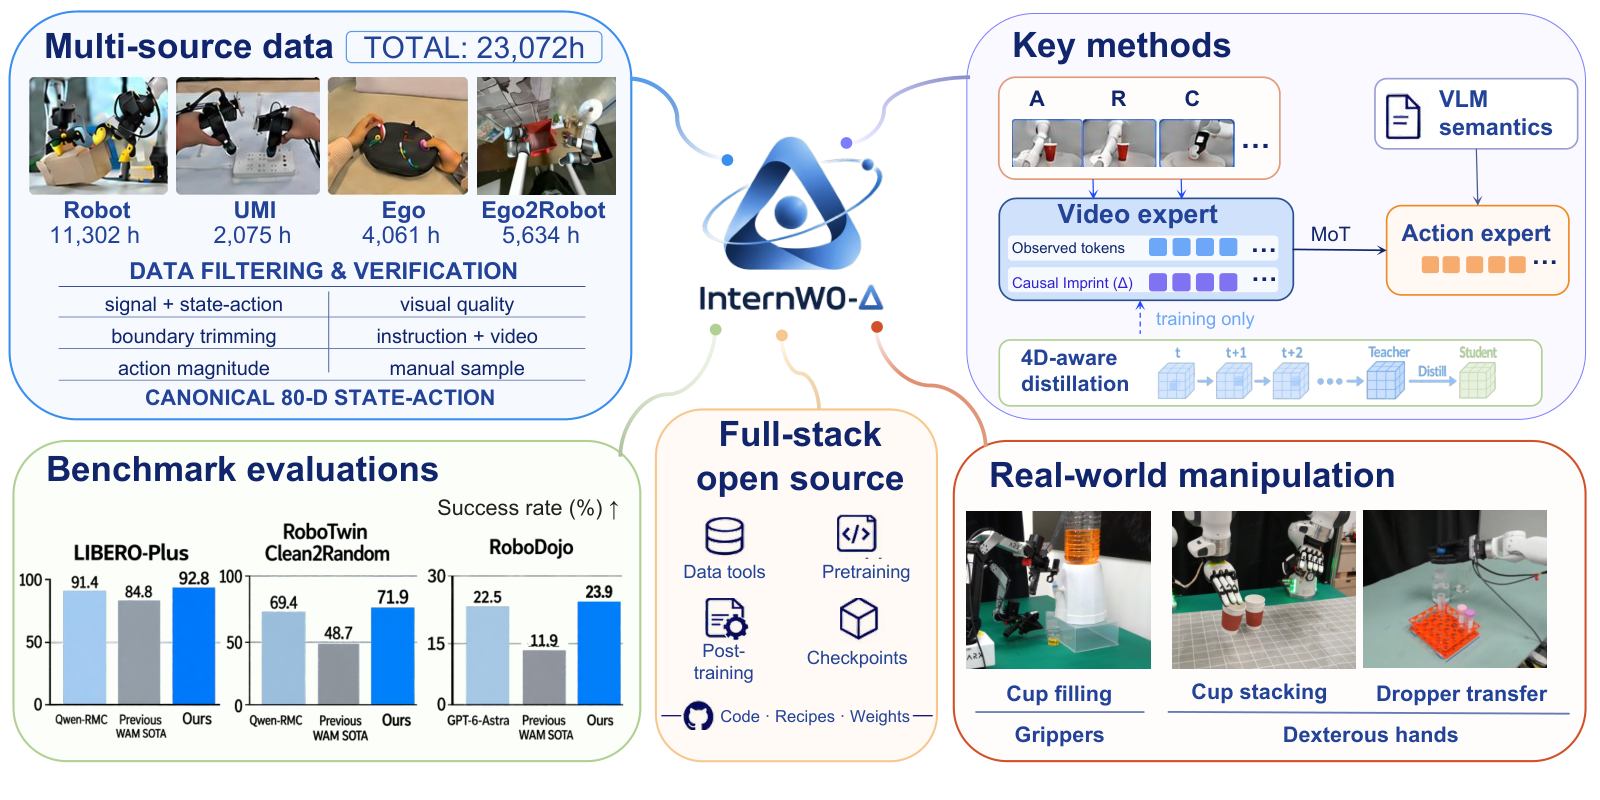
⚡ InternW0-Δ: A World Action Model Bridging Predictive Dynamics and Actions with 20K+ Hours of Open Data
世界模型×动作大系统:MoT 双专家 + 冻结 VLM 语义 + 训练期蒸馏,23,072h 全栈开源。
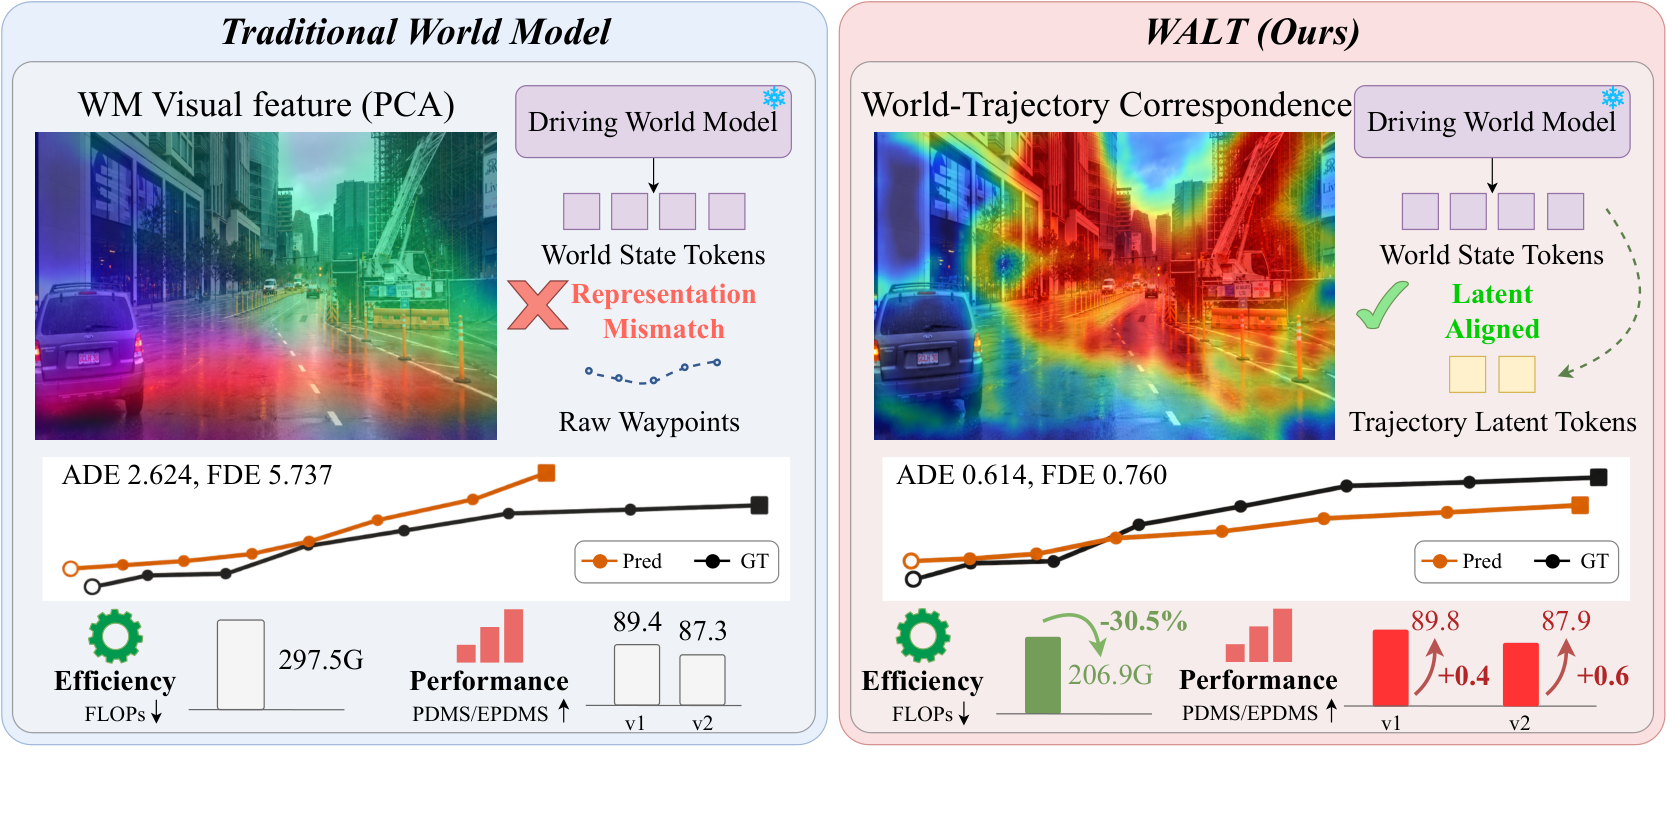
⚡ WALT: Learning World-Model-Aligned Latent Trajectories for Autonomous Driving
轨迹潜空间对齐冻结世界模型:NAVSIM 涨分的同时规划 FLOPs −30.5%。
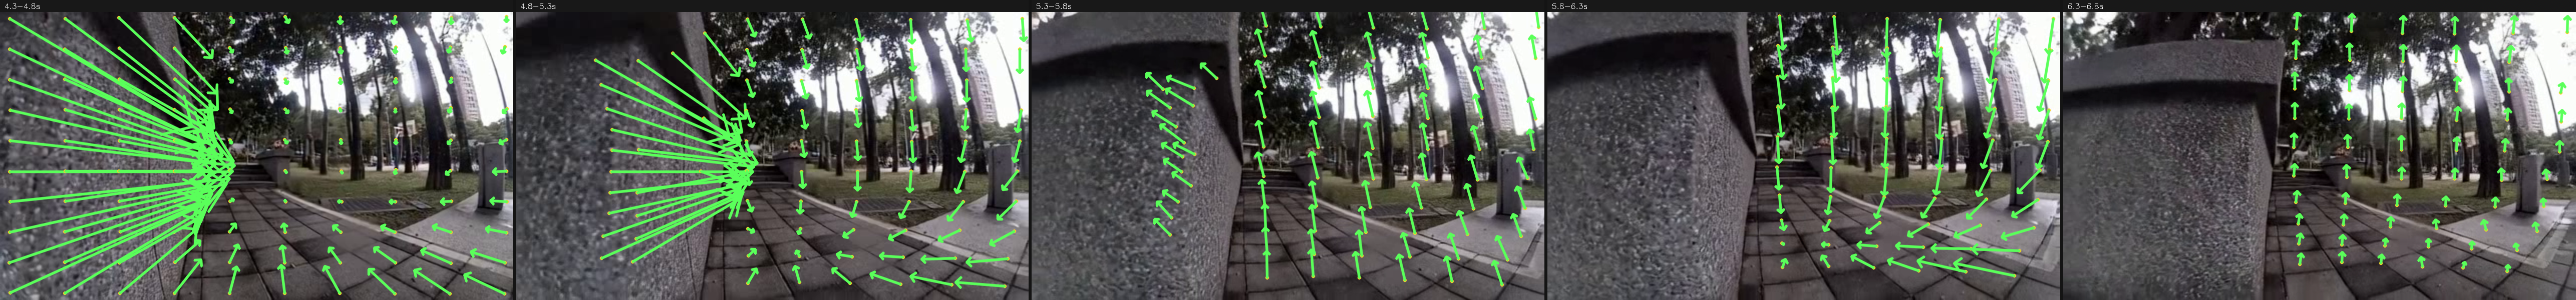
⚡ Action Forcing: Training World Models on Unsupervised Video by Recovering Underlying Egomotion Bases
无标注视频训可控世界模型:PCA egomotion 基当动作监督 + 四维免参考评测。
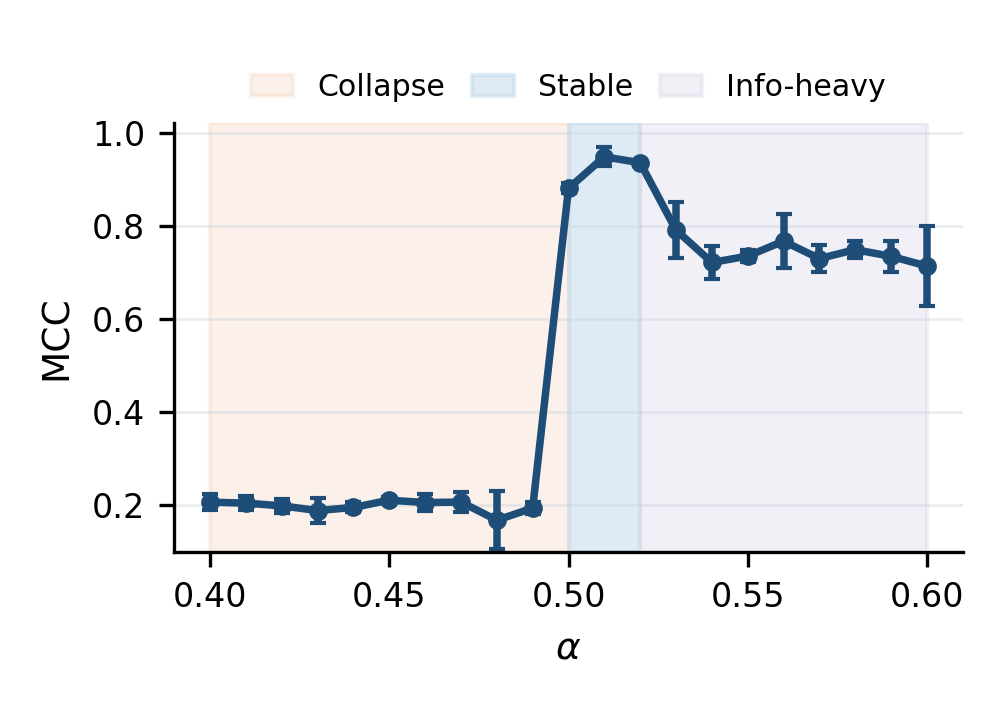
⚡ I Act Therefore I Am: When Is JEPA’s Action-Conditioning Enough to Learn Causal Mechanisms?
动作条件 JEPA 的可辨识性:何时能恢复因果状态(充分动作变异)。
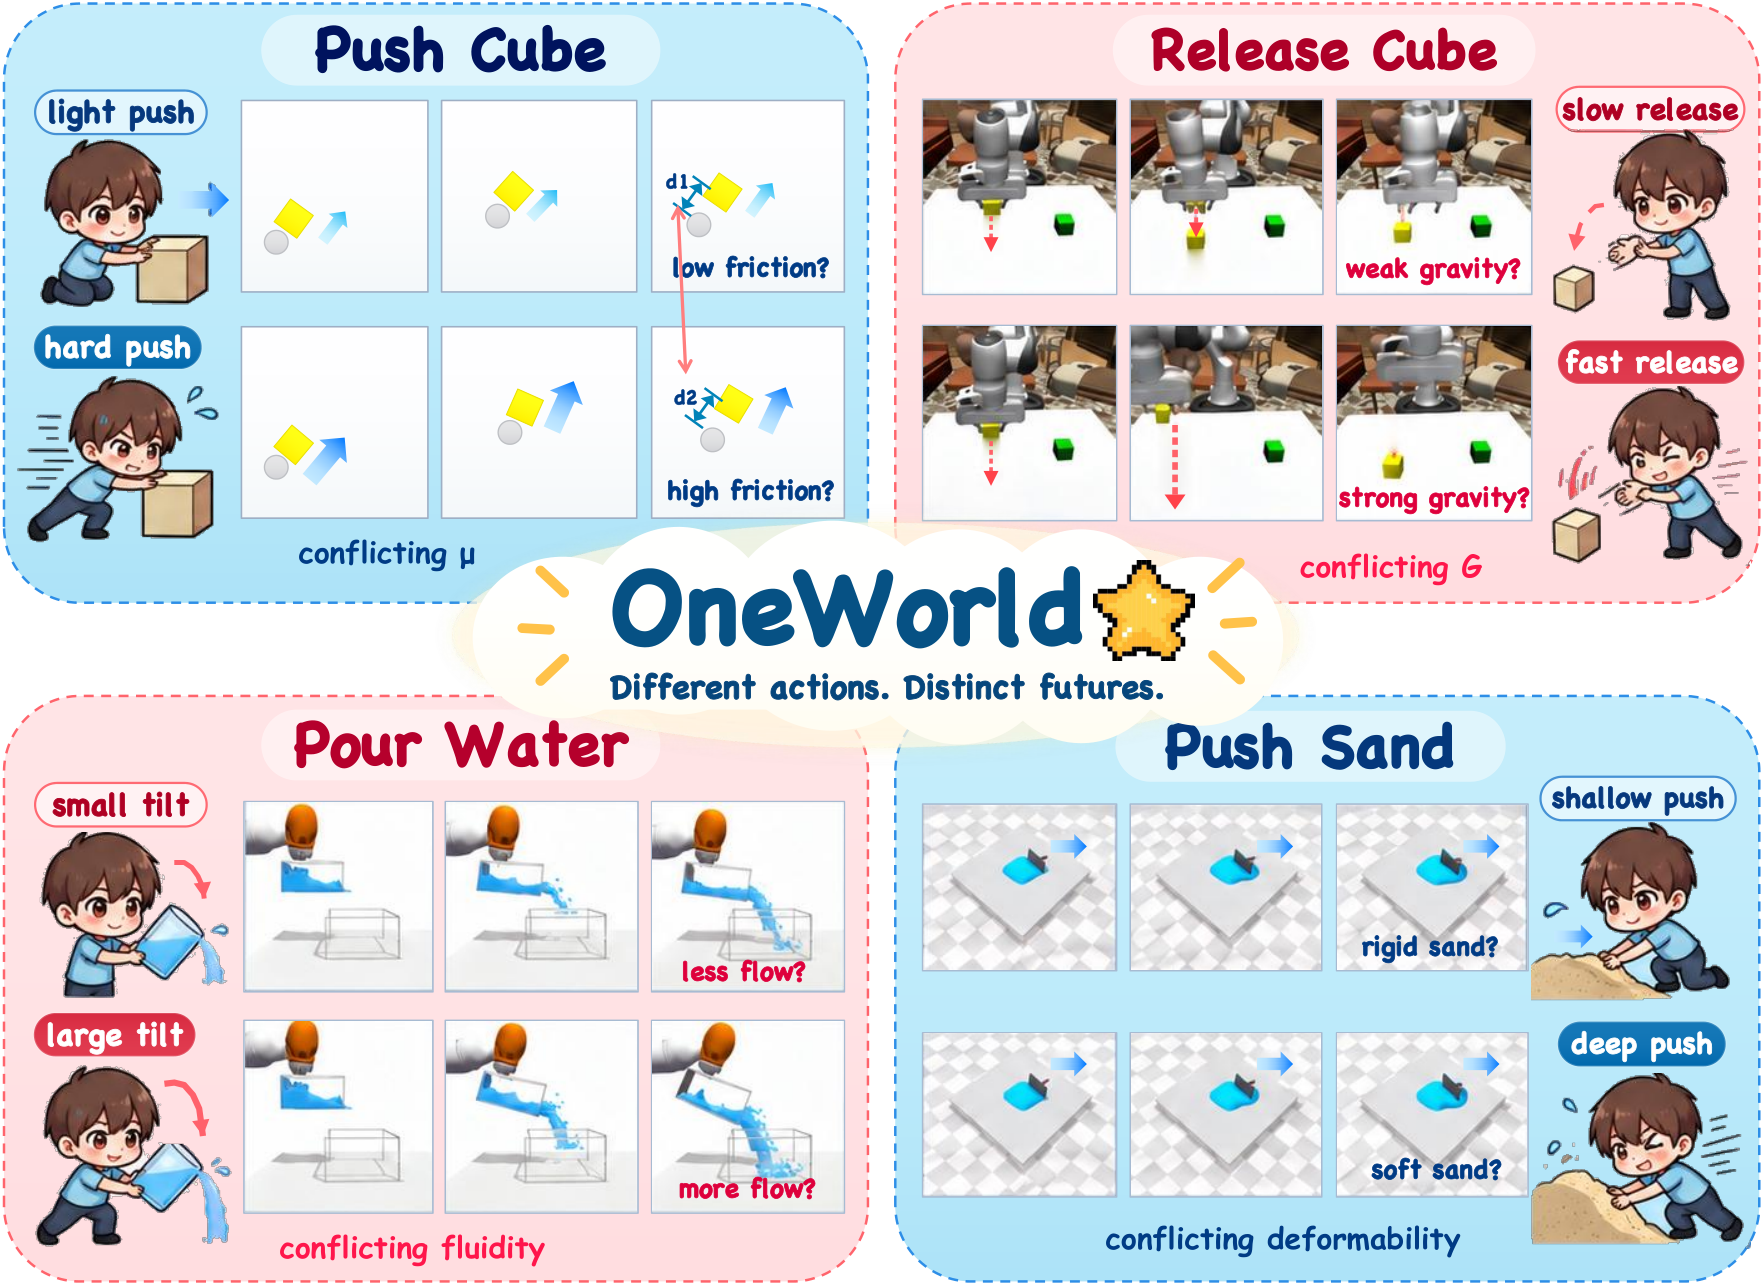
⚡ OneWorld: Learning Consistent Physics Across Actions in World Models
跨动作物理一致性:共享潜机制 + 多干预评估协议。
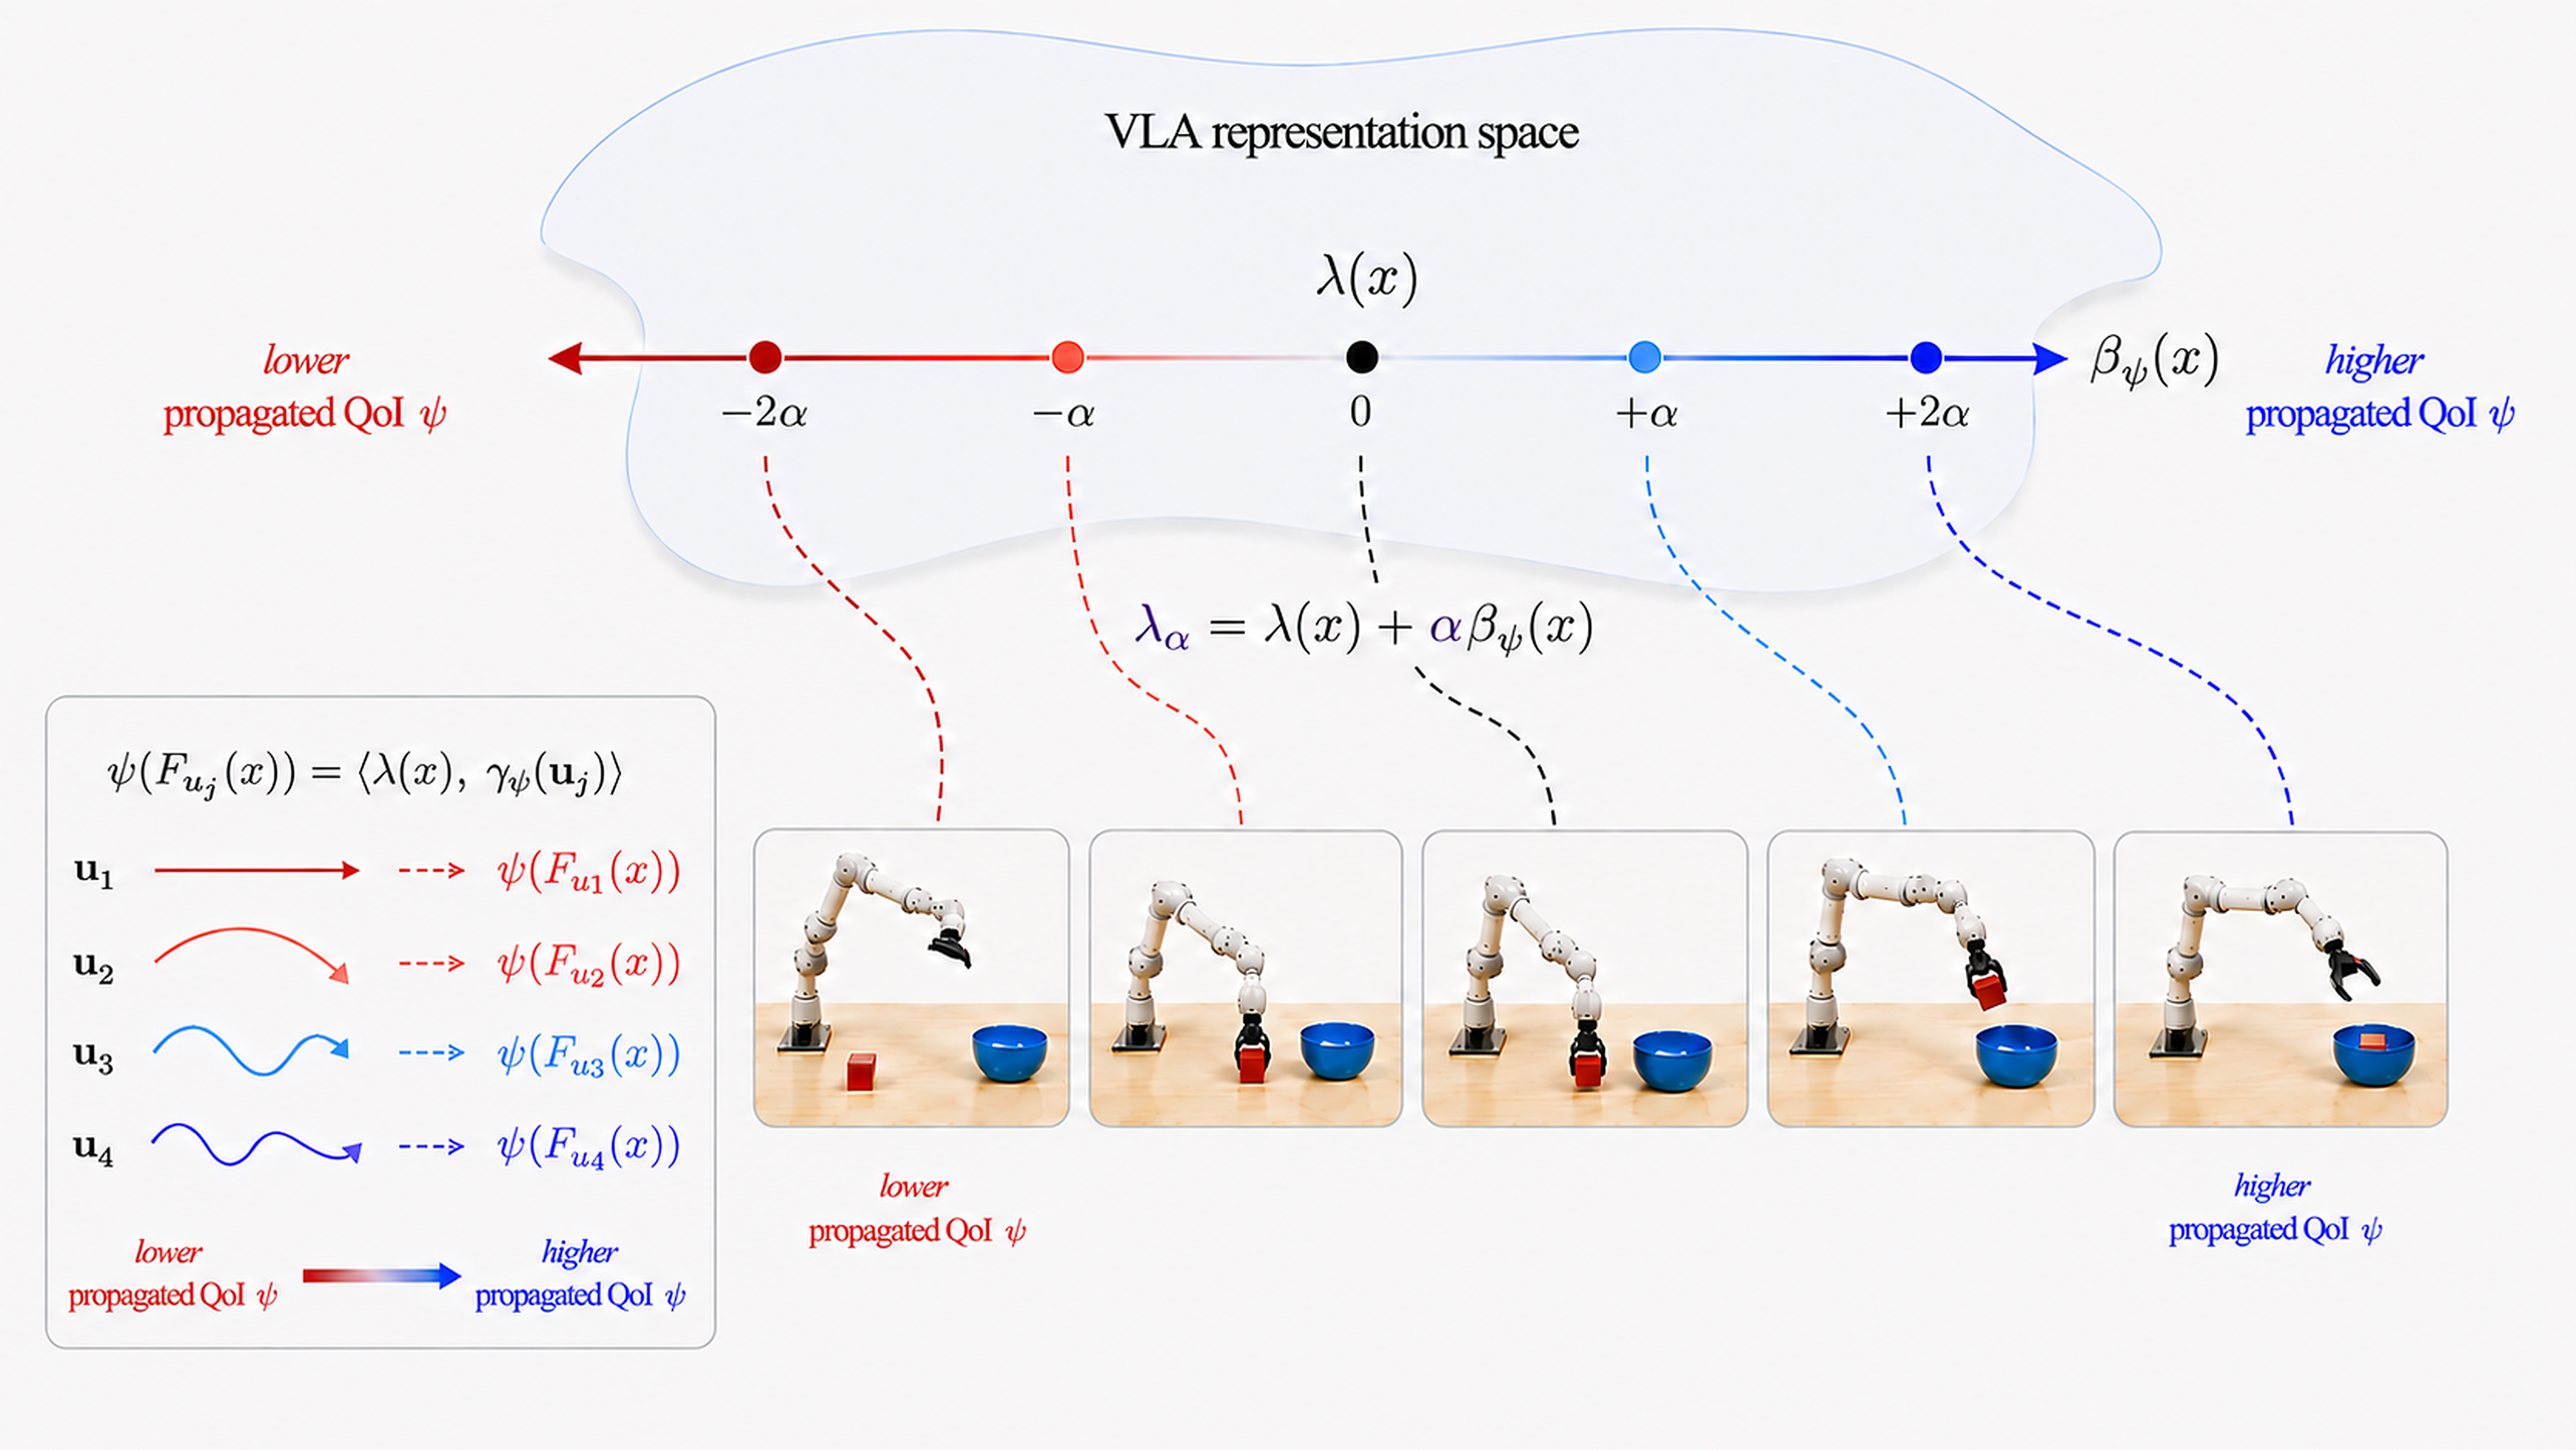
⚡ The Linear Representation Hypothesis for Vision-Language-Action Models
VLA 的线性表示假设:表示-策略统一的 signature 框架 + 线性操控。
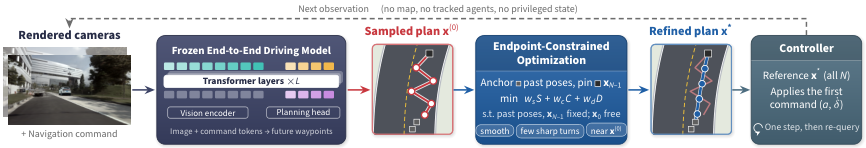
⚡ Guiding End-to-End Driving Models with Endpoint-Constrained Trajectory Optimization
驾驶闭环差距修复:端点保持、重塑中间 waypoint,即插即用。
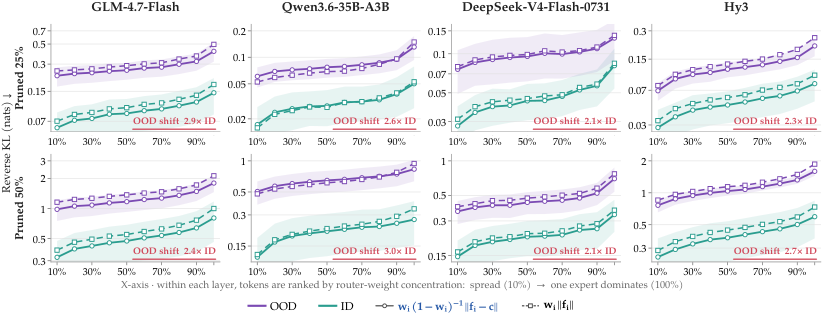
⚡ RAZOR: Pruning Replaceable Experts in LLMs
MoE 专家剪枝的「功能可替代性」口径:8 组设置全胜 REAP。
⚡ Skip the Talk, Re-Focus on Vision: Latent Reasoning for Reasoning Segmentation in Multimodal Large Language Models
推理分割的潜空间推理:潜 token 替代显式 CoT,token ↓16×、gIoU ↑。
⚡ Auditing Latent-Space Monitors for Autonomous Driving
潜空间监控器审计:能预测≠有增量,输出-only 同样强。
自动生成于 2026-09-29 · 基于 arXiv Daily Digest